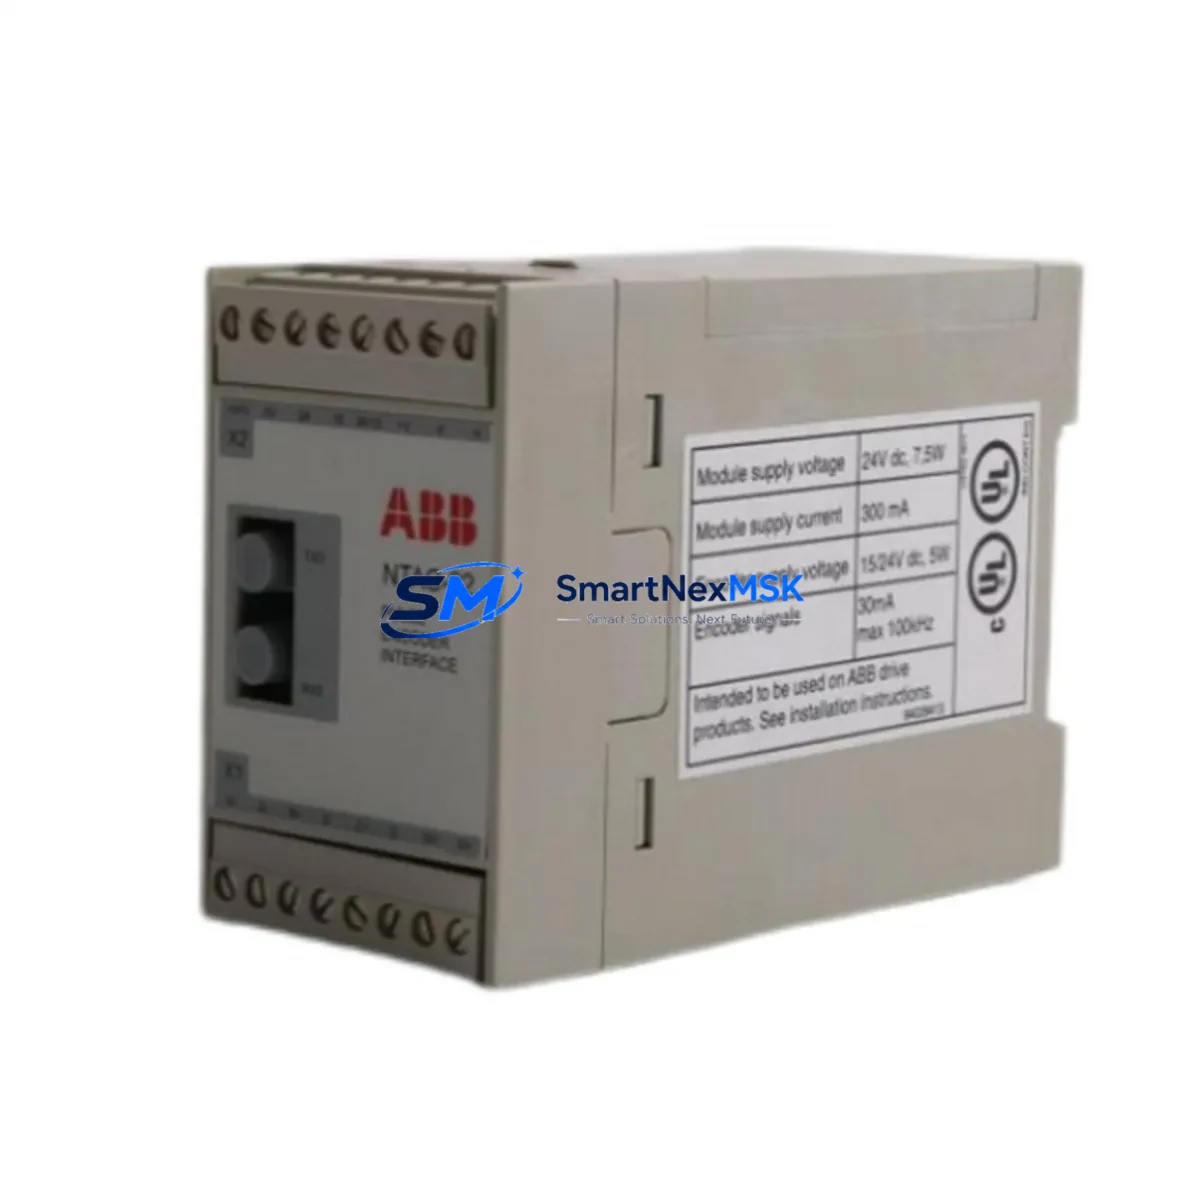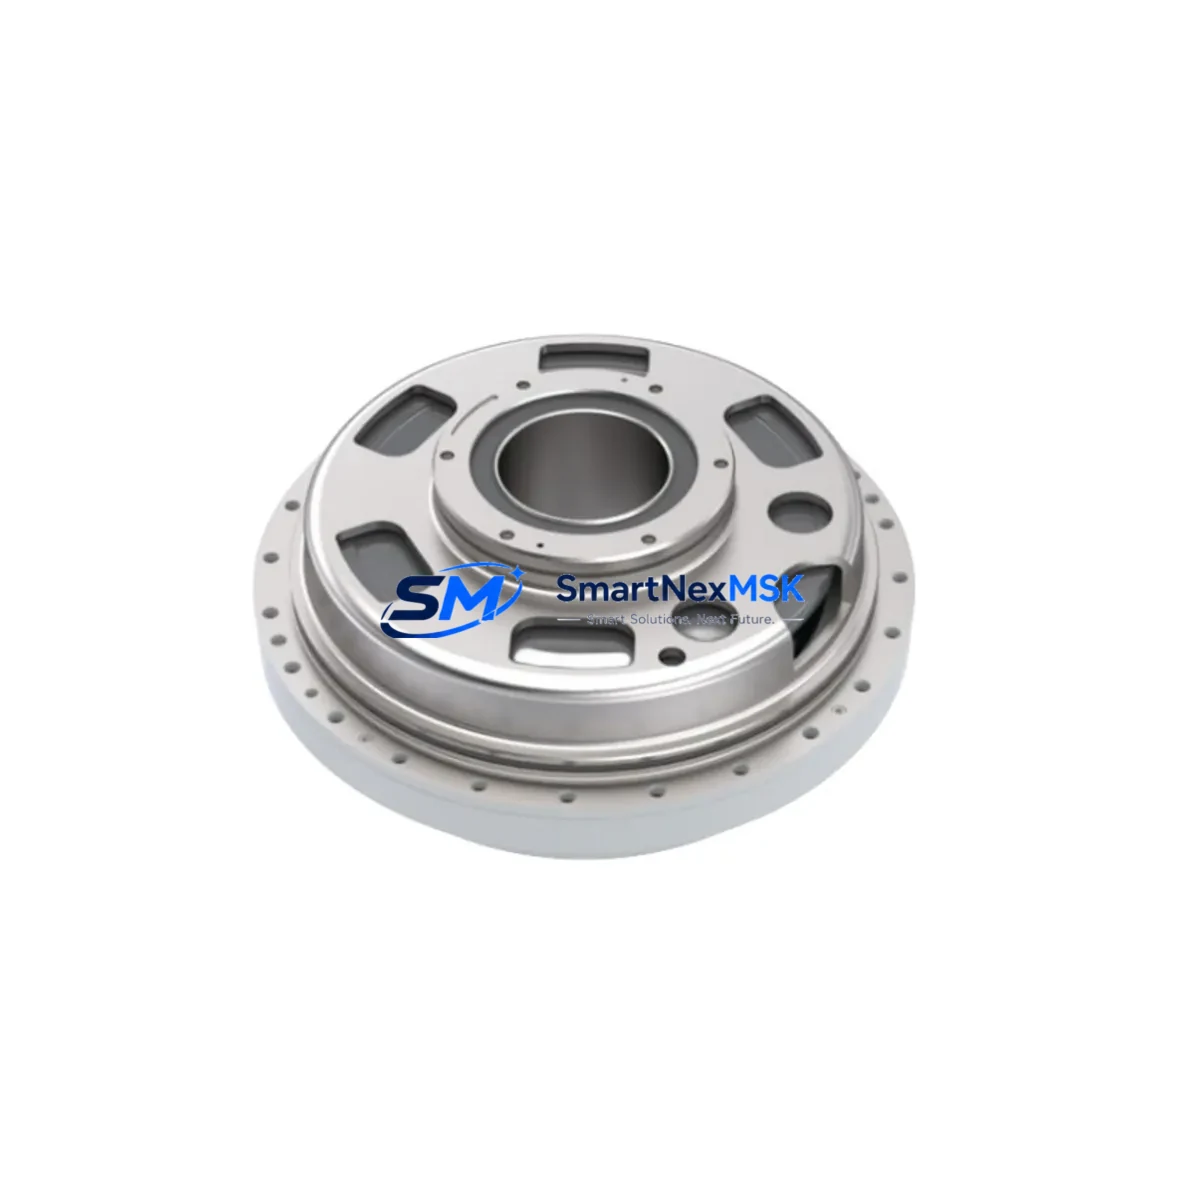
ABB 3HAC021541-001 Maintenance-Ready Spare IRB 6600 Automation
The ABB 3HAC021541-001 is the original upper arm assembly designed for the ABB IRB 6600 series industrial robot — one of the most widely deployed heavy-payload articulated robots in automotive, foundry, and general manufacturing environments. When this component fails or shows signs of mechanical wear, every minute of unplanned downtime translates directly into production loss. Sourcing a verified, maintenance-ready spare is the fastest path to restoring full robot operation and protecting your line’s uptime commitments.
This unit is supplied as an original ABB spare part, manufactured in Germany to ABB Robotics’ exacting dimensional and material specifications. Each unit undergoes functional inspection and electrical continuity verification prior to shipment. A 12-month warranty is included, covering manufacturing defects and component integrity under normal operating conditions. Whether you are executing a planned overhaul, responding to an emergency breakdown, or building a strategic spare parts buffer for your IRB 6600 fleet, the 3HAC021541-001 is the correct, compatible replacement.
Maintenance engineers working on IRB 6600 platforms understand that the upper arm assembly is a load-bearing, precision-aligned structural component. Its replacement requires careful attention to cable routing, wrist harness integrity, and axis 4–6 calibration. Procurement engineers sourcing this part should confirm the robot’s software version and mechanical revision level to ensure full compatibility before installation.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | 3HAC021541-001 |
| Brand | ABB Robotics |
| Series Compatibility | IRB 6600 (all variants incl. IRB 6600-175/2.55, IRB 6600-225/2.55) |
| Component Type | Upper Arm Assembly |
| Origin | Germany (DE) |
| Payload Class | 175–225 kg heavy-payload articulated robot |
| Application Environment | Automotive, foundry, metal fabrication, general heavy manufacturing |
| Installation Position | Axis 3–4 junction, upper arm link |
| Calibration Required | Yes — axis 4, 5, 6 recalibration after replacement |
| Pre-Shipment Testing | Functional inspection + electrical continuity check |
| Warranty | 12 Months — manufacturing defects & component integrity |
| Condition | Original spare (new or factory-refurbished as specified at order) |
| Lead Time | Typically 1–5 business days depending on stock availability |
Maintenance Planning for Continuous Operation
Replacing the 3HAC021541-001 upper arm assembly on an IRB 6600 is rarely an isolated task. A disciplined maintenance engineer will treat this event as an opportunity to inspect and, where necessary, replace adjacent components that share the same service interval or failure mode.
Begin with the axis 3 gearbox (3HAC021540-001) and axis 4 gearbox (3HAC14580-1) — both are mechanically coupled to the upper arm and should be inspected for oil leakage, backlash, and bearing noise during the same shutdown window. The upper arm cable harness (3HAC025562-001) routes power and signal to axes 4, 5, and 6; any chafing, connector corrosion, or insulation breakdown discovered during disassembly should trigger immediate replacement rather than a patch repair.
The SMB (Serial Measurement Board, 3HAC14550-1) is the resolver interface for axes 1–6 and is frequently implicated in position error alarms that precede mechanical failures. If the robot has been logging axis 4–6 resolver faults, inspect the SMB and its battery backup (3HAC16831-1) before returning the robot to service. A depleted SMB battery will cause revolution counter loss after a power cycle, requiring a full recalibration sequence.
On the power distribution side, verify the axis computer (DSQC 668, 3HAC025338-001) and the drive unit for axes 4–6 (DSQC 661, 3HAC026253-001) for fault logs and thermal stress indicators. Overtemperature events in the controller cabinet — often caused by a failing cabinet cooling fan (3HAC025484-001) — can accelerate drive unit degradation and should be addressed concurrently. Check the 24 VDC power supply (DSQC 662, 3HAC026254-001) output voltage under load; a sagging supply rail is a common root cause of intermittent I/O and communication faults that are misdiagnosed as mechanical issues.
Finally, inspect the FlexPendant cable and connector (3HAC028357-001) for physical damage, and verify that the IRC5 controller backplane bus connections are secure and free of oxidation. These checks, performed during the same planned maintenance window as the upper arm replacement, significantly reduce the probability of a secondary failure within the next 12-month operating cycle.
Site Replacement Workflow
Step 1 — Pre-replacement verification: Confirm the robot’s mechanical variant and software version in RobotStudio or the FlexPendant system information screen. Cross-reference the 3HAC021541-001 part number against the robot’s spare parts manual (document 3HAC021338-001) to confirm applicability to your specific IRB 6600 build revision.
Step 2 — Safe isolation: Place the robot in manual mode, engage the mechanical brake, and isolate the IRC5 controller from mains power following LOTO procedures. Allow the drive capacitors to discharge fully (minimum 5 minutes after power-off) before opening the controller cabinet or disconnecting arm cabling.
Step 3 — Cable and harness documentation: Photograph all cable routing, connector positions, and tie-wrap anchor points on the existing upper arm before disassembly. The upper arm harness connectors are keyed but the routing path must be replicated exactly to avoid chafing against the new arm casting during operation.
Step 4 — Mechanical replacement: Follow the ABB service manual torque specifications for all fasteners. Do not substitute metric fasteners with imperial equivalents. Apply fresh thread-locking compound where specified. Verify that the wrist unit seats correctly and that axis 4 rotation is smooth and free of binding before reconnecting the harness.
Step 5 — Calibration and recommissioning: Perform a full axis 4, 5, and 6 calibration using the calibration pendulum or Levelmeter 2000 as specified in the IRB 6600 product manual. Update revolution counters via the FlexPendant. Run a slow-speed test cycle through the full working envelope before returning the robot to production speed.
This structured workflow minimizes total downtime, eliminates rework caused by missed steps, and ensures the replacement spare performs to the same specification as the original factory-installed component.
Spare Parts Support FAQ
Q1: Is the 3HAC021541-001 compatible with all IRB 6600 variants?
The 3HAC021541-001 upper arm assembly is designed for the IRB 6600 series, including the 175/2.55 and 225/2.55 payload/reach variants. Compatibility with specific build revisions should be confirmed against your robot’s serial number and the ABB spare parts manual. Contact our technical team with your robot serial number for a definitive compatibility check before ordering.
Q2: What pre-shipment testing is performed on this spare?
Every 3HAC021541-001 unit undergoes a functional inspection and electrical continuity verification before dispatch. Units are packaged in protective foam-lined crating to prevent transit damage. A test report is available upon request. The 12-month warranty covers manufacturing defects and component integrity under normal operating conditions from the date of receipt.
Q3: How should I manage IRB 6600 spare parts inventory to minimize downtime risk?
For facilities operating two or more IRB 6600 robots, we recommend holding at minimum one 3HAC021541-001 upper arm assembly, one set of axis 3–4 gearbox seals, one SMB battery, and one spare cable harness as a fast-response buffer. High-cycle applications (automotive body-in-white, foundry tending) should consider a complete axis 4–6 drive unit as a critical spare given the thermal stress profile of those environments.
Q4: What is the lead time and can expedited shipment be arranged?
Standard lead time is 1–5 business days from order confirmation depending on current stock position. For emergency breakdown situations, contact us directly at [email protected] or +86 18259474341 to discuss same-day dispatch options. We maintain strategic stock of high-demand IRB 6600 spares to support urgent maintenance requirements globally.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341