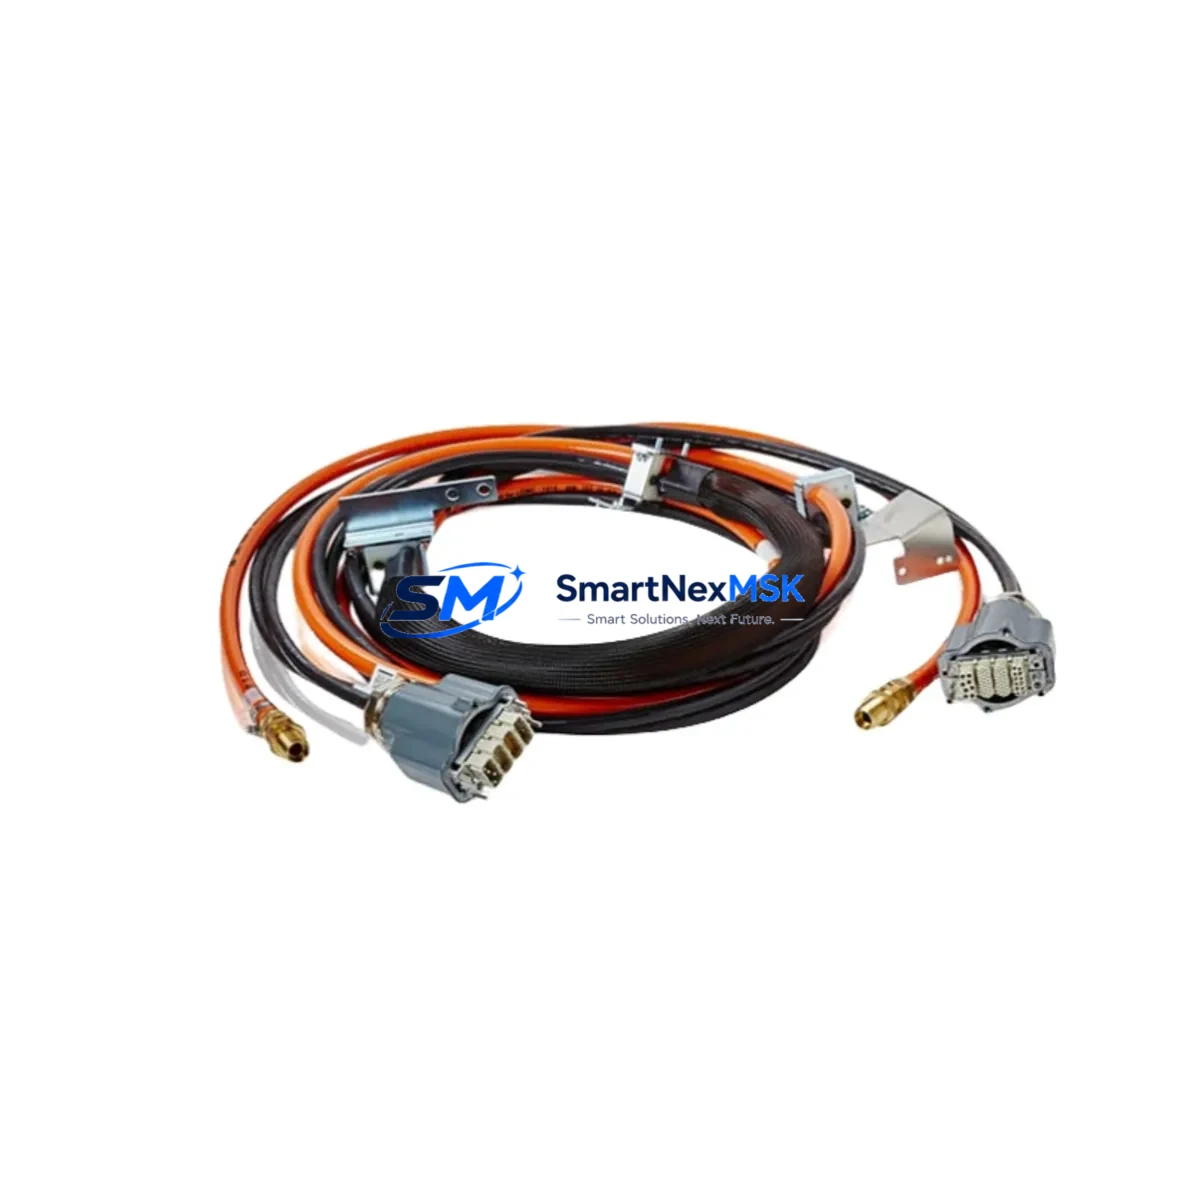
ABB 3HAC022999-001 Maintenance-Ready Spare for IRB6400 Automation
The ABB 3HAC022999-001 is an original lower arm cable harness engineered for ABB IRB 6400 and IRB 6650 industrial robot systems. In high-cycle manufacturing environments — automotive body shops, foundry lines, heavy-duty palletizing cells, and arc welding stations — the lower arm cable harness is one of the highest-wear consumable assemblies on the robot. Mechanical flexing, thermal cycling, coolant exposure, and abrasion from cable management guides all accelerate harness degradation. Maintaining a certified OEM replacement unit on the shelf is the single most effective strategy for minimizing unplanned downtime when harness failure occurs.
Sourced directly from ABB’s authorized supply chain and manufactured in Sweden to original factory specifications, the 3HAC022999-001 ensures full electrical continuity, correct connector pinout, and mechanical fit without modification. Every unit shipped by SMARTNEXMSK undergoes pre-shipment continuity and insulation testing, and is covered by a 12-month warranty against manufacturing defects.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | 3HAC022999-001 |
| Brand | ABB (Sweden) |
| Description | Lower Arm Cable Harness |
| Compatible Series | IRB 6400, IRB 6650 |
| Origin | Sweden (OEM) |
| Connector Type | OEM multi-pin, factory-crimped |
| Cable Rating | Rated for high-flex, high-cycle robot arm motion |
| Installation Position | Lower arm (Axis 2–3 region) |
| Application Environment | Automotive, foundry, welding, palletizing, heavy-duty industrial |
| Maintenance Interval | Inspect every 6,000–8,000 operating hours or per ABB PM schedule |
| Replacement Trigger | Insulation breakdown, chafing, connector corrosion, axis fault alarms |
| Pre-Shipment Test | Continuity + insulation resistance verified |
| Warranty | 12 Months |
| Lead Time | In-stock; ships within 1–3 business days |
| Long-Term Supply | Available for legacy IRB 6400 fleet life extension programs |
Maintenance Planning for Continuous Operation
When a maintenance or procurement engineer schedules replacement of the 3HAC022999-001 lower arm cable harness, the work order should extend to a broader inspection of the robot’s electrical and signal infrastructure. Cable harness failure rarely occurs in isolation — it is typically accompanied by accelerated wear on adjacent components that share the same routing path and environmental exposure.
During the same maintenance window, engineers should inspect the upper arm cable harness (3HAC025562-001) for signs of jacket cracking or connector pin corrosion, as it operates under similar flex cycles. The axis 1 motor cable (3HAC026253-001) and axis 2–3 motor power cables should be checked for insulation integrity using a megohmmeter. The SMB (Serial Measurement Board) battery unit and its connecting harness should be verified — a degraded SMB connection can generate axis calibration faults that mimic harness failure symptoms.
At the controller cabinet level, inspect the IRC5 controller main computer (DSQC 639) and its I/O bus connections for loose backplane connectors that may have been disturbed during harness routing. The DSQC 652 digital I/O board and any installed DSQC 378 fieldbus adapter (DeviceNet or PROFIBUS) should be reseated and checked for alarm history. Verify that the teach pendant (FlexPendant) cable is undamaged and that the emergency stop circuit through the safety relay module is functioning correctly before returning the robot to production.
For welding applications, also inspect the process cable assembly connecting the robot to the welding power source, and confirm that the wire feeder interface harness is free of burn-through damage. Maintaining a coordinated spare parts kit — harness, SMB battery, I/O board, and safety relay — reduces mean time to repair (MTTR) and supports a predictive maintenance posture rather than a reactive one.
Site Replacement Workflow
Step 1 — Isolation: Place the IRC5 controller in maintenance mode. De-energize the robot and lock out / tag out (LOTO) per site safety procedure. Confirm zero-energy state on all axis drives.
Step 2 — Documentation: Photograph the existing harness routing, cable tie positions, and connector orientation before disassembly. This is critical for correct reinstallation and for identifying any non-standard field modifications made to legacy IRB 6400 units.
Step 3 — Removal: Release cable management clips along the lower arm. Disconnect the harness at both the axis 2 motor junction and the upper arm interface connector. Note any signs of chafing, heat discoloration, or connector pin damage for the maintenance log.
Step 4 — Installation: Route the 3HAC022999-001 replacement harness following the original path. Secure all cable ties at factory-specified intervals. Reconnect all connectors and verify positive locking on each multi-pin housing.
Step 5 — Verification: Restore power and perform a low-speed axis 2–3 motion test. Monitor the IRC5 event log for any residual axis fault codes. Confirm signal integrity on all I/O channels before returning to full production speed.
This workflow is compatible with both the original IRB 6400 platform and the IRB 6650 derivative, making the 3HAC022999-001 a dual-platform spare that simplifies inventory management for mixed-fleet robot installations.
Spare Parts Support FAQ
Q1: Is the 3HAC022999-001 compatible with all IRB 6400 variants?
The 3HAC022999-001 lower arm cable harness is designed for the IRB 6400 series and is also compatible with the IRB 6650. Always verify the robot’s serial number and arm configuration against ABB’s spare parts documentation or contact our technical team to confirm fitment for your specific unit before installation.
Q2: How is the harness tested before shipment?
Every 3HAC022999-001 unit undergoes pre-shipment electrical testing including conductor continuity verification and insulation resistance measurement. Units that do not meet OEM electrical specifications are quarantined and not shipped. A test record is available upon request.
Q3: What does the 12-month warranty cover?
The warranty covers manufacturing defects in materials and workmanship for 12 months from the date of shipment. It does not cover damage resulting from incorrect installation, mechanical abuse, or operation outside the robot’s rated duty cycle. Warranty claims are processed through [email protected] with photographic evidence of the defect.
Q4: Can you support long-term supply for legacy IRB 6400 fleets?
Yes. SMARTNEXMSK maintains stock of the 3HAC022999-001 and related IRB 6400 / IRB 6650 spare parts to support fleet life extension programs. For customers managing 10+ robot installations, we offer reserved stock agreements and priority lead times. Contact our procurement team to discuss a tailored supply arrangement.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341