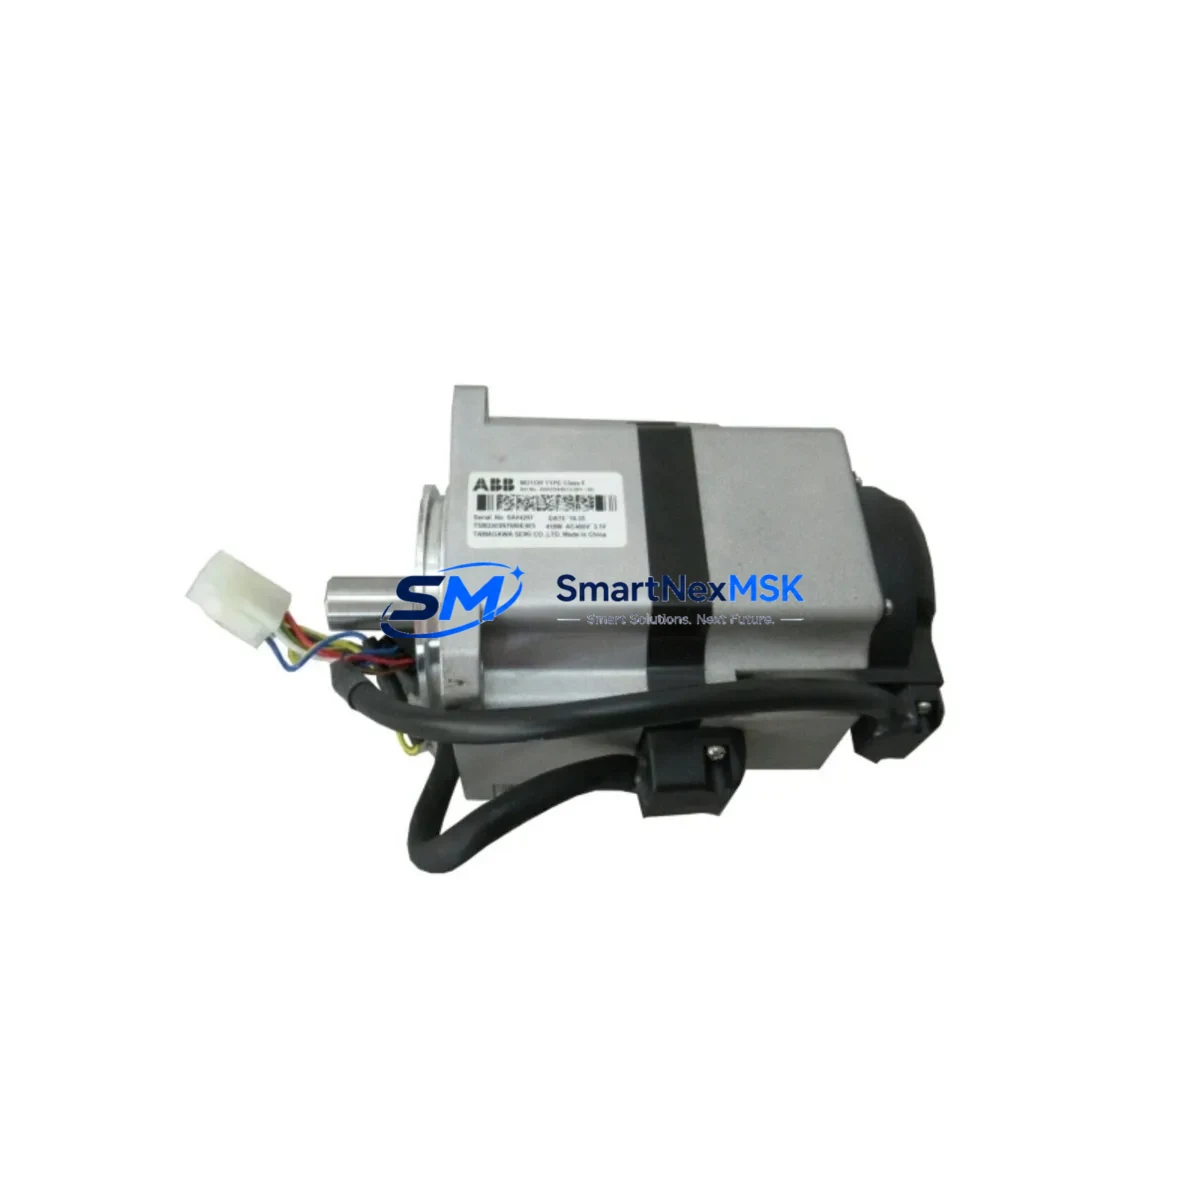
ABB 3HAC024779-002 Retrofit-Ready AC Servo Motor for IRB 6600: Compatible Upgrade for Legacy Robot Control Systems
The ABB 3HAC024779-002 is a precision AC servo motor engineered for the IRB 6600 series industrial robot platform. As automation facilities worldwide face the challenge of maintaining aging robot fleets, this unit serves as a verified retrofit-ready replacement for discontinued or end-of-life servo motor assemblies within the IRB 6600 drive train. Whether you are executing a planned maintenance overhaul, recovering from an unplanned axis failure, or modernizing a legacy production cell, the 3HAC024779-002 delivers the mechanical and electrical compatibility required for a smooth, low-downtime swap.
Sourced directly from authorized supply channels and subjected to pre-shipment functional testing, each unit is backed by a 12-month warranty covering manufacturing defects and performance deviations. Stock is maintained to support urgent dispatch requirements for facilities operating on tight maintenance windows.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Series | ABB IRB 6600 (all axis configurations) |
| Replaces / Supersedes | 3HAC024779-001 and earlier servo motor variants in IRB 6600 axis assemblies |
| Motor Type | AC Servo Motor (brushless, encoder-feedback) |
| Mounting Interface | Direct bolt-on to IRB 6600 gearbox flange; no adapter plate required |
| Connector / Terminal Compatibility | Compatible with ABB IRC5 cabinet power and resolver/encoder wiring harness |
| Communication Protocol | Resolver-based feedback; compatible with ABB DSQC series drive units |
| Backplane / Rack Interface | N/A (standalone motor unit; interfaces via drive cabinet) |
| Controller Compatibility | ABB IRC5 controller with DSQC661 / DSQC662 drive modules |
| Installation Requirement | Axis calibration via RobotStudio or teach pendant after replacement |
| Commissioning Note | Fine calibration offset update required; original program logic preserved |
| Warranty | 12 months from date of shipment; covers manufacturing defects and performance |
| Origin | Sweden (ABB Robotics) |
Retrofit Planning for Existing Automation Systems
Replacing a servo motor in an IRB 6600 robot requires careful pre-work to ensure the surrounding control architecture remains intact. Before removing the failed unit, engineers should document the current axis calibration data stored in the IRC5 controller — this data is critical for restoring precise positional accuracy after the new 3HAC024779-002 is installed. The IRC5 cabinet typically houses the DSQC661 or DSQC662 servo drive modules, and both are fully compatible with the resolver feedback interface on this motor. Verify that the drive module firmware is current, as older firmware versions may require an update to correctly interpret the encoder signal from the replacement unit.
Power supply capacity within the IRC5 cabinet should be confirmed before installation. The DSQC609 power supply unit or its equivalent must be delivering stable 24 VDC auxiliary power to the drive bus. If the cabinet has been in service for more than eight years, it is advisable to inspect the DSQC608 capacitor bank module for degradation, as a weakened capacitor bank can cause intermittent drive faults even with a new motor installed.
Terminal wiring at the motor connector block follows the standard ABB color-coded harness convention. Technicians should cross-reference the wiring diagram in the IRB 6600 product manual (document 3HAC026876-001) before disconnecting the existing harness. The resolver cable and the power cable must be routed separately to avoid signal interference — a common oversight during rushed replacements that leads to erratic axis behavior post-commissioning.
For facilities running multiple IRB 6600 units on the same production line, it is worth maintaining a small buffer stock of the 3HAC024779-002 alongside related consumables such as the 3HAC14550-2 gearbox oil seal kit and the 3HAC026876-001 axis-1 bearing assembly. These components share the same service interval and are frequently replaced together during planned shutdowns. Additionally, if the robot cell communicates with a Siemens S7-300 PLC or an Allen-Bradley ControlLogix controller via DeviceNet or PROFIBUS, verify that the fieldbus node address assignments remain unchanged after the motor swap — the IRC5 controller’s fieldbus configuration does not reset during a motor replacement, but a power cycle of the entire cell can occasionally trigger a node re-enumeration on older PROFIBUS segments.
HMI screens connected to the robot cell via the ABB Panel PC 800 or a third-party SCADA system should be reviewed to confirm that axis status tags are correctly mapped. In some legacy integrations, axis fault codes from the IRC5 are forwarded to the HMI via an OPC-DA server running on the robot controller’s embedded PC. After the motor replacement and recalibration, a short test cycle should be run to confirm that all axis position feedback values displayed on the HMI match the teach pendant readings within acceptable tolerance.
Downtime Control During System Migration
Minimizing production downtime during a servo motor replacement on the IRB 6600 begins with preparation, not execution. The replacement procedure itself — mechanical removal, motor installation, cable reconnection, and axis calibration — can typically be completed within four to six hours by a qualified ABB-certified technician. The majority of unplanned downtime extensions occur due to missing calibration data, incorrect wiring, or the discovery of secondary faults in adjacent components such as the DSQC662 drive module or the resolver cable harness.
To protect original program logic, back up the IRC5 controller configuration using RobotStudio before beginning any mechanical work. This backup captures the RAPID program, system parameters, I/O configuration, and axis calibration offsets. If the replacement motor requires a calibration offset adjustment, the original program logic remains entirely intact — only the calibration data file is updated. This means that once the axis is recalibrated, the robot can resume its production program without any reprogramming.
For facilities that cannot tolerate extended downtime, a pre-staged replacement strategy is recommended: install and pre-wire the 3HAC024779-002 on a spare axis assembly or test stand, perform a bench-level resolver check, and then execute the final swap during a scheduled maintenance window. This approach reduces live installation time to under two hours and eliminates the risk of discovering wiring or compatibility issues during production hours. Coordinating the motor swap with a broader IRC5 cabinet inspection — covering the DSQC661 drive, DSQC609 power supply, and fieldbus communication modules — further reduces the frequency of future unplanned stoppages.
Retrofit Support FAQ
Q1: Is the ABB 3HAC024779-002 a direct drop-in replacement for the 3HAC024779-001?
Yes. The 3HAC024779-002 is the current production revision of the 3HAC024779-001 and is mechanically and electrically interchangeable. The mounting flange dimensions, resolver connector pinout, and power connector interface are identical. No adapter hardware or wiring modification is required. After installation, an axis calibration update via the IRC5 teach pendant is the only commissioning step needed.
Q2: What commissioning steps are required after installing the 3HAC024779-002?
After mechanical installation and cable reconnection, power on the IRC5 controller and navigate to the calibration menu on the teach pendant (FlexPendant). Select the affected axis and perform a fine calibration using the calibration pin method as described in the IRB 6600 product manual. Update the calibration offset value and verify axis movement across the full range of motion. Run a slow-speed test cycle of the production program before returning the robot to full operating speed.
Q3: How do I verify wiring compatibility before powering on the system?
Before energizing the IRC5 cabinet, use a multimeter to verify continuity on the resolver cable between the motor connector and the DSQC662 drive module terminal block. Check that the power cable phase connections (U, V, W) match the original wiring diagram. Confirm that the protective earth (PE) conductor is securely bonded to the motor housing. A resolver signal check can be performed using the IRC5 diagnostic menu without running the motor, which allows you to confirm signal integrity before committing to a full power-on sequence.
Q4: What does the 12-month warranty cover, and how is a claim initiated?
The 12-month warranty covers manufacturing defects, resolver signal failures, winding insulation faults, and encoder feedback anomalies that arise under normal operating conditions. Physical damage resulting from incorrect installation, overvoltage events, or contamination is excluded. To initiate a warranty claim, contact our sales team at [email protected] with the order number, a description of the fault symptom, and any IRC5 fault codes recorded at the time of failure. Replacement units are dispatched within 3 business days of claim approval.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341