ABB 3HAC024782-003 Retrofit-Ready Servo Motor for IRB 6620 Control Systems
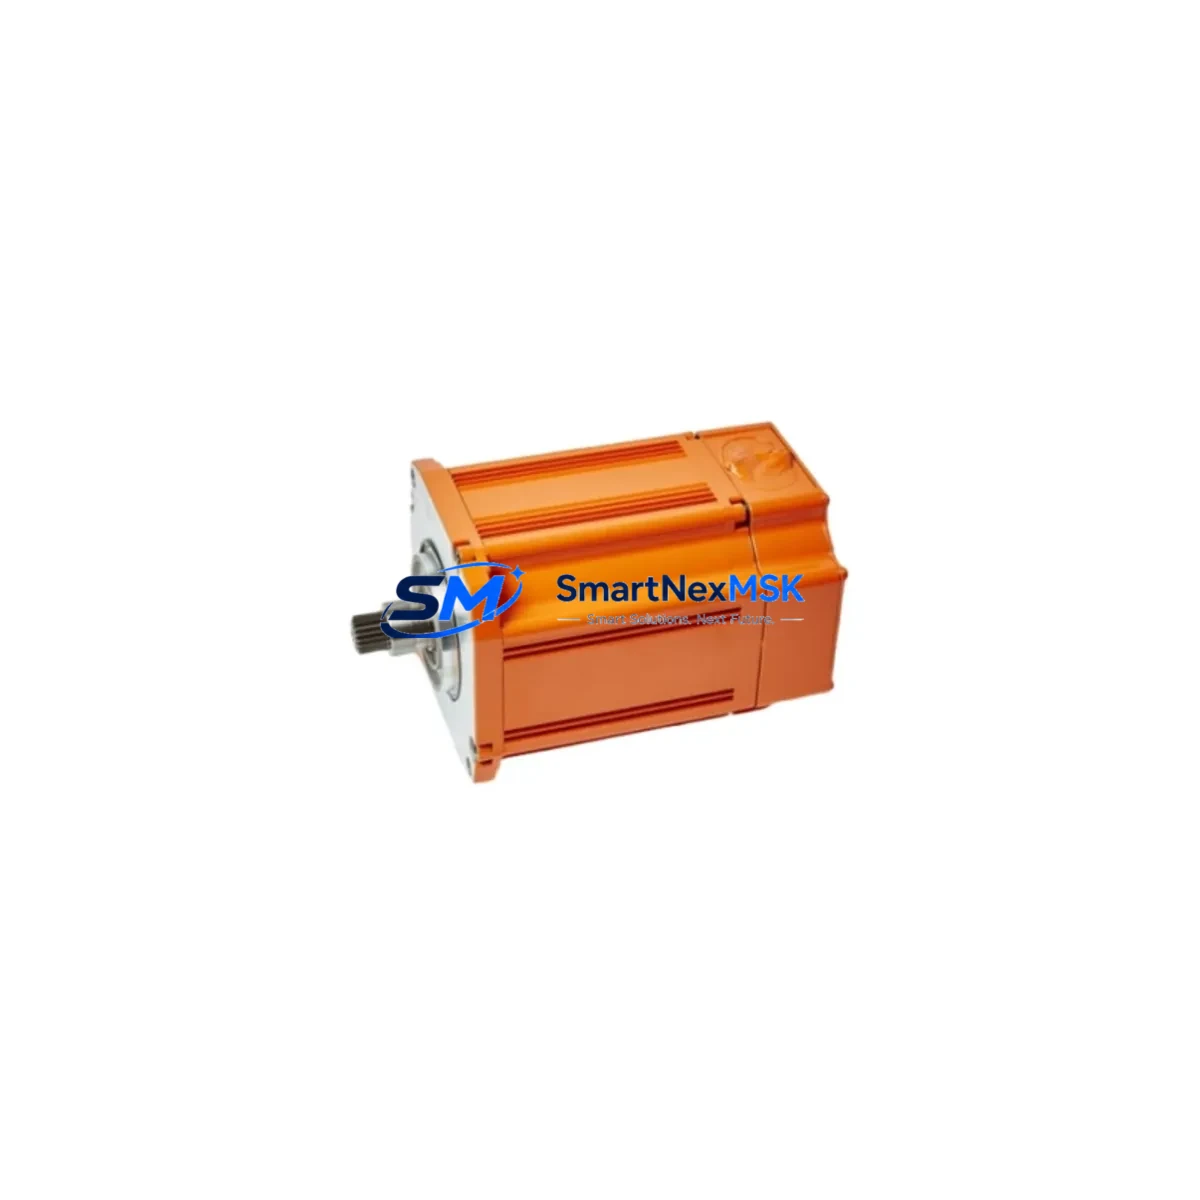
The ABB 3HAC024782-003 is a precision AC servo motor engineered for the IRB 6620 articulated robot series, widely deployed in automotive body-in-white welding, material handling, and heavy-duty palletizing lines. As legacy IRB 6620 installations approach end-of-support cycles, procurement teams and maintenance engineers increasingly rely on verified replacement units to sustain uptime without committing to a full robot replacement. SMARTNEXMSK maintains ready stock of the 3HAC024782-003 with full functional testing, dimensional inspection, and a 12-month warranty on every unit shipped.
This motor is a direct mechanical and electrical replacement for the original axis drive assembly. It interfaces with the ABB IRC5 controller cabinet through the standard SMB (Serial Measurement Board) harness and axis computer board, preserving existing resolver feedback signals and eliminating the need for parameter re-mapping in RobotWare. Engineers retrofitting worn or failed axis motors on IRB 6620 installations can swap the 3HAC024782-003 without modifying the RAPID program, provided the axis calibration offset is re-recorded using the FlexPendant calibration routine after installation.
Upgrade Compatibility Table
| Parameter | Detail |
|---|---|
| Compatible Robot Series | ABB IRB 6620 (all variants: 150/2.2, 175/2.0) |
| Controller Compatibility | ABB IRC5 Single / Dual Cabinet |
| Feedback Interface | Resolver via SMB board (3HAC031670-001 or equivalent) |
| Mounting Interface | Direct flange replacement — no adapter plate required |
| Connector Type | OEM-matched motor power and resolver connectors |
| Communication Compatibility | DeviceNet / PROFIBUS DP via IRC5 axis computer — no reconfiguration needed |
| Calibration Requirement | Axis offset re-calibration via FlexPendant after installation |
| Replacement Scope | Drop-in for failed or worn axis motor; no RAPID program modification required |
| Pre-shipment Testing | Full functional run-in and insulation resistance test |
| Warranty | 12 months from date of shipment |
Retrofit Planning for Existing Automation Systems
A successful IRB 6620 servo motor retrofit begins well before the replacement unit arrives on site. Maintenance planners should first audit the IRC5 controller cabinet to confirm the axis computer board — typically the DSQC 668 or DSQC 673 — is functioning correctly, since a degraded axis computer can mask the true source of motor faults and lead to repeat failures after replacement. The SMB board (Serial Measurement Board), which manages resolver signal conditioning for all six axes, should also be inspected; a failing SMB board can generate false encoder errors that mimic motor failure symptoms.
On the power distribution side, verify that the drive module within the IRC5 cabinet — the ABB DSQC 661 or DSQC 662 drive unit depending on cabinet configuration — is delivering clean DC bus voltage within specification. Voltage ripple or intermittent bus faults will stress a new motor and shorten its service life. Check the capacitor bank condition and confirm that the main computer board (DSQC 1000 or DSQC 639) is logging no persistent fault codes related to the drive chain before proceeding with the motor swap.
For sites running DeviceNet or PROFIBUS DP fieldbus topologies, confirm that the fieldbus adapter module — such as the DSQC 651 for DeviceNet or DSQC 667 for PROFIBUS — is correctly addressed and that the network scan list in the IRC5 system parameters matches the physical I/O configuration. Fieldbus communication errors introduced during a maintenance window can delay restart and extend unplanned downtime beyond the motor swap itself.
Before removing the failed motor, back up the current system configuration using RobotStudio or the FlexPendant backup function. This preserves the RAPID module library, system parameters, tool data, work object definitions, and calibration offsets. Store the backup on an external USB drive and verify the archive is complete. After installing the 3HAC024782-003, restore the backup, perform the axis calibration routine, and run a slow-speed dry cycle through the full working envelope before resuming production speed. Document the new calibration offset values and update the site maintenance log.
Downtime Control During System Migration
Minimizing unplanned downtime during an IRB 6620 servo motor replacement requires a structured pre-maintenance protocol. Begin by scheduling the swap during a planned production window rather than responding reactively to a hard failure — predictive maintenance indicators such as increasing motor temperature trends, rising current draw on the axis drive, or intermittent position error alarms are reliable early warning signals that the 3HAC024782-003 should be staged as a ready spare.
Keep the replacement motor in its protective packaging at ambient temperature for at least two hours before installation to prevent condensation on the winding insulation. Prepare the torque specifications for all mounting fasteners in advance, and have the FlexPendant calibration procedure printed or accessible offline in case the teach pendant display is unavailable during the maintenance window. Assign one technician to the mechanical swap and a second to manage the IRC5 controller — powering down the drive system in the correct sequence, monitoring the DC bus discharge indicator, and confirming safe-to-work status before the mechanical team begins disassembly.
After installation, perform a controlled power-up sequence: enable the controller in manual reduced-speed mode, jog each axis individually to confirm correct direction and resolver feedback, then run the calibration routine. Only after all six axes report correct calibration offsets and no active fault codes should the system be returned to automatic mode. This disciplined approach consistently achieves motor swap completion within a four-hour maintenance window, protecting both the production schedule and the integrity of the original RAPID program logic.
Retrofit Support FAQ
Q1: Is the ABB 3HAC024782-003 a direct drop-in replacement for the original IRB 6620 axis motor?
Yes. The 3HAC024782-003 is dimensionally and electrically identical to the original OEM motor. It uses the same flange pattern, resolver connector, and motor power connector, allowing installation without adapter plates or wiring modifications. Axis calibration must be re-performed after installation using the standard FlexPendant routine.
Q2: Will I need to modify the RAPID program or system parameters after replacing the motor?
No RAPID program modification is required. System parameters related to motor type and resolver configuration remain unchanged. The only post-installation step is re-recording the axis calibration offset, which is a standard procedure that takes approximately 15–30 minutes per axis and does not alter the program logic or work object definitions.
Q3: What pre-shipment testing does SMARTNEXMSK perform on the 3HAC024782-003?
Every unit undergoes a full functional run-in test, winding insulation resistance measurement (Megger test), and dimensional inspection of the mounting flange and shaft. Units that pass all acceptance criteria are sealed, labeled with test results, and shipped with a 12-month warranty certificate. Test records are retained and available upon request.
Q4: What is covered under the 12-month warranty?
The 12-month warranty covers defects in materials and workmanship under normal operating conditions. It includes free replacement or repair of the unit if a verified manufacturing defect is identified within the warranty period. The warranty does not cover damage resulting from incorrect installation, overvoltage events, contamination, or mechanical impact. SMARTNEXMSK’s technical team is available to assist with installation guidance to help customers avoid warranty-voiding conditions.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341