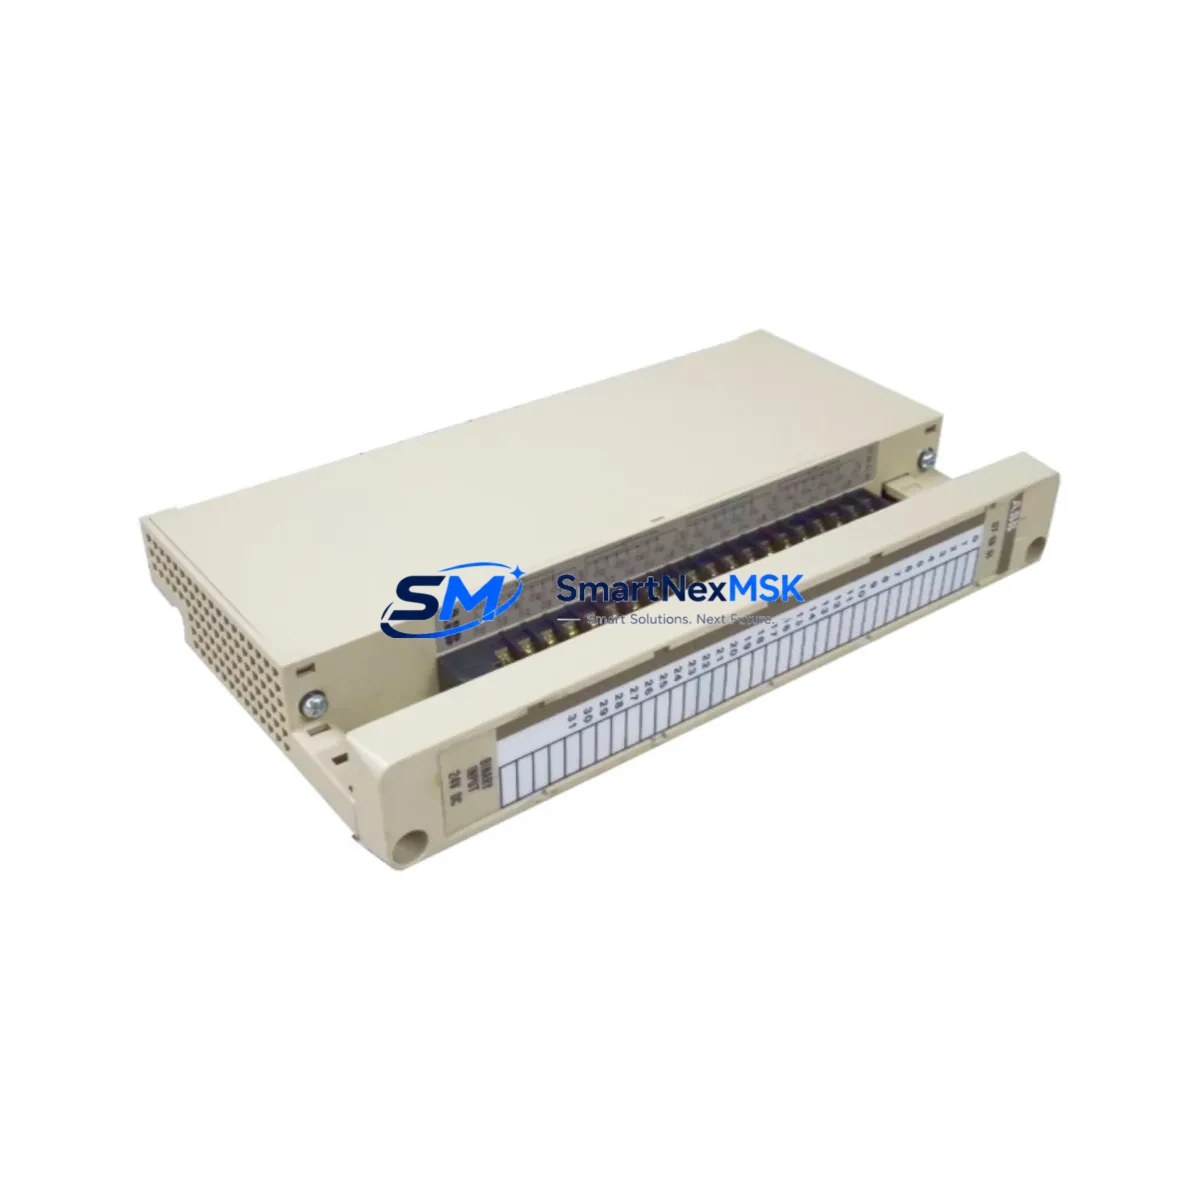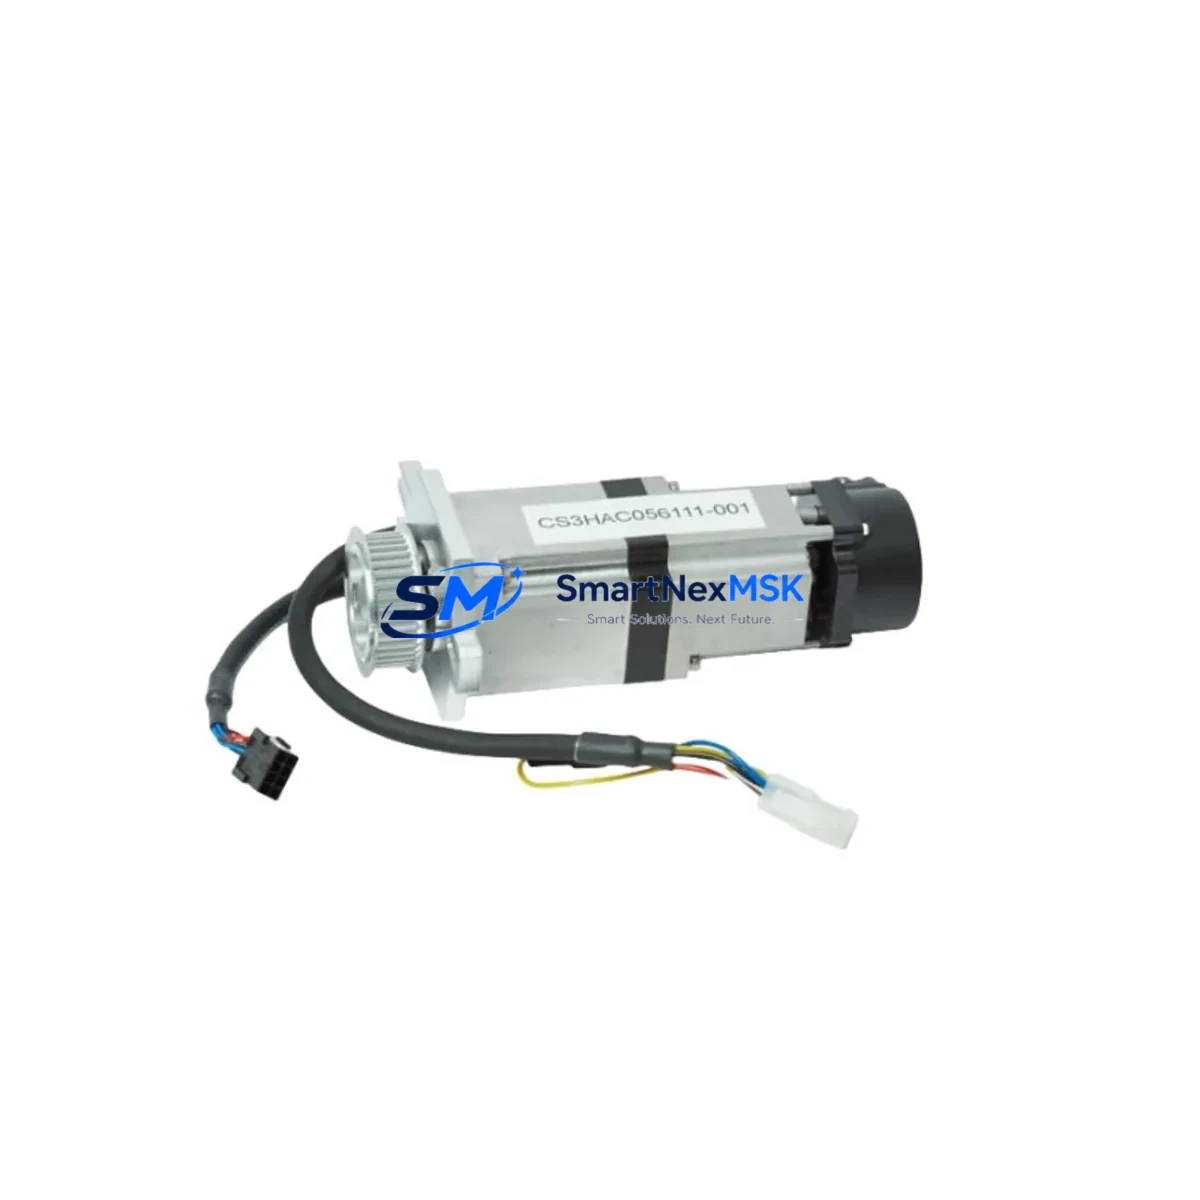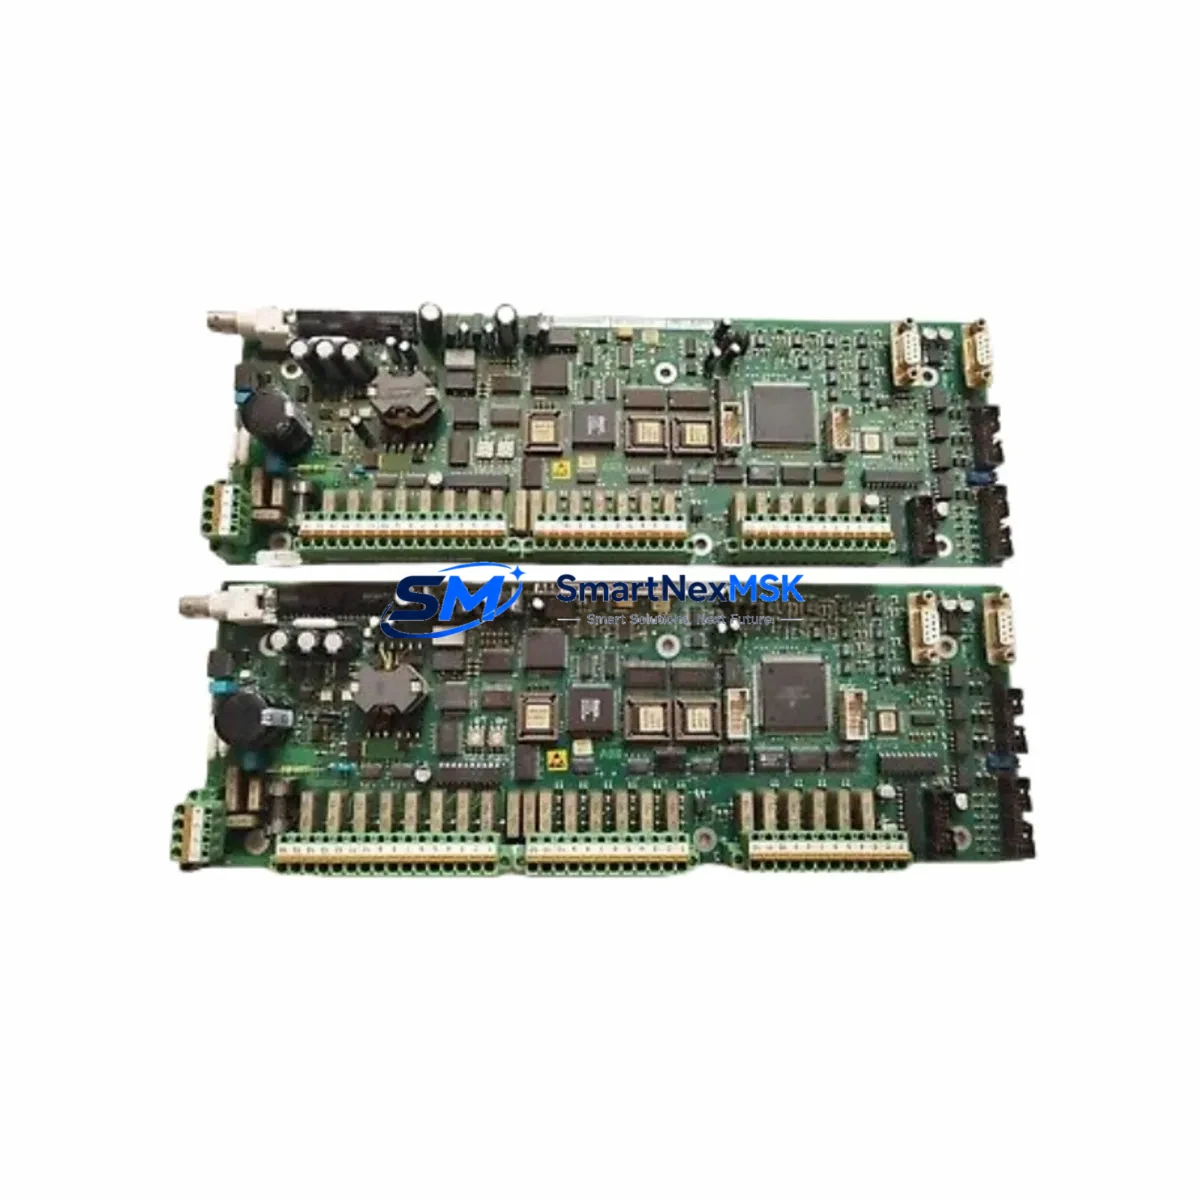
ABB 3HAC028837-001 Retrofit-Ready Reduction Gear for IRB4600 Control Systems
The ABB 3HAC028837-001 is a precision reduction gear unit engineered for the IRB4600 series industrial robot, one of ABB’s most widely deployed six-axis articulated arms in automotive, general manufacturing, and material handling applications. As legacy IRB4600 installations age beyond their original service cycles, the 3HAC028837-001 has become a critical retrofit component for maintenance engineers and system integrators tasked with extending robot service life without full platform replacement. This unit provides a direct mechanical and dimensional match to the original factory specification, enabling smooth integration into existing robot cells with minimal downtime and no requirement for structural modification to the robot base or arm assembly.
Whether you are replacing a worn axis-1 or axis-2 gearbox on an IRB4600/20, IRB4600/45, or IRB4600/60 variant, the 3HAC028837-001 is the correct OEM-equivalent reduction gear to restore full torque capacity, positional repeatability, and load-bearing performance. Procurement teams sourcing discontinued ABB spare parts for multi-robot production lines will find this unit available from verified stock with a 12-month warranty covering manufacturing defects and functional performance.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Models | ABB IRB4600/20, IRB4600/45, IRB4600/60 |
| Replacement For | 3HAC028837-001 (OEM equivalent); also applicable where 3HAC028837-009 is referenced |
| Axis Position | Axis 1 / Axis 2 gearbox (confirm axis assignment with robot serial number documentation) |
| Mounting Interface | Direct bolt-on to IRB4600 base casting; no adapter plate required |
| Communication Compatibility | Mechanical component; compatible with IRC5 controller and RobotWare 5.x / 6.x |
| Installation Requirement | Torque calibration via RobotStudio or IRC5 FlexPendant required post-installation |
| Commissioning Focus | Fine calibration of axis zero position, load data re-entry, and collision detection threshold reset |
| Warranty | 12 months from date of shipment — covers manufacturing defects and functional performance |
| Origin | Germany (OEM-grade manufacturing) |
| Lead Time | In stock — ships within 2 business days |
Retrofit Planning for Existing Automation Systems
A successful IRB4600 gearbox retrofit begins well before the replacement unit arrives on site. Engineers should pull the robot’s service history from the IRC5 controller event log and cross-reference accumulated operating hours against ABB’s recommended gearbox service intervals. In most production environments, the 3HAC028837-001 is replaced alongside the axis gearbox oil (ABB Gearbox Oil 3HAB3537-1) and the associated motor seal kit to prevent secondary failures after the robot returns to service.
Before disassembly, back up the current calibration data using RobotStudio connected to the IRC5 controller via the service port. The IRC5 controller stores axis calibration offsets in its RAPID system parameters, and these values must be preserved and re-applied after the new gearbox is installed and torqued to specification. If the robot is part of a coordinated multi-robot cell managed by a PLC — such as an ABB AC500 series controller or a Siemens S7-300 — the cell PLC program should be placed in manual hold mode to prevent unintended motion commands during the mechanical swap.
The IRC5 controller’s axis computer board (3HAC026254-001) communicates resolver feedback from the motor encoder through the measurement board (3HAC025562-001). After gearbox replacement, verify that resolver signals are clean and within tolerance using the IRC5 FlexPendant’s axis calibration wizard. Any deviation in resolver offset will manifest as positional drift or TCP (Tool Center Point) error, which will affect downstream process quality — particularly in welding, dispensing, or assembly applications where the IRB4600 is commonly deployed.
For robots integrated with external vision systems or force-torque sensors mounted at the wrist — such as the ABB IRBPA positioner or an ATI force-torque sensor connected through the robot’s signal harness (3HAC031683-001) — confirm that the wrist flange alignment is within the specified angular tolerance after gearbox installation. Misalignment at the flange will propagate errors into the vision calibration matrix and require a full hand-eye calibration cycle before production can resume.
In facilities running multiple IRB4600 units on the same production line, it is advisable to maintain a minimum of one 3HAC028837-001 unit in local spare parts inventory alongside the IRC5 drive module (3HAC025338-001) and the robot’s teach pendant cable (3HAC031683-001). This ensures that an unplanned gearbox failure does not result in extended line stoppage while waiting for international freight. Our team can assist with consignment stock arrangements for high-volume customers managing fleets of five or more IRB4600 robots.
Downtime Control During System Migration
Minimizing production downtime during an IRB4600 gearbox replacement requires a structured pre-shutdown checklist and a disciplined commissioning sequence. The following approach has been validated across multiple automotive and electronics manufacturing retrofit projects:
Pre-Shutdown (Day Before): Export the full RAPID program backup from the IRC5 controller using RobotStudio. Document the current axis calibration offsets from the SMB (Serial Measurement Board) memory. Photograph the existing cable routing around the gearbox housing to ensure identical re-routing after installation. Confirm that the replacement 3HAC028837-001 unit has been inspected and matches the robot’s axis specification.
During Replacement: Place the IRC5 controller in maintenance mode and lock out the robot’s main power isolator. Remove the axis motor (3HAC17484-3 or equivalent) before extracting the gearbox to avoid damaging the motor shaft seal. Install the new 3HAC028837-001 gearbox, apply the correct gearbox oil fill volume as specified in the IRB4600 product manual (3HAC026876-001), and re-install the motor with fresh motor flange gasket.
Post-Installation Commissioning: Restore the RAPID program backup to the IRC5 controller. Run the axis calibration routine using the FlexPendant. Perform a slow-speed (25% override) dry-run cycle of the full robot program to verify TCP accuracy before returning to production speed. If the robot is part of a SafeMove2 safety configuration, re-validate all safety zones and speed limits through the IRC5 safety controller before releasing the robot to automatic mode.
With proper preparation, total planned downtime for a 3HAC028837-001 gearbox replacement on an IRB4600 can be contained to 4–8 hours, including commissioning and test cycles. Unplanned replacements without prior calibration backup typically require 12–24 hours due to the need for full TCP re-calibration from scratch.
Retrofit Support FAQ
Q: Is the 3HAC028837-001 a direct drop-in replacement for the original ABB gearbox on the IRB4600?
A: Yes. The 3HAC028837-001 is dimensionally and mechanically equivalent to the original factory-installed gearbox on IRB4600 series robots. No adapter plates, machining, or structural modifications are required. Standard ABB installation torque specifications apply.
Q: Will I need to re-calibrate the robot after installing the 3HAC028837-001?
A: Yes. Axis calibration is always required after any gearbox replacement. The IRC5 controller’s calibration routine via the FlexPendant will guide you through the zero-position calibration process. We strongly recommend backing up your existing calibration data before disassembly to minimize commissioning time.
Q: Does the 3HAC028837-001 work with both RobotWare 5.x and RobotWare 6.x?
A: Yes. As a mechanical component, the 3HAC028837-001 is software-agnostic. It is compatible with all IRC5 controller variants running RobotWare 5.14 and above, including RobotWare 6.x. No firmware changes are required on the IRC5 controller or the axis computer board.
Q: What warranty does this unit carry, and what does it cover?
A: Every 3HAC028837-001 unit shipped by SMARTNEXMSK carries a 12-month warranty from the date of shipment. The warranty covers manufacturing defects, dimensional non-conformance, and functional performance failure under normal operating conditions. Pre-shipment functional inspection records are available upon request. Warranty claims are processed within 5 business days of receipt of the returned unit.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341