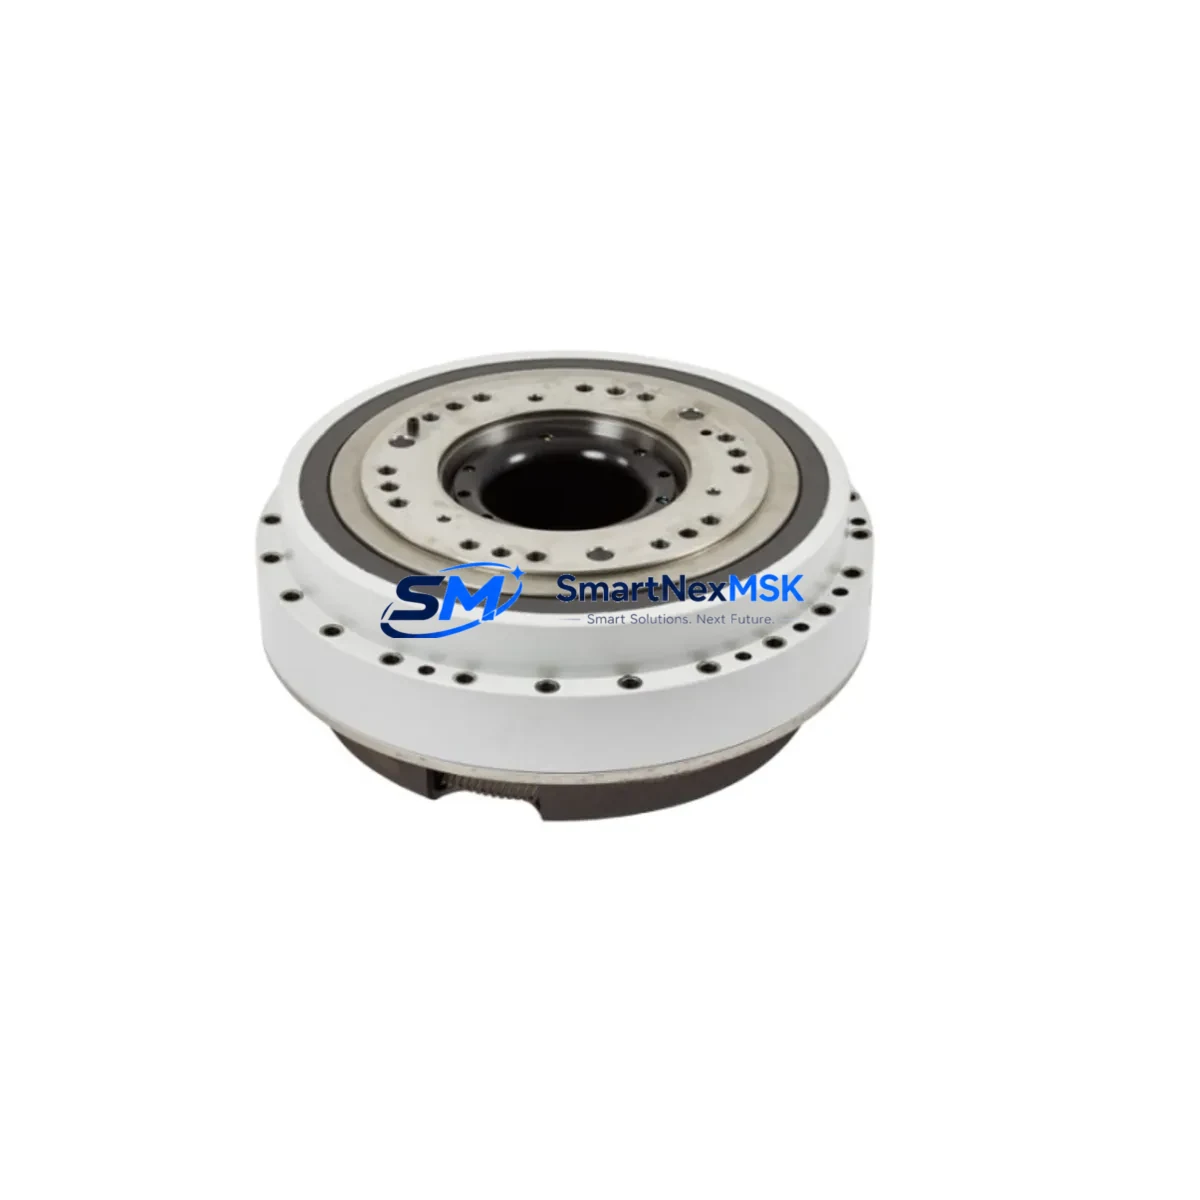
ABB 3HAC028837-006 Retrofit-Ready Axis Gearbox for IRB 4600 Control Systems
The ABB 3HAC028837-006 is a precision-engineered axis gearbox designed as a direct retrofit replacement for the IRB 4600 series industrial robot platform. As ABB continues to evolve its robotics lineup, many facilities operating legacy IRB 4600 units face the challenge of sourcing discontinued spare parts, managing aging drivetrain components, and maintaining production continuity without committing to a full robot replacement. The 3HAC028837-006 addresses this challenge directly — offering a mechanically and electrically compatible drop-in solution that restores full axis performance with minimal downtime and no reprogramming of the robot controller.
Whether your facility is executing a planned maintenance overhaul, responding to an unexpected gearbox failure, or upgrading a multi-robot cell as part of a broader automation modernization initiative, the 3HAC028837-006 provides the reliability and compatibility assurance that industrial engineers require. This unit is sourced, inspected, and dispatched from our Xiamen warehouse with a 12-month warranty covering manufacturing defects and functional performance.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| SKU / Part Number | 3HAC028837-006 |
| Compatible Robot Series | ABB IRB 4600 (all variants: IRB 4600-20/2.50, IRB 4600-45/2.05, IRB 4600-60/2.05) |
| Axis Position | Axis 1 / Axis 2 (confirm axis designation with robot serial number before ordering) |
| Mounting Interface | Direct bolt-on; matches OEM flange pattern and housing dimensions |
| Electrical Compatibility | Compatible with ABB IRC5 controller and associated servo drive modules |
| Communication Protocol | No protocol change required; integrates with existing PROFIBUS, DeviceNet, or EtherNet/IP configurations on the IRC5 panel |
| Replacement Recommendation | Recommended for units showing backlash deviation >0.05°, abnormal vibration, or oil seal failure |
| Commissioning Requirement | Fine calibration via RobotStudio or FlexPendant required post-installation; revolution counter update mandatory |
| Warranty | 12 months from date of shipment; covers manufacturing defects and functional failure under normal operating conditions |
| Origin | China (CN) — dispatched from Xiamen |
Retrofit Planning for Existing Automation Systems
Replacing the 3HAC028837-006 gearbox within an active production environment requires careful pre-planning across mechanical, electrical, and software domains. Before initiating the swap, engineers should verify the robot’s current calibration offsets stored in the ABB IRC5 controller and back up the RAPID program modules to a USB or network share. The IRC5 cabinet typically houses the main computer unit, axis computer boards, and drive units — all of which remain untouched during a gearbox replacement, but their configuration data must be preserved.
On the mechanical side, confirm that the replacement gearbox flange torque ratings match the payload configuration of your specific IRB 4600 variant. For cells running the IRB 4600-60/2.05 at maximum payload, the axis 1 gearbox experiences significantly higher cyclic stress than lighter-duty variants, and the installation torque sequence for the mounting bolts must follow ABB’s specified pattern to avoid housing distortion.
Electrically, the motor resolver cable and brake connector routed through the robot’s internal cable harness — often referenced alongside the 3HAC026253-001 motor cable assembly — should be inspected for insulation wear during the gearbox removal process. This is a common opportunity to replace aging wiring before reassembly. The servo motor itself, typically an ABB 3HAC17484-1 or 3HAC14550-2 series motor depending on axis position, should be tested for winding resistance and insulation integrity before reinstallation.
For facilities also managing I/O expansion or safety circuit upgrades within the same maintenance window, the ABB DSQC 652 digital I/O board and DSQC 643 power distribution unit inside the IRC5 cabinet are common co-replacement items. If the robot cell communicates with a Siemens S7-300 or S7-1500 PLC via PROFIBUS DP, verify that the GSD file and hardware configuration in TIA Portal or STEP 7 remain consistent after any cabinet-level changes. Similarly, if the cell uses an ABB CP600 HMI panel or a third-party SCADA interface, confirm that the robot status tags and alarm mappings are unaffected by the maintenance event.
Facilities upgrading multiple IRB 4600 units simultaneously should also assess whether the ABB 3HAC025338-001 SMB battery unit (serial measurement board battery) requires replacement — these are frequently overlooked during gearbox overhauls but are critical for maintaining axis position memory during power-off cycles. Replacing the SMB battery alongside the gearbox eliminates a common source of post-maintenance calibration drift.
Downtime Control During System Migration
Minimizing unplanned downtime during a gearbox retrofit on an IRB 4600 begins with pre-staging all replacement components before the maintenance window opens. The 3HAC028837-006 should be on-site and bench-verified at least 48 hours before the scheduled outage. This includes a visual inspection of the output flange, oil fill level check, and confirmation that the part number and revision code match the robot’s BOM.
During the swap, the robot’s RAPID program should remain loaded in the IRC5 controller memory — do not perform a system restore or P-disk format unless specifically required. After mechanical installation, the revolution counter update procedure via the FlexPendant (IRC5 teach pendant) is the most critical commissioning step. Skipping or incorrectly executing this step is the leading cause of post-retrofit axis positioning errors. Follow the axis-by-axis calibration sequence documented in ABB’s Product Manual for IRB 4600 (document 3HAC026876-001).
For cells where continuous production is critical, consider a parallel-robot strategy: bring a pre-configured spare IRB 4600 unit online while the primary robot undergoes gearbox replacement. This approach, combined with pre-tested replacement modules and a structured commissioning checklist, can reduce effective production downtime to under four hours for experienced maintenance teams. All configuration data — including tool data, work object frames, load data, and safety zone definitions — should be validated against the original backup before returning the robot to automatic mode.
Retrofit Support FAQ
Q1: Is the 3HAC028837-006 a direct drop-in replacement for all IRB 4600 variants?
The 3HAC028837-006 is compatible with the IRB 4600 series across the primary payload variants (20 kg, 45 kg, and 60 kg). However, axis position (Axis 1 vs. Axis 2) must be confirmed against your robot’s serial number and the ABB spare parts catalog before ordering. Contact our technical team with your robot serial number for confirmation.
Q2: Will I need to reprogram the IRC5 controller after replacing the gearbox?
No RAPID program reprogramming is required. The existing program logic, tool data, and work object configurations remain valid. The only mandatory software step is the revolution counter update via the FlexPendant, followed by a fine calibration check. Back up your system data before beginning the mechanical replacement as a precaution.
Q3: How do I verify wiring compatibility before installation?
The 3HAC028837-006 uses the same motor mounting interface and internal cable routing as the original OEM gearbox. Inspect the motor resolver connector, brake cable, and power connector for pin configuration against ABB’s circuit diagram (available in the IRB 4600 product manual). If the existing cable harness shows signs of wear, replace it during the same maintenance window to avoid a secondary outage.
Q4: What does the 12-month warranty cover, and how is it claimed?
The 12-month warranty covers manufacturing defects, premature bearing failure, oil seal integrity, and functional performance under normal industrial operating conditions. It does not cover damage resulting from improper installation, overloading beyond rated specifications, or contamination. To initiate a warranty claim, contact [email protected] with your order reference, robot serial number, and a description of the fault. Our team will coordinate return logistics and replacement dispatch.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341