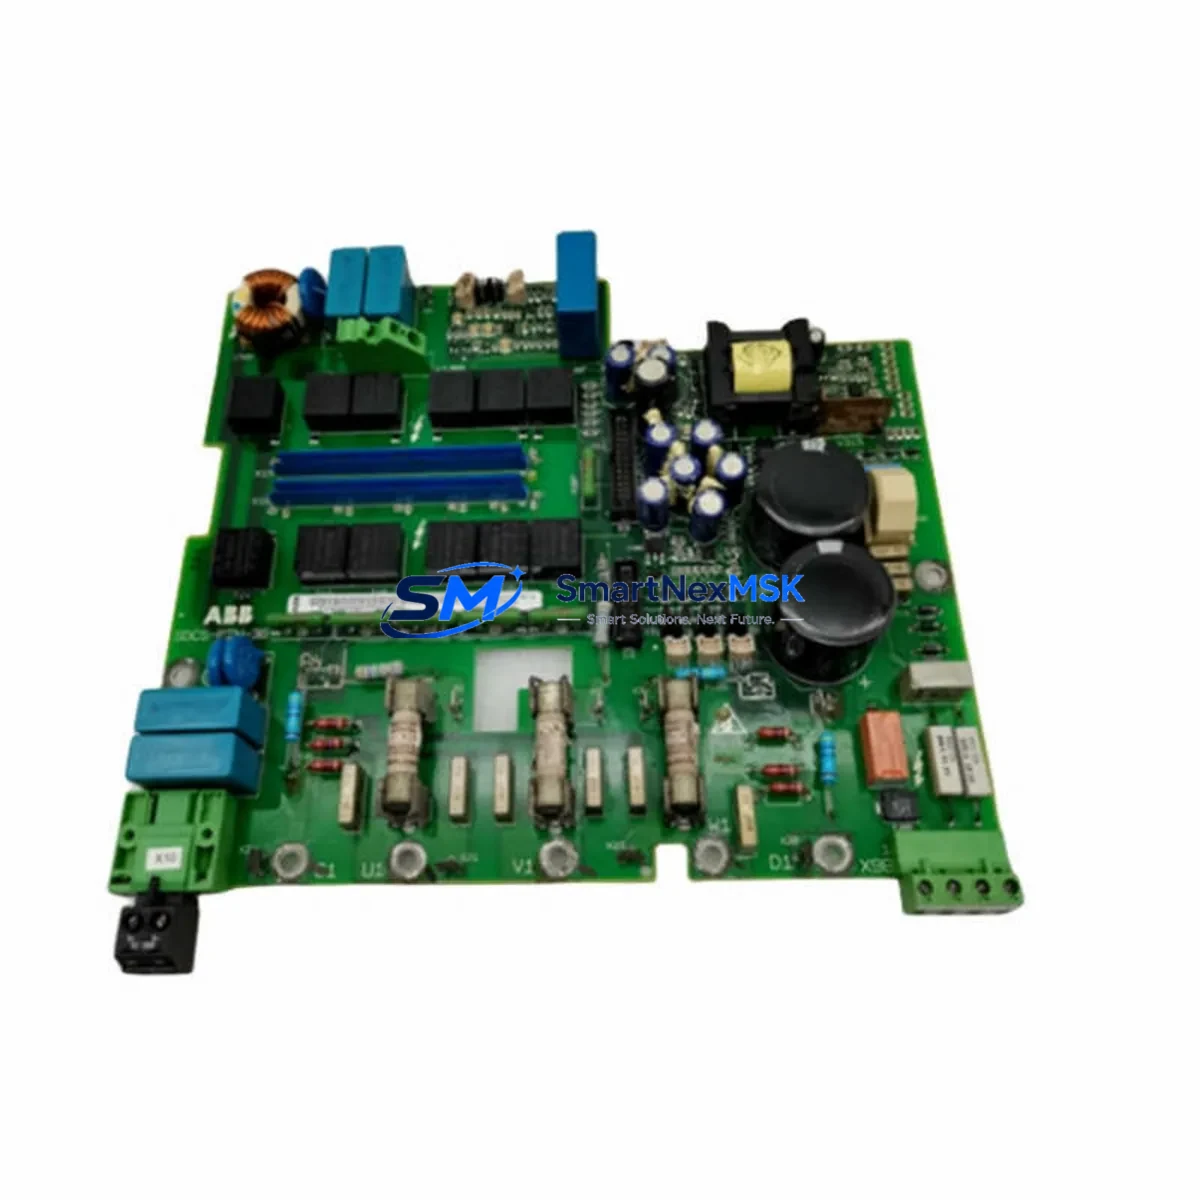
ABB 3HAC028889-001 Spare for IRB 6660 Automation: Spare Parts Replacement & Downtime Risk Control
The ABB 3HAC028889-001 is an original servo motor unit designed for the IRB 6660 heavy-duty industrial robot series, widely deployed in press-tending, foundry, and machine-tending automation cells. As a maintenance-ready spare, this component is critical to axis drive continuity — particularly for Axis 1 and Axis 2 drive configurations where motor failure directly triggers unplanned production stops. Sourced from verified supply channels and tested prior to dispatch, each unit ships with a 12-month warranty and full compatibility confirmation against the IRB 6660 mechanical interface and ABB IRC5 controller ecosystem.
For maintenance engineers managing aging IRB 6660 installations, the 3HAC028889-001 represents a direct replacement path that eliminates the need for mechanical adaptation or firmware reconfiguration. The motor’s encoder interface, mounting flange geometry, and connector pinout are fully compatible with the original installation, enabling same-shift replacement under planned or emergency maintenance conditions. Procurement engineers will find this unit available for immediate dispatch from bonded stock, with documentation packages available upon request for incoming inspection and asset registration.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | 3HAC028889-001 |
| Cross-Reference SKUs | 3HAC028068-001 / IRT501-663 / HAWC116592-/00 |
| Brand | ABB |
| Compatible Robot Series | IRB 6660 (all variants) |
| Controller Compatibility | ABB IRC5 / IRC5 Compact |
| Component Type | AC Servo Motor — Axis Drive Unit |
| Origin | Sweden (OEM) |
| Mounting Interface | Direct flange replacement — no mechanical adaptation required |
| Encoder Type | Resolver / Absolute encoder (per original axis configuration) |
| Connector Pinout | OEM-matched — plug-and-play with existing harness |
| Operating Environment | Industrial — foundry, press-tending, machine-tending cells |
| Pre-Shipment Testing | Functional test performed on each unit before dispatch |
| Warranty | 12 Months from date of delivery |
| Lead Time | In stock — same-day or next-business-day dispatch available |
| Documentation | Test report, datasheet, and compliance certificate available on request |
Maintenance Planning for Continuous Operation
When replacing the 3HAC028889-001 servo motor in an IRB 6660 cell, a thorough maintenance review of the surrounding electrical and mechanical subsystems is strongly recommended. Servo motor failures in heavy-duty robot installations are rarely isolated events — they are frequently preceded or accompanied by degradation in adjacent components that share the same power distribution and signal routing infrastructure.
Begin with the ABB DSQC661 drive unit or equivalent axis computer board within the IRC5 cabinet: check for fault logs, thermal discoloration, and capacitor condition. The 3HAC025338-001 motor cable assembly connecting the servo to the drive should be inspected for insulation wear, connector corrosion, and continuity — cable harness degradation is a leading cause of premature motor failure in high-cycle press-tending applications. Verify the 3HAC026254-001 power supply module output voltage stability under load, as undervoltage conditions accelerate servo winding stress.
I/O integrity should be confirmed at the DSQC652 digital I/O board level — check for stuck outputs or intermittent input signals that may have contributed to abnormal motor loading. The 3HAC14550-1 SMB (Serial Measurement Board) should be tested for resolver signal quality, as a degraded SMB can cause axis position errors that mask underlying motor faults. If the installation includes a 3HAC026254-001 rectifier unit, verify DC bus voltage ripple is within specification.
For cells with extended runtime histories, inspect the 3HAC020812-001 brake unit for holding torque consistency — a worn brake can cause axis drift that places abnormal load on the servo during hold cycles. Terminal blocks and Phoenix Contact or Weidmüller rail-mount terminals within the control cabinet should be re-torqued and inspected for oxidation, particularly in foundry environments with elevated particulate contamination. Finally, confirm that the FlexPendant (IRC5 teach pendant) and associated DSQC679 main computer board are logging no persistent axis-related fault codes that could indicate a systemic drive issue beyond the motor itself.
Site Replacement Workflow
The 3HAC028889-001 is designed as a direct drop-in replacement for the original servo motor in the IRB 6660 axis assembly. The replacement workflow follows standard ABB field service procedure and does not require mechanical re-engineering or controller reconfiguration under normal conditions.
Step 1 — Isolation & Lockout: De-energize the IRC5 cabinet and apply LOTO (Lockout/Tagout) per site safety protocol. Confirm zero-energy state at the axis drive terminals before proceeding.
Step 2 — Motor Removal: Disconnect the motor cable harness (power and resolver/encoder connectors), release the mounting flange bolts per the IRB 6660 product manual torque specification, and extract the motor assembly. Record the axis calibration offset values from the FlexPendant before disconnection.
Step 3 — Inspection & Cleaning: Inspect the motor mounting bore, gear interface, and cable routing channel for contamination or mechanical damage. Clean mating surfaces before installing the replacement unit.
Step 4 — Installation: Mount the 3HAC028889-001 to the axis assembly, torque flange bolts to specification, and reconnect the cable harness. Verify connector seating and locking clip engagement.
Step 5 — Calibration & Commissioning: Restore axis calibration offsets via the FlexPendant. Perform a slow-speed jog test across the full axis range before returning the cell to production speed. Log the replacement in the maintenance management system with the new unit’s serial number and warranty start date.
This workflow supports a target replacement time of under 4 hours for a trained field technician, minimizing production downtime and enabling same-shift recovery in most planned maintenance scenarios.
Spare Parts Support FAQ
Q1: Is the 3HAC028889-001 compatible with all IRB 6660 variants, including the IRB 6660-205/1.9 and IRB 6660-130/3.1?
Yes. The 3HAC028889-001 is the OEM-specified servo motor for the IRB 6660 series across standard payload and reach variants. Compatibility with your specific axis configuration can be confirmed by providing your robot serial number and axis designation — our technical team will verify the correct part match before dispatch.
Q2: What pre-shipment testing is performed on each unit?
Each 3HAC028889-001 unit undergoes functional electrical testing prior to dispatch, including winding resistance measurement, insulation resistance check, and encoder/resolver signal verification. A test report is available upon request and can be included with the shipment for incoming inspection and quality records.
Q3: How should this spare be stored if held in a maintenance inventory buffer?
Store in original packaging in a dry, temperature-controlled environment (5–40°C, <85% RH non-condensing). Avoid proximity to strong magnetic fields or vibration sources. Rotate stock on a first-in, first-out basis and inspect packaging integrity annually. Units held in buffer stock for more than 24 months should be functionally tested before deployment.
Q4: What does the 12-month warranty cover, and how is a warranty claim initiated?
The 12-month warranty covers manufacturing defects and functional failure under normal operating conditions from the date of delivery. It does not cover damage resulting from incorrect installation, overvoltage events, or contamination ingress. To initiate a warranty claim, contact [email protected] with the order reference, unit serial number, and a description of the fault. Replacement or repair will be arranged within the warranty period without additional charge.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341