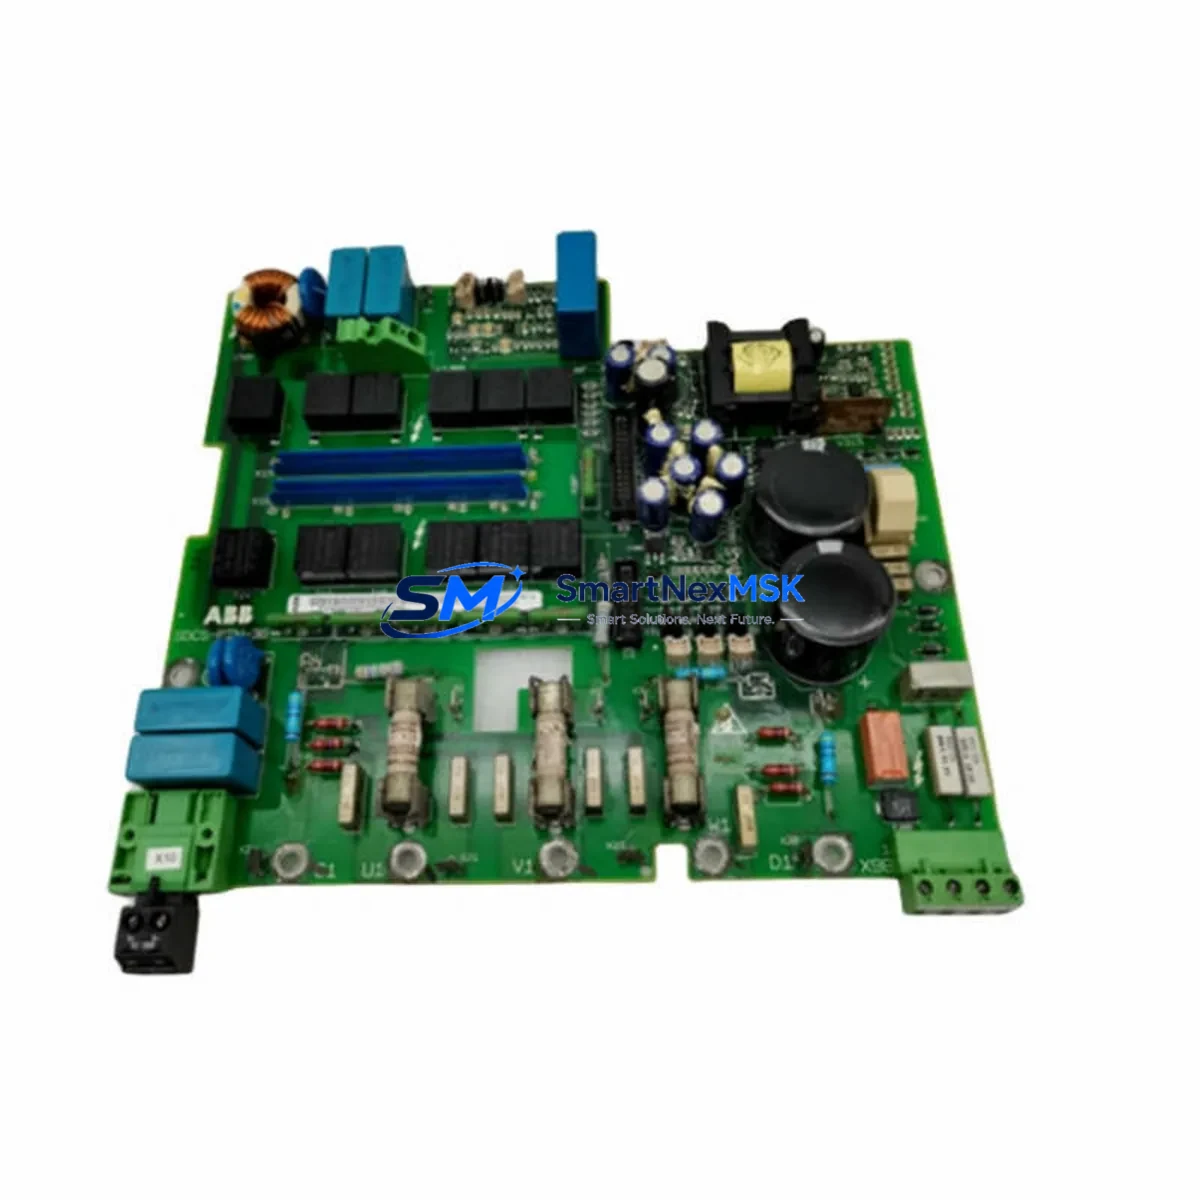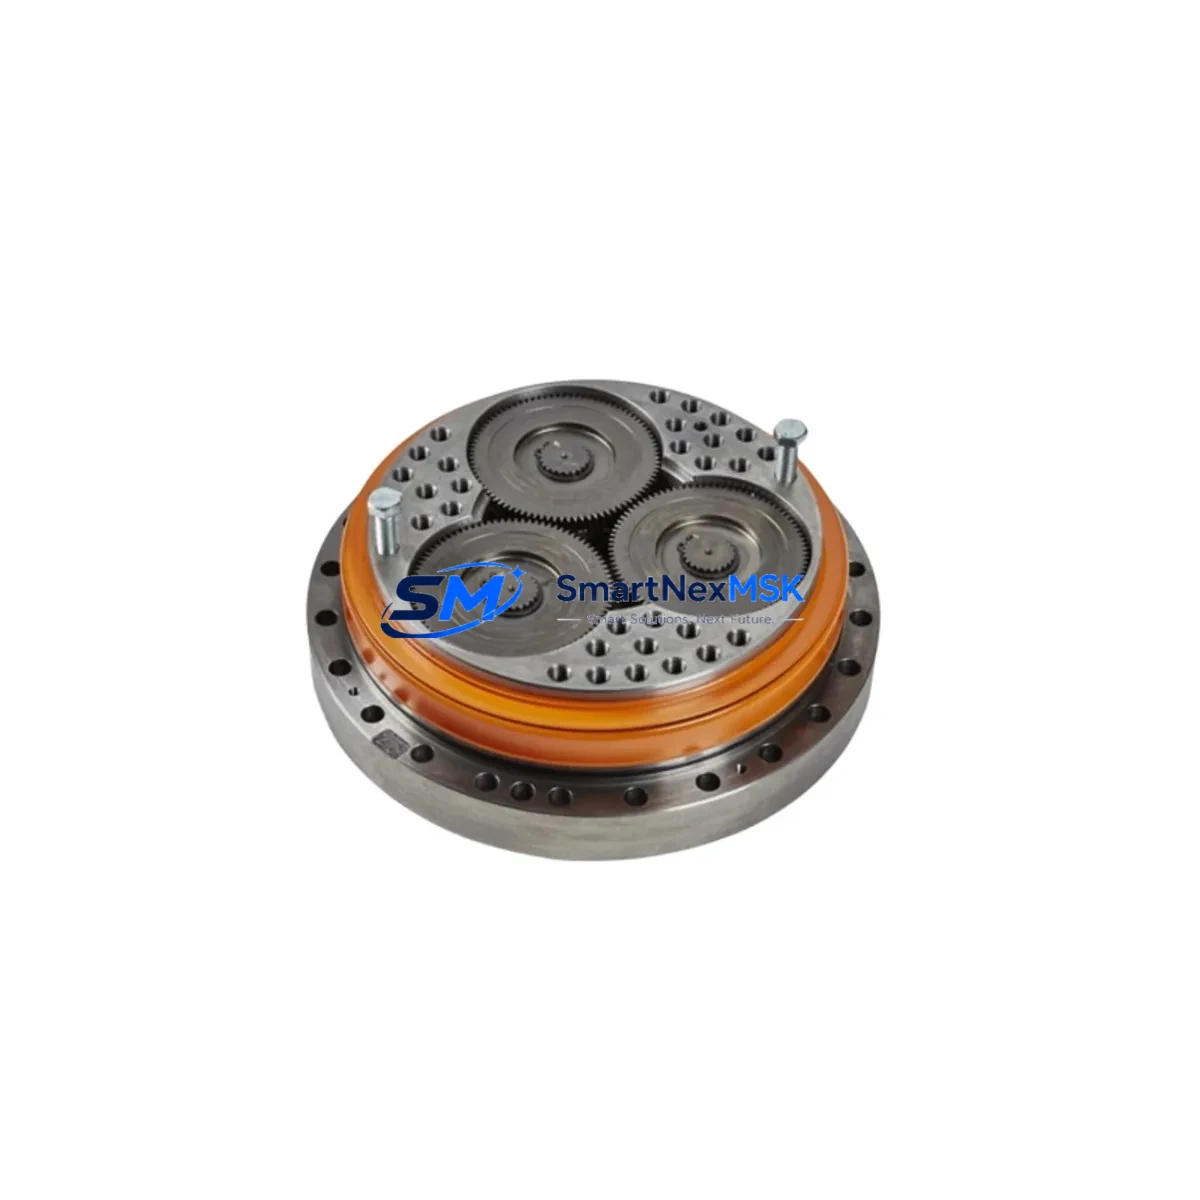
ABB 3HAC033413-001 Retrofit-Ready AC Servo Motor for IRB 1520ID Control Systems
The ABB 3HAC033413-001 is a precision AC servo motor engineered for the IRB 1520ID arc welding robot series, and it remains one of the most sought-after retrofit components for facilities managing aging ABB robot cells. As production lines built around the IRB 1520ID approach end-of-support cycles, procurement teams and automation engineers increasingly rely on verified replacement units to sustain throughput without committing to full robot replacement. This unit is stocked, tested, and shipped with a 12-month warranty, making it a dependable choice for both emergency breakdown recovery and planned maintenance upgrades.
The 3HAC033413-001 is mechanically and electrically compatible with the original axis drive configuration of the IRB 1520ID. It interfaces directly with the ABB DSQC3060 drive unit and is designed to operate within the S4C+ and IRC5 controller environments. Engineers replacing a failed motor on an active welding line will find that the mounting flange dimensions, encoder connector pinout, and shaft geometry match OEM specifications, minimizing the need for mechanical adaptation during installation.
When planning a retrofit around this motor, it is essential to verify the power supply capacity of the existing control cabinet. The IRB 1520ID typically draws axis power through a dedicated servo power module, and any degradation in the cabinet’s power conditioning components — such as the 3HAC050411-001 axis computer or associated rectifier assemblies — should be addressed before commissioning the replacement motor. Overlooking upstream power quality is a common cause of premature motor failure in retrofit scenarios.
Upgrade Compatibility Table
| Parameter | Detail |
|---|---|
| Replacement SKU | 3HAC033413-001 |
| Compatible Robot | ABB IRB 1520ID (Arc Welding Variant) |
| Compatible Controller | IRC5, S4C+ |
| Drive Interface | ABB DSQC3060 |
| Related Axis Computer | 3HAC050411-001 |
| Encoder Type | Resolver / Absolute Encoder (OEM spec) |
| Mounting Interface | OEM flange — no mechanical adaptation required |
| Communication Compatibility | DeviceNet, PROFIBUS (via IRC5 option boards) |
| Installation Requirement | Axis calibration required post-swap; backup SMB data before removal |
| Commissioning Note | Restore revolution counter; verify fine calibration via FlexPendant |
| Warranty | 12 Months — covers manufacturing defects and functional failure |
| Condition | New / Refurbished OEM — tested prior to shipment |
Retrofit Planning for Existing Automation Systems
A successful retrofit of the 3HAC033413-001 into an active IRB 1520ID cell requires a structured approach that accounts for both mechanical and software dependencies. Before removing the failed motor, engineers should back up the SMB (Serial Measurement Board) data using the IRC5 FlexPendant. The SMB stores revolution counter values for all axes, and losing this data will require a full mechanical calibration — a time-consuming process that extends downtime significantly.
The IRB 1520ID’s axis 1 and axis 2 motors are the most frequently replaced in arc welding applications due to the continuous rotational demands of torch positioning. When replacing the 3HAC033413-001, it is advisable to simultaneously inspect the 3HAC064211-001 cabling harness for insulation wear, as heat cycling in welding environments accelerates cable degradation. A worn harness can cause intermittent encoder faults that mimic motor failure, leading to unnecessary component replacement.
The control cabinet housing the IRC5 controller typically contains several interdependent modules that should be assessed during any motor retrofit. The DSQC3060 drive unit, which directly powers and controls the servo motor, should be tested for output voltage stability before the new motor is connected. If the drive unit shows signs of capacitor aging or IGBT degradation, replacing the motor alone will not resolve recurring fault codes. In parallel, the 3HAC050411-001 axis computer should be checked for firmware currency — outdated firmware can cause compatibility issues with replacement motors that carry updated encoder specifications.
For facilities running multiple IRB 1520ID cells, it is common practice to maintain a small buffer stock of critical consumable modules. Beyond the servo motor itself, recommended spares include the SMB board, the teach pendant cable assembly, and at least one spare DSQC3060 drive unit. Facilities that have migrated from S4C+ to IRC5 controllers should also verify that their existing I/O modules — particularly any 24VDC digital I/O expansion cards — are correctly mapped in the new controller configuration, as address assignments can shift during controller upgrades.
Communication protocol continuity is another critical consideration. IRB 1520ID cells integrated into larger manufacturing execution systems via PROFIBUS or DeviceNet must maintain their node addresses and baud rate settings throughout the motor swap. If the IRC5 controller is rebooted during the retrofit, the fieldbus configuration should be verified against the original network topology before resuming production. Any HMI screens linked to robot status signals should also be tested to confirm that axis position feedback and fault relay outputs are functioning correctly after the motor replacement.
Downtime Control During System Migration
Minimizing downtime during a servo motor replacement on an active welding line requires preparation that begins well before the maintenance window opens. The most effective strategy is to pre-stage the replacement 3HAC033413-001 unit alongside all required tools, torque specifications, and a printed copy of the axis calibration procedure. Having the FlexPendant calibration routine pre-loaded and the SMB backup verified before the line stops can reduce the mechanical swap and recommissioning window to under four hours for experienced technicians.
Program logic preservation is non-negotiable. The RAPID program stored in the IRC5 controller should be backed up to a USB memory device before any hardware intervention. This backup should include the system parameters, I/O configuration, and any custom EIO (Electronic I/O) signal definitions that control weld start, arc OK, and wire feed sequences. Restoring from a verified backup eliminates the risk of parameter drift that can occur when controllers are power-cycled unexpectedly during a fault condition.
For facilities that cannot tolerate extended downtime, a parallel commissioning approach is recommended: configure and test the replacement motor on a spare robot or test rig before bringing it to the production cell. This allows the calibration data to be pre-validated and the motor’s thermal behavior to be confirmed under load before it enters service. Combined with a pre-negotiated 12-month warranty on the replacement unit, this approach provides both operational continuity and financial protection against early failure.
Retrofit Support FAQ
Q: Is the 3HAC033413-001 a direct drop-in replacement for the original IRB 1520ID servo motor?
A: Yes. The 3HAC033413-001 matches the OEM mechanical interface, encoder connector, and electrical specifications of the original motor. No mechanical adaptation is required. Post-installation axis calibration via the IRC5 FlexPendant is mandatory to restore fine calibration data.
Q: What wiring checks should be performed before connecting the replacement motor?
A: Verify the motor power cable insulation resistance using a megohmmeter before reconnecting. Inspect the encoder cable shield continuity and confirm that the DSQC3060 drive unit output terminals are within specification. Any terminal corrosion or loose crimps in the cabinet wiring should be remediated before powering up the new motor.
Q: How is compatibility with the IRC5 controller confirmed?
A: The IRC5 controller identifies the motor through the SMB data and the drive unit configuration. After installing the 3HAC033413-001, update the revolution counter via the FlexPendant calibration menu and verify that no axis configuration fault codes are active. If the controller was previously running S4C+ firmware, confirm that the IRC5 system parameters include the correct motor model definition for this SKU.
Q: What does the 12-month warranty cover, and what is the shipping lead time?
A: The 12-month warranty covers manufacturing defects and functional failure under normal operating conditions. Each unit is tested prior to shipment. In-stock units typically ship within 1–3 business days. Expedited shipping is available for emergency breakdown situations. Contact our team for availability confirmation and lead time on your specific quantity requirement.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341