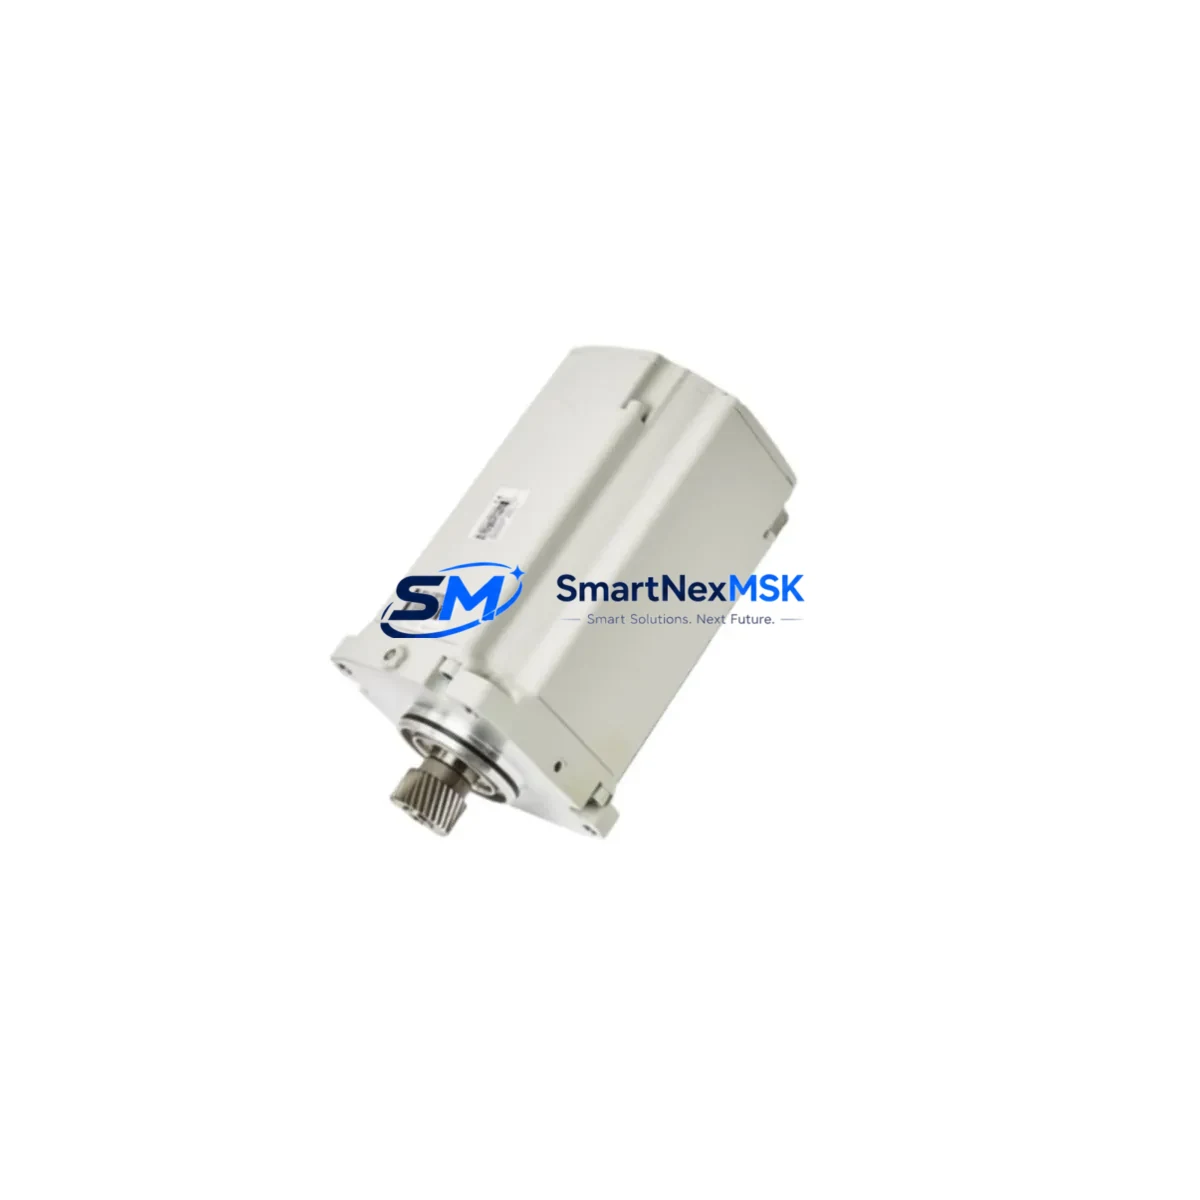
ABB 3HAC034526-001 Retrofit-Ready AC Servo Motor for IRB 660/760 Control Systems
The ABB 3HAC034526-001 is a precision AC servo motor engineered for seamless integration into IRB 660 and IRB 760 industrial robot platforms. As legacy automation lines face increasing pressure from discontinued OEM spare parts and aging drive systems, this unit delivers a verified drop-in retrofit path that preserves existing wiring harnesses, mechanical mounting geometry, and motion controller compatibility. Whether you are executing a planned upgrade cycle or responding to an unplanned axis failure, the 3HAC034526-001 is stocked, tested, and ready to ship with a 12-month warranty.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Platforms | ABB IRB 660, IRB 760 |
| OEM Part Number | 3HAC034526-001 |
| Motor Type | AC Servo Motor (Brushless) |
| Mounting Interface | Direct bolt-on; matches OEM flange pattern |
| Connector / Wiring | OEM-compatible motor power and resolver/encoder connectors; no re-pinning required |
| Drive Compatibility | Compatible with ABB DSQC drive units and IRC5 controller drive modules |
| Communication | Resolver feedback; compatible with IRC5 motion control board |
| Replacement Recommendation | Direct replacement for worn, failed, or discontinued 3HAC034526-001 units |
| Commissioning Notes | Motor calibration offset update via RobotStudio or FlexPendant required after swap |
| Warranty | 12 Months — covers manufacturing defects and functional failure under normal operating conditions |
Retrofit Planning for Existing Automation Systems
Retrofitting an IRB 660 or IRB 760 axis servo motor requires a structured approach to avoid secondary failures and extended downtime. Before removing the failed unit, engineers should document the current axis calibration data stored in the IRC5 controller — this data is critical for restoring accurate TCP (Tool Center Point) positioning after the swap. The IRC5 controller cabinet typically houses the DSQC 661 or DSQC 663 drive units that interface directly with the 3HAC034526-001 motor’s resolver feedback signal; confirming drive firmware compatibility before installation prevents resolver signal mismatch errors at startup.
On the mechanical side, verify that the gearbox output shaft and motor coupling are within tolerance before fitting the replacement unit. In high-cycle palletizing applications — common for the IRB 660’s 250 kg payload class — coupling wear is frequently the root cause of premature motor failure. Replacing the 3HAC034526-001 without inspecting the ABB gearbox unit (such as the 3HAC028357-001 gearbox assembly for axis 1) risks repeating the failure within a short interval.
For the electrical side, the motor power cable assembly (3HAC031683-001) and the resolver cable (3HAC031684-001) should be inspected for insulation damage, connector pin corrosion, and cable routing stress points — particularly at the cable management arm exit points. If the robot has accumulated significant operating hours, proactive replacement of these cable assemblies alongside the servo motor eliminates a common source of intermittent faults post-retrofit.
The IRC5 controller’s axis computer board (DSQC 668) manages the motion profile for each axis. After installing the 3HAC034526-001, a fine calibration routine must be executed using the FlexPendant or RobotStudio software to update the motor calibration offset stored in the system parameters. Skipping this step results in positional drift and potential collision with fixtures or peripheral equipment. If the robot is integrated with an ABB SafeMove safety module, the safety configuration must also be re-validated after the motor swap to maintain functional safety certification.
In multi-robot cells where the IRB 660 or IRB 760 operates alongside conveyor systems, vision systems, or collaborative peripherals, coordinating the retrofit window with the broader cell PLC — often a Siemens S7-300 or Allen-Bradley ControlLogix managing the cell sequence — is essential. The cell controller’s robot interface signal (typically via DeviceNet or PROFINET) should be placed in a safe hold state before power is removed from the IRC5 cabinet to prevent sequence faults that could corrupt the robot program memory.
Downtime Control During System Migration
Minimizing production downtime during a servo motor replacement on an IRB 660 or IRB 760 begins with pre-staging. Having the 3HAC034526-001 on-site and pre-inspected before the maintenance window opens eliminates the most common source of extended downtime: waiting for parts. Our standard lead time for in-stock units is 1–3 business days to most global destinations, with expedited shipping available for critical line-down situations.
Before the maintenance window, back up the complete robot system — including RAPID programs, system parameters, I/O configuration, and SafeMove parameters — to a USB drive via the IRC5 FlexPendant. This backup protects against data loss if the controller requires a restart during the swap procedure. The backup also captures the current motor calibration offsets, which serve as a reference baseline if the post-swap calibration produces unexpected results.
During the swap, follow ABB’s documented axis motor replacement procedure for the IRB 660/760 series, paying particular attention to the torque specifications for the motor mounting bolts and the correct seating of the resolver connector. An improperly seated resolver connector is the leading cause of “resolver error” faults at first power-on after a motor replacement — a fault that can add 30–60 minutes to the commissioning process if not identified immediately.
After mechanical installation and electrical reconnection, perform a controlled power-on sequence: enable the IRC5 controller in manual mode, clear any accumulated fault logs, and execute the motor calibration update before switching to automatic mode. Run the robot through a slow-speed dry cycle across the full axis range to verify smooth motion, correct direction, and absence of abnormal current draw on the drive unit before returning the cell to production speed. This structured commissioning sequence typically allows a full axis motor swap to be completed within a 4–6 hour planned maintenance window.
Retrofit Support FAQ
Q: Is the 3HAC034526-001 a direct drop-in replacement for the original ABB motor on the IRB 660 and IRB 760?
A: Yes. The 3HAC034526-001 matches the OEM mechanical mounting pattern, motor power connector, and resolver connector of the original factory-installed unit. No adapter plates or re-pinning are required. A motor calibration offset update via the IRC5 FlexPendant is required after installation, which is standard procedure for any servo motor replacement on ABB robot platforms.
Q: What commissioning steps are required after installing the replacement motor?
A: After mechanical and electrical installation, you must perform a motor calibration update using the IRC5 controller’s calibration routine (accessible via FlexPendant or RobotStudio). If SafeMove is installed, re-validate the safety configuration. Run a slow-speed dry cycle across the full axis range before returning to production. Full commissioning documentation is available from ABB’s service manual for the IRB 660/760 series.
Q: How do I verify wiring compatibility before installation?
A: Compare the motor power cable assembly (3HAC031683-001) and resolver cable (3HAC031684-001) connector types on your existing installation against the replacement unit. Both connectors on the 3HAC034526-001 are OEM-standard and should mate directly. If your robot has been previously modified or repaired with non-OEM cables, verify pin assignments against the IRB 660/760 electrical diagram before powering on.
Q: What does the 12-month warranty cover?
A: The 12-month warranty covers manufacturing defects and functional failure under normal operating conditions from the date of shipment. It includes free replacement or repair of the unit. The warranty does not cover damage resulting from incorrect installation, electrical overvoltage, mechanical impact, or operation outside the motor’s rated specifications. Our technical team is available to support pre-installation verification to help ensure a successful retrofit.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341