ABB 3HAC037639-001 Retrofit-Ready Servo Motor for IRB 7600: Compatible Upgrade for Legacy Axis Drive Systems
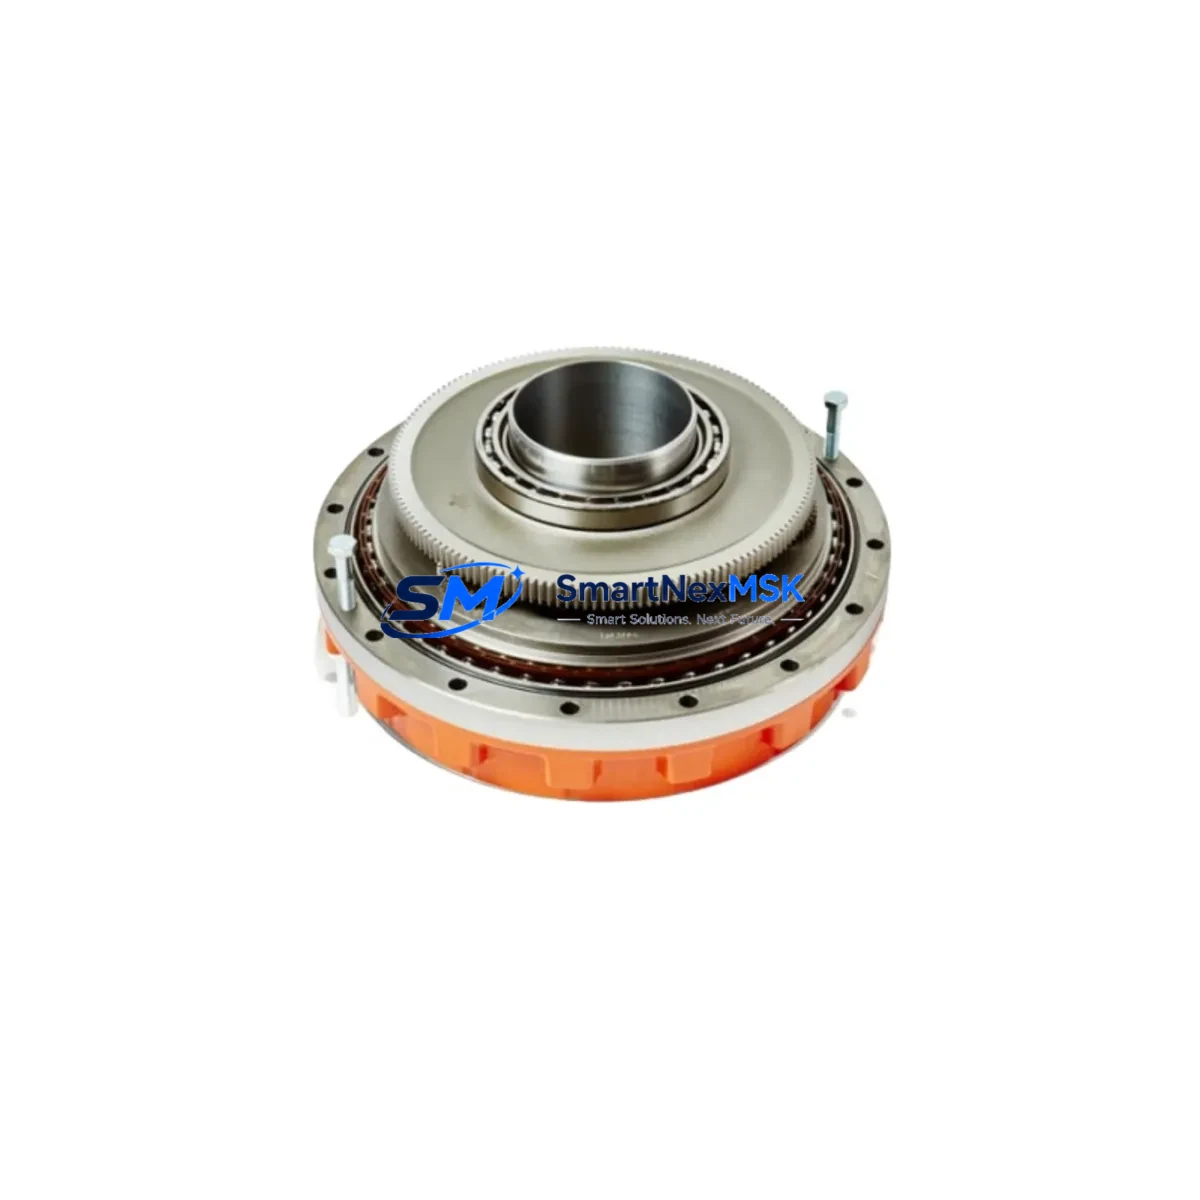
The ABB 3HAC037639-001 is a precision servo motor with integrated pinion, purpose-engineered for the IRB 7600 series industrial robot platform. As ABB’s large-payload robot line continues to operate across heavy manufacturing, foundry, and press-tending environments, the demand for verified replacement and retrofit-grade components has grown significantly. SMARTNEXMSK maintains in-stock inventory of the 3HAC037639-001 to support planned overhauls, emergency breakdowns, and phased modernization programs — with a 12-month warranty on every unit shipped.
Whether you are replacing a failed axis motor on an aging IRB 7600/500, upgrading a refurbished robot cell, or sourcing a spare for a multi-robot line, the 3HAC037639-001 is the correct OEM-specification component for Axis 1 drive applications on this platform. Each unit is pre-tested prior to dispatch and ships with full documentation to support your commissioning team.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Series | ABB IRB 7600 (all variants: /150, /325, /400, /500) |
| Replaces / Supersedes | 3HAC037639-001, 3HAC037639-002 (cross-reference verified) |
| Axis Application | Axis 1 (base rotation drive) |
| Motor Type | AC Servo Motor with Pinion |
| Mounting Interface | Direct bolt-on to IRB 7600 base casting; OEM flange pattern |
| Encoder / Resolver Compatibility | Compatible with ABB IRC5 controller resolver feedback chain |
| Communication Protocol | Integrated with IRC5 drive unit via standard ABB axis computer bus |
| Power Supply Requirement | Verify drive unit capacity before installation; consult IRC5 drive module ratings |
| Commissioning Requirement | SMB (Serial Measurement Board) calibration required after replacement |
| Retrofit Recommendation | Replace SMB battery (3HAC044075-001) simultaneously to avoid recalibration repeat |
| Warranty | 12 Months — covers manufacturing defects and functional failure under normal operating conditions |
Retrofit Planning for Existing Automation Systems
Replacing the 3HAC037639-001 in an active production environment requires careful pre-planning to protect both the robot’s mechanical integrity and the integrity of the control program. Before beginning the swap, engineers should verify the IRC5 controller cabinet configuration — specifically the drive unit (DSQC 661 or equivalent) and the axis computer (DSQC 668) to confirm firmware compatibility with the replacement motor’s resolver signal chain.
The SMB (Serial Measurement Board, 3HAC031670-001) stores axis calibration data and revolution counters. When the 3HAC037639-001 is removed, the SMB data for Axis 1 is invalidated. Teams must back up the current calibration offsets from RobotStudio or the FlexPendant before disconnecting the motor. After installation, a full revolution counter update and fine calibration procedure must be performed using the calibration pendulum or laser tool, depending on the robot’s original calibration method.
For robots integrated into a larger cell, the IRC5 panel board (DSQC 1000) and the I/O modules — such as the DSQC 652 digital I/O unit or DSQC 378B fieldbus adapter — should be inspected during the same maintenance window. Replacing the servo motor while the cabinet is open is an efficient opportunity to check terminal block integrity, inspect the teach pendant cable (3HAC028357-001), and verify the condition of the axis 1 brake resistor circuit.
If the robot is part of a MultiMove configuration or operates under coordinated motion with a positioner (such as the IRBP series), the motion configuration in the IRC5 must be reviewed after axis 1 recalibration to ensure coordinated path accuracy is maintained. Any changes to the robot’s base frame or tool data should be re-verified in RobotStudio before resuming production.
For older IRB 7600 installations still running S4C+ controllers, a controller upgrade to IRC5 may be the appropriate long-term path. In such cases, the 3HAC037639-001 motor remains mechanically compatible, but the drive interface and cabling harness will require adaptation. SMARTNEXMSK can advise on the correct cable assembly and connector kit for cross-generation retrofits.
Downtime Control During System Migration
Minimizing unplanned downtime during a servo motor replacement on the IRB 7600 begins with pre-staging. Before the maintenance window opens, the replacement 3HAC037639-001 should be on-site, inspected, and confirmed against the robot’s serial number and axis configuration. The IRC5 controller’s RAPID program should be backed up to a USB drive or network share, and the current system parameters — including motion configuration, I/O signal maps, and safety configuration — should be exported from the controller.
During the swap, the robot must be placed in a mechanically safe position with Axis 1 locked using the mechanical brake or a physical support fixture. The drive unit should be powered down and the DC bus discharged before any connector is touched. Labeling all connectors on the motor — including the resolver cable, power cable, and brake cable — before disconnection prevents wiring errors during reinstallation.
After the 3HAC037639-001 is installed and all connectors are secured, the IRC5 should be powered up in manual mode. The revolution counter update for Axis 1 must be completed before any automatic mode operation is attempted. Once calibration is confirmed, a slow-speed test cycle should be run to verify smooth motion, correct direction, and absence of fault codes on the axis computer. Only after this verification should the robot be returned to automatic production mode.
For facilities running 24/7 operations, SMARTNEXMSK recommends maintaining one 3HAC037639-001 as a cold spare in the maintenance store. Given the lead times associated with OEM channels, having a pre-tested spare on the shelf reduces mean time to repair (MTTR) from days to hours.
Retrofit Support FAQ
Q1: Is the 3HAC037639-001 a direct drop-in replacement for the 3HAC037639-002?
Yes. The 3HAC037639-002 is a revision of the same part number family and is mechanically and electrically interchangeable with the 3HAC037639-001 in all IRB 7600 axis 1 applications. Both part numbers are cross-referenced in ABB’s spare parts documentation. SMARTNEXMSK ships whichever revision is in current stock, and both carry the same 12-month warranty.
Q2: What calibration steps are required after replacing the servo motor?
After installing the 3HAC037639-001, you must perform a revolution counter update for Axis 1 using the FlexPendant. If the robot uses fine calibration (laser or pendulum method), the full calibration procedure must also be repeated. Failure to update the revolution counter will result in incorrect axis positioning and potential collision risk. Always back up the existing calibration data before beginning the replacement.
Q3: Can this motor be installed on an IRB 7600 running an S4C+ controller?
The 3HAC037639-001 is mechanically compatible with IRB 7600 robots regardless of controller generation. However, the drive interface and resolver cabling differ between S4C+ and IRC5 systems. An adapter harness and drive unit review are required for S4C+ installations. Contact SMARTNEXMSK’s technical team for guidance on the correct interface components for your specific controller revision.
Q4: What does the 12-month warranty cover, and what is the shipping timeline?
The 12-month warranty covers manufacturing defects and functional failure under normal operating conditions from the date of delivery. It does not cover damage resulting from incorrect installation, electrical overstress, or mechanical impact. SMARTNEXMSK ships from in-stock inventory with standard lead times of 3–7 business days for international orders. Express shipping options are available for emergency breakdown situations. All units are functionally tested before dispatch.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341