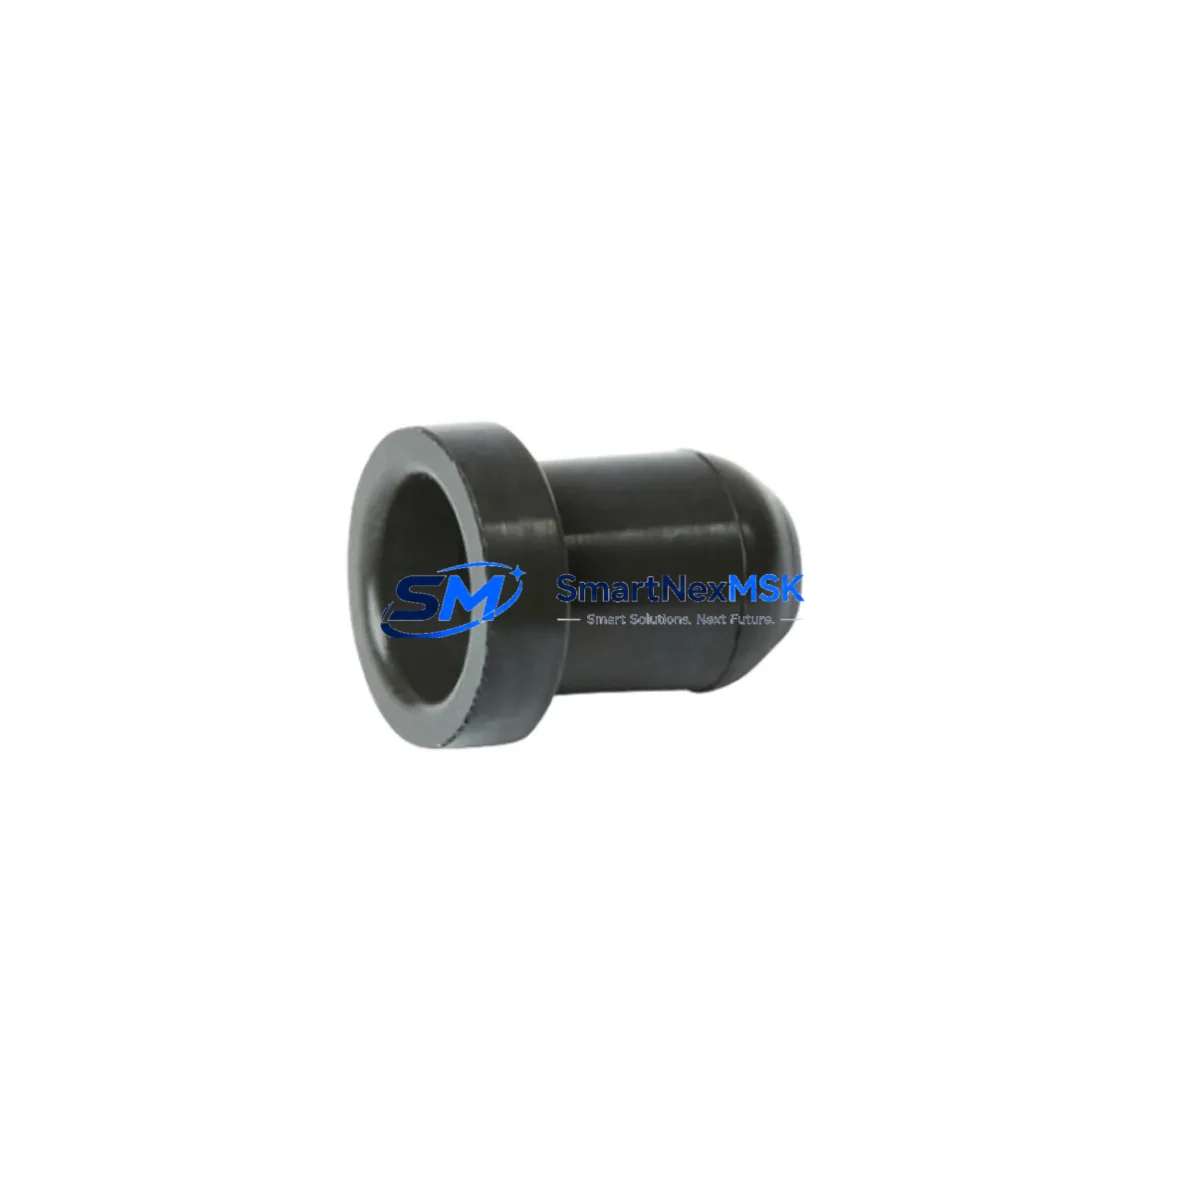
ABB 3HAC040500-001 Retrofit-Ready Wrist Seal for IRB6700 Control Systems
The ABB 3HAC040500-001 is a precision wrist joint cap seal engineered for the IRB6700 series of industrial robots. As production lines age and original sealing components reach end-of-life, this part serves as the primary retrofit solution for facilities operating IRB6700/150, IRB6700/200, IRB6700/235, and IRB6700/300 variants. Whether you are executing a planned maintenance overhaul, responding to an unplanned seal failure, or upgrading an older IRB6640 or IRB6650 installation to the IRB6700 platform, the 3HAC040500-001 provides a direct-fit, OEM-compatible replacement that restores full IP67 ingress protection at the wrist axis.
This seal is also cross-referenced against 3HAC048318-001 and the legacy part number 4N4785, making it the correct selection for engineers sourcing replacements across multiple ABB robot generations. Before installation, technicians should verify the wrist housing condition on the axis-6 gearbox, confirm that the mating surface on the IRB6700 wrist unit is free of scoring, and inspect the adjacent grease nipple and lubrication channel for blockage. A damaged mating surface will compromise the new seal regardless of part quality.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Part Number | 3HAC040500-001 |
| Cross-Reference / Supersedes | 3HAC048318-001, 4N4785 |
| Compatible Robot Series | IRB6700 (all payload variants: /150, /200, /235, /300) |
| Upgrade Path From | IRB6640, IRB6650 (with wrist housing adapter verification) |
| Installation Interface | Axis-6 wrist housing, press-fit / snap-fit retention |
| Ingress Protection Restored | IP67 (dust-tight, immersion-resistant) |
| Communication Compatibility | No electrical interface; mechanical seal only |
| Retrofit Requirement | Confirm mating surface condition; re-grease per 3HAC065034-001 lubrication schedule |
| Debugging Focus | Leak test after installation; verify axis-6 torque within ABB IRC5 controller alarm thresholds |
| Country of Origin | Germany (ABB Robotics) |
| Warranty | 12 Months — covers manufacturing defects under normal operating conditions |
Retrofit Planning for Existing Automation Systems
A successful retrofit of the 3HAC040500-001 seal requires a structured approach that accounts for the broader robot cell architecture. In most IRB6700 installations, the robot is controlled by an IRC5 controller cabinet, which houses the main computer module (DSQC1000 or DSQC679), drive units, and the panel board. Before taking the robot offline for seal replacement, engineers should export the current RAPID program from RobotStudio and confirm that the backup includes all module files, system parameters, and EIO configuration. This protects program logic in the event that a controller restart is required after maintenance.
On the mechanical side, the wrist seal replacement typically coincides with a broader axis-6 service interval. Technicians commonly inspect or replace the axis-6 gearbox oil seal, check the condition of the wrist harness and signal cable bundle routed through the upper arm, and verify the integrity of the tool flange. If the robot is equipped with an integrated media flange or a process cable package, these assemblies must be disconnected and re-routed carefully to avoid pinching during reassembly.
For facilities running multiple IRB6700 units on the same production line, it is advisable to maintain a small buffer stock of 3HAC040500-001 seals alongside related consumables such as the axis-1 through axis-5 sealing kits, gearbox oil (ABB specification), and the standard grease cartridge used for the wrist lubrication point. Lines that also operate IRB6640 robots should note that the wrist seal geometry differs and that the 3HAC040500-001 is not a direct drop-in for the IRB6640 without confirming the housing revision level.
Where the retrofit involves migrating from an older S4C+ or IRC5 M2004 controller to a current IRC5 M2016 or OmniCore C30 platform, the seal replacement is best scheduled concurrently with the controller upgrade to minimize total downtime. The OmniCore C30 controller introduces a new SafeMove2 safety configuration, and the axis-6 parameters — including speed limits and zone definitions — must be re-validated after any mechanical intervention on the wrist. The FlexPendant or RobotStudio Safety Configurator should be used to confirm that all safety zones remain intact before returning the robot to automatic mode.
Facilities that use ABB’s Ability™ condition monitoring service can cross-reference the seal replacement date against the vibration and temperature trend data logged for axis 6. An anomalous rise in axis-6 motor temperature or an increase in positional deviation alarms in the IRC5 event log are common early indicators of wrist seal degradation, and this data should be archived as part of the maintenance record.
Downtime Control During System Migration
Minimizing unplanned downtime during a wrist seal replacement on the IRB6700 begins with preparation. The 3HAC040500-001 seal should be on-hand before the maintenance window opens — waiting for parts after a seal failure can extend downtime from hours to days. SMARTNEXMSK maintains in-stock inventory of this part to support same-day or next-business-day dispatch for urgent retrofit requirements.
The recommended procedure is to schedule the seal replacement during a planned production break or shift changeover. Before powering down the IRC5 controller, the operator should place the robot in a maintenance-safe posture (typically the calibration position), engage the mechanical brake release procedure per the IRB6700 product manual, and lock out the main power isolator. The RAPID program should remain untouched on the controller memory; there is no need to reload software for a mechanical seal replacement unless a full controller reset is performed for unrelated reasons.
After the new 3HAC040500-001 seal is seated and the wrist assembly is torqued to specification, the robot should be jogged manually through the full axis-6 range of motion at reduced speed before returning to automatic mode. The IRC5 controller’s axis calibration should be verified using the revolution counter update procedure if the axis-6 resolver was disturbed during disassembly. This step is critical for maintaining TCP (Tool Center Point) accuracy and preventing positional errors that could affect weld seams, pick-and-place targets, or dispensing paths.
For lines where continuous operation is essential, a spare robot or a pre-configured swap unit can be staged in advance. The RAPID program, EIO table, and system parameters can be transferred to the spare unit via USB or network backup, allowing the production cell to resume within minutes of the mechanical swap rather than waiting for a full recommissioning cycle.
Retrofit Support FAQ
Q1: Is the 3HAC040500-001 a direct replacement for 3HAC048318-001 and 4N4785?
Yes. The 3HAC040500-001 supersedes both 3HAC048318-001 and the legacy 4N4785 part number. All three references describe the same wrist joint cap seal for the IRB6700 series. When ordering, use 3HAC040500-001 as the current active part number to ensure you receive the latest revision.
Q2: What pre-installation checks are required before fitting the new seal?
Inspect the axis-6 wrist housing bore for scoring, corrosion, or deformation. Clean the mating surface with a lint-free cloth and confirm that the grease channel is clear. If the housing bore is damaged, the seal will not hold pressure regardless of part quality. Also verify that the correct grease type is available for re-lubrication after installation per the ABB maintenance schedule.
Q3: Will replacing this seal require re-calibration of the IRC5 controller?
In most cases, no — provided the axis-6 resolver and motor are not disturbed. However, if the wrist unit is fully removed and reinstalled, a revolution counter update is required. This is performed via the FlexPendant under Calibration → Revolution Counter Update and takes approximately 5–10 minutes per axis.
Q4: What warranty coverage applies to this part?
All 3HAC040500-001 seals supplied by SMARTNEXMSK carry a 12-month warranty covering manufacturing defects under normal operating conditions. Warranty claims require the part number, purchase date, and a description of the failure mode. Seals damaged by improper installation, chemical exposure outside ABB specifications, or operation beyond rated IP67 conditions are not covered under warranty.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341