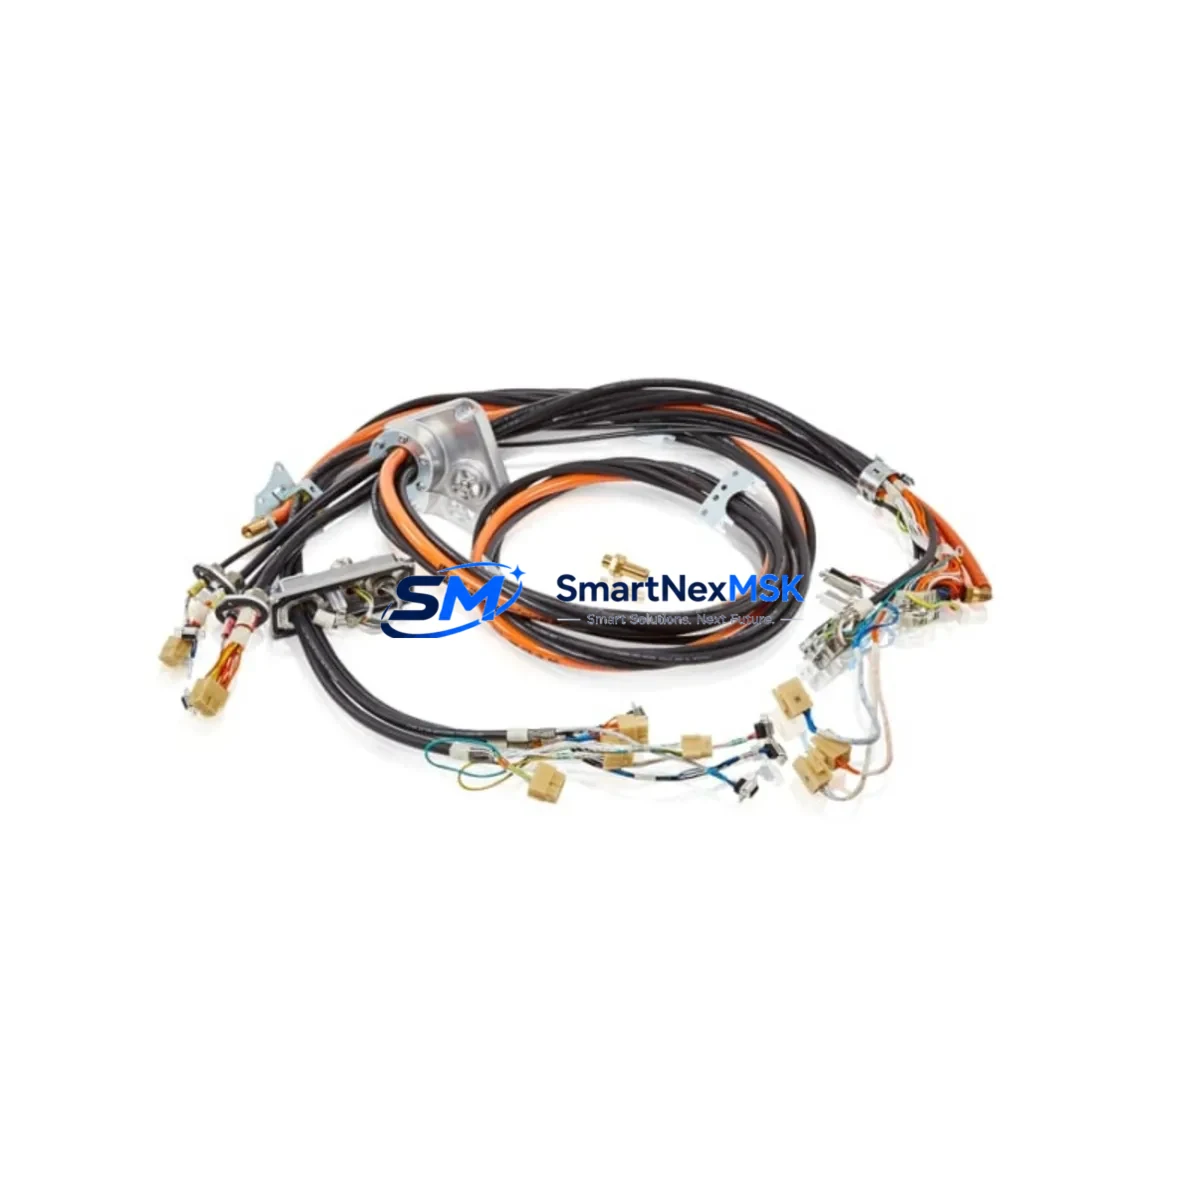
ABB 3HAC043963-001 Maintenance-Ready Spare for IRB 4600 Automation
The ABB 3HAC043963-001 is an original cable harness assembly engineered for ABB IRB 4600 and IRB 1600 series industrial robots. In high-cycle manufacturing environments — automotive body shops, arc welding cells, material handling lines, and precision assembly stations — the internal cable harness is one of the highest-wear components in the robot arm. Fatigue cracking, insulation breakdown, and connector corrosion are the leading causes of unplanned robot downtime. Stocking a verified 3HAC043963-001 spare is the single most effective step a maintenance team can take to compress mean time to repair (MTTR) and protect production continuity.
At SMARTNEXMSK, every 3HAC043963-001 unit is sourced from authorized supply channels, inspected against ABB dimensional and electrical specifications, and tested prior to shipment. Each unit ships with a 12-month warranty covering manufacturing defects and is packaged to prevent transit damage to the connector housings and cable jacket.
Spare Maintenance Table
| Parameter | Specification / Detail |
|---|---|
| Part Number | 3HAC043963-001 |
| Manufacturer | ABB Robotics (Sweden) |
| Compatible Series | IRB 4600, IRB 1600 |
| Component Type | Internal Cable Harness Assembly |
| Origin | Sweden (SE) |
| Connector Standard | ABB OEM multi-pin robot harness |
| Insulation Rating | Suitable for industrial robot arm flex cycles |
| Operating Environment | Industrial automation cells; welding, handling, assembly |
| Installation | Direct OEM replacement; no modification required |
| Pre-shipment Test | Continuity, insulation resistance, connector seating verified |
| Compatibility Verification | Cross-referenced against IRB 4600 and IRB 1600 BOM |
| Warranty | 12 Months — manufacturing defects covered |
| Lead Time | In-stock; ships within 1–3 business days |
| Long-term Supply | Available for repeat orders and blanket PO arrangements |
Maintenance Planning for Continuous Operation
When a 3HAC043963-001 cable harness failure is identified — whether through a robot fault alarm, axis position error, or visible jacket damage during a control cabinet inspection — the replacement procedure should be treated as a trigger for a broader preventive maintenance review. Experienced maintenance engineers know that a harness failure rarely occurs in isolation; adjacent components in the same electrical circuit are often stressed by the same root cause.
Before returning the robot to production after a 3HAC043963-001 swap, the following components should be inspected or tested as part of the same maintenance window:
Power and Drive: Check the ABB DSQC661 or DSQC662 drive unit for overcurrent events logged prior to the harness failure. A degraded harness can cause intermittent short-circuit conditions that stress the drive module. Inspect the 24 VDC power supply module (such as the DSQC609) for output voltage stability under load.
I/O and Signal Integrity: Verify the ABB DSQC652 digital I/O module for any latched fault states. Signal corruption caused by a failing harness can leave I/O modules in an undefined state even after the harness is replaced. If the robot is integrated into a safety circuit, test the safety relay module (e.g., DSQC643) for correct response to E-stop and safeguard inputs.
Communication Modules: If the cell uses DeviceNet or Profibus, inspect the DSQC378B or equivalent fieldbus adapter for connector integrity. A loose or corroded fieldbus connector can cause intermittent communication faults that are misdiagnosed as harness issues.
Connectors and Terminal Blocks: Inspect all Phoenix Contact or equivalent terminal blocks in the control cabinet for signs of heat discoloration, loose screws, or oxidation. Re-torque all power terminals to specification. Replace any terminal blocks showing signs of arcing.
HMI and Teach Pendant: After harness replacement, perform a full axis calibration using the FlexPendant (IRC5 teach pendant). Verify that all axis positions are within tolerance and that no resolver or encoder fault codes are active. If the IRC5 controller main computer (DSQC1000) shows persistent memory faults, a controller backup and restore may be required.
Signal Isolators and Fusing: Check any signal isolators in the analog I/O circuit for correct output. Replace any blown fuses in the robot controller fuse panel — a harness short may have cleared a fuse without triggering a logged fault. Verify that the replacement fuses match the original amperage rating specified in the IRB 4600 electrical documentation.
This systematic approach — replacing the 3HAC043963-001 and simultaneously auditing the surrounding electrical ecosystem — is the most reliable method for preventing a repeat failure and ensuring the robot returns to full production capacity without residual fault conditions.
Site Replacement Workflow
The 3HAC043963-001 is a direct OEM replacement for the original ABB cable harness in IRB 4600 and IRB 1600 robots. No firmware changes, parameter adjustments, or mechanical modifications are required. The replacement workflow is as follows:
Step 1 — Isolation: Place the IRC5 controller in manual mode and engage the E-stop. Isolate the main power supply and verify zero-energy state using a lockout/tagout procedure compliant with local safety regulations.
Step 2 — Documentation: Photograph the existing harness routing, connector positions, and cable tie locations before disassembly. This documentation is critical for correct reinstallation and reduces the risk of routing errors that cause premature wear on the new harness.
Step 3 — Removal: Disconnect all harness connectors in sequence per the IRB 4600 maintenance manual. Remove cable ties and routing clips. Extract the harness from the robot arm, noting any areas of visible damage for root cause analysis.
Step 4 — Installation: Route the new 3HAC043963-001 harness following the documented routing path. Seat all connectors fully and verify locking tabs are engaged. Install new cable ties at the original clip positions. Do not over-tension ties near flex zones.
Step 5 — Verification: Before restoring power, perform a continuity check on all harness circuits using a multimeter. Restore power and run the robot through a slow-speed manual cycle on all axes. Check for fault codes and verify smooth motion on all axes before returning to automatic mode.
This workflow is applicable to both planned maintenance replacements and emergency breakdown scenarios. Having a 3HAC043963-001 in the on-site spare parts inventory eliminates the procurement lead time from the critical path and allows maintenance teams to execute this workflow within a single shift.
Spare Parts Support FAQ
Q1: Is the 3HAC043963-001 compatible with both IRB 4600 and IRB 1600 robots?
Yes. The 3HAC043963-001 is listed in the spare parts BOM for both the IRB 4600 and IRB 1600 series. However, compatibility can vary by robot variant and manufacturing date. We recommend confirming your robot’s serial number and controller revision before ordering. Our technical team can assist with compatibility verification at no charge.
Q2: What does the 12-month warranty cover?
The warranty covers manufacturing defects in materials and workmanship for 12 months from the date of shipment. It does not cover damage resulting from incorrect installation, operation outside ABB specifications, or physical damage during handling. Warranty claims are processed with priority — contact [email protected] with your order number and a description of the fault.
Q3: How is the unit tested before shipment?
Each 3HAC043963-001 unit undergoes continuity testing on all circuits, insulation resistance measurement, and physical inspection of all connector housings and cable jacket integrity. Test results are logged against the unit serial number. Units that do not pass all checks are quarantined and not shipped.
Q4: Can I place a standing order or blanket PO for ongoing spare parts supply?
Yes. SMARTNEXMSK supports blanket purchase orders and scheduled delivery arrangements for maintenance teams that require guaranteed stock availability. This is particularly valuable for facilities operating multiple IRB 4600 or IRB 1600 robots where harness replacement is a scheduled maintenance item. Contact our sales team to discuss volume pricing and delivery scheduling.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341