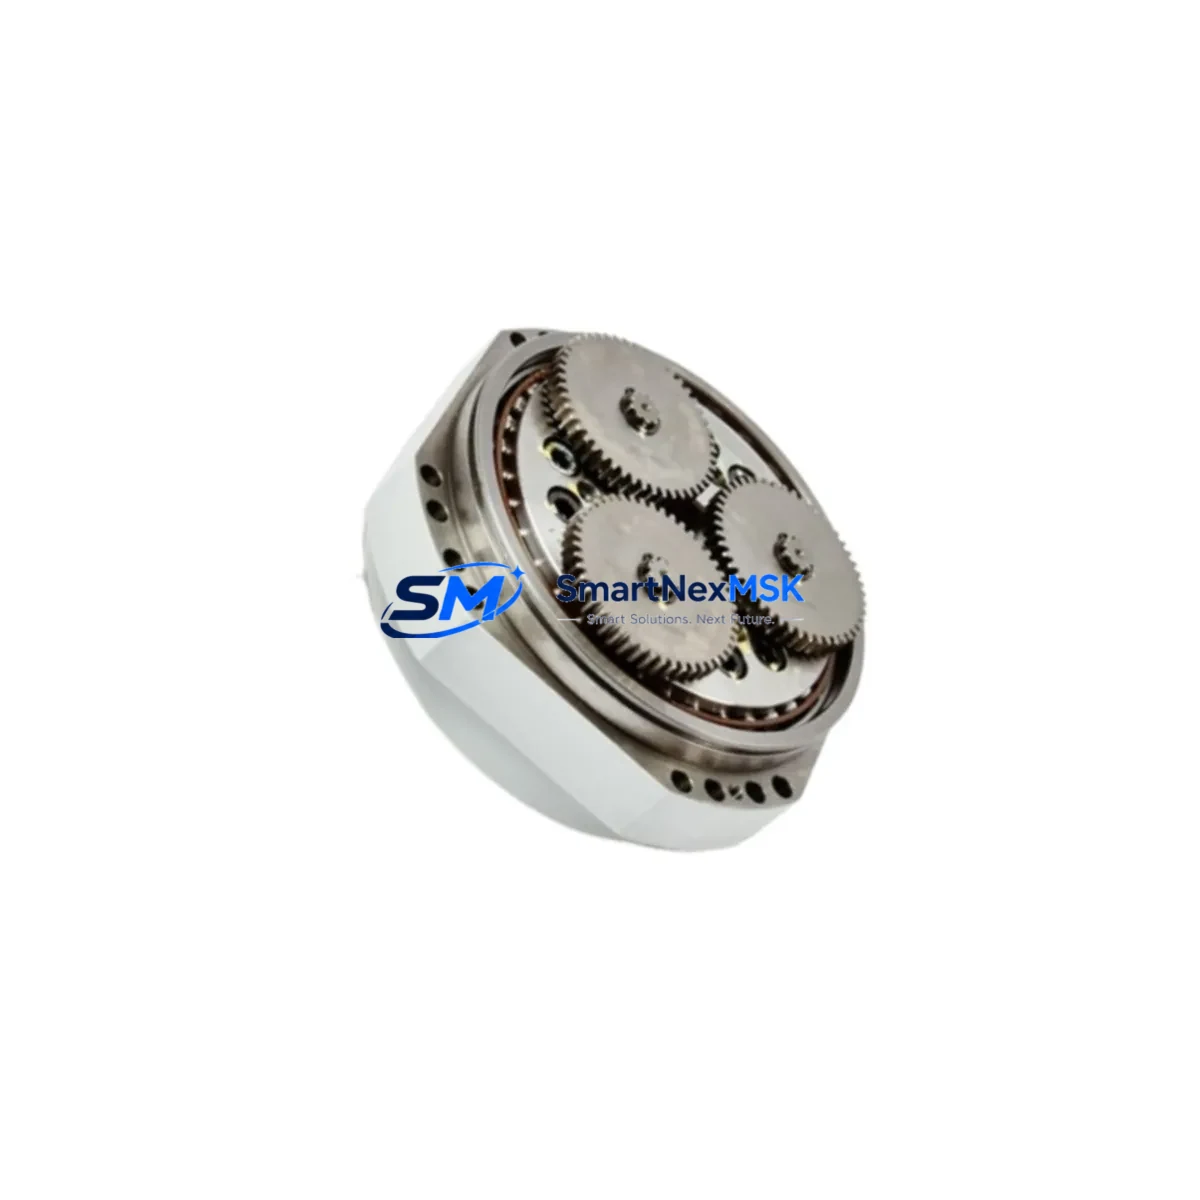
ABB 3HAC046336-003 Retrofit-Ready RV Reducer for IRB Series Control Systems
The ABB 3HAC046336-003 is a precision RV-100N-161 cycloidal reduction gear engineered for seamless retrofit integration into ABB IRB industrial robot platforms. As legacy robot arms approach end-of-service life or require joint-axis overhaul, this reducer serves as the authoritative drop-in replacement — restoring full torque capacity, positional repeatability, and axis stiffness without requiring mechanical redesign of the robot base or wrist assembly. Whether you are executing a planned maintenance cycle, recovering from an unplanned gearbox failure, or upgrading an aging IRB 6600 or IRB 6640 arm to extend its operational lifespan by 5–10 years, the 3HAC046336-003 is the factory-specified solution.
SMARTNEXMSK maintains verified stock of the ABB 3HAC046336-003 and ships globally with full documentation, including dimensional drawings, torque specifications, and installation torque sequences. Each unit undergoes pre-shipment functional inspection and is covered by a 12-month warranty against manufacturing defects.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Part Number | 3HAC046336-003 |
| Reducer Type | RV Cycloidal Reducer — RV-100N-161 |
| Reduction Ratio | 161:1 |
| Compatible Robot Series | ABB IRB 6600, IRB 6640, IRB 6650S, IRB 7600 |
| Axis Application | Axis 1 / Axis 2 (model-dependent — verify robot BOM) |
| Mounting Interface | Flange-mount; matches OEM bolt pattern — no adapter required |
| Communication Compatibility | Mechanical component; integrates with IRC5 / OmniCore controller without software change |
| Replacement Recommendation | Direct OEM-equivalent replacement; re-use existing motor coupling and encoder |
| Commissioning Requirement | Axis calibration via RobotStudio or teach pendant after installation |
| Warranty | 12 Months — covers manufacturing defects and premature failure |
Retrofit Planning for Existing Automation Systems
A successful gearbox retrofit on an ABB IRB robot involves more than a mechanical swap. Before removing the failed or worn 3HAC046336-003 from the robot arm, engineers should document the current axis calibration offsets stored in the IRC5 controller or OmniCore controller — these values are critical for restoring positional accuracy after reinstallation. The calibration data is accessible via the FlexPendant teach pendant or through RobotStudio offline programming software.
During disassembly, inspect the ABB 3HAC14057-1 motor (axis drive motor) for bearing wear and encoder integrity. It is common practice to replace the motor oil seal and re-grease the new reducer with the specified ABB LGEP 2 grease (part reference 3HAC032140-004) during the same maintenance window to avoid a second shutdown. Verify that the 3HAC046336-003 input shaft spline matches the existing motor coupling — mismatched spline counts are a frequent source of commissioning errors on mixed-vintage robot fleets.
For robots integrated into a production cell with a DSQC 661 I/O module or DSQC 652 digital I/O board, confirm that the safety PLC interlock logic is placed in bypass mode before powering down the robot. Failure to do so may trigger an unplanned E-stop cascade across the cell. If the robot communicates via DeviceNet or PROFIBUS-DP to a Siemens S7-300 or Allen-Bradley ControlLogix PLC, coordinate the maintenance window with the PLC operator to suppress timeout faults on the network master.
After mechanical installation, re-torque all flange bolts to the specified values in the ABB Product Manual (document 3HAC028284-001). Reconnect the SMB (Serial Measurement Board) cable — typically routed through the robot’s lower arm — and verify resolver signal integrity before powering up. The SMB board (3HAC14550-1) stores axis revolution counters; if the battery has discharged during the repair window, revolution counter update is mandatory before running any program.
For cells using an ABB Panel PC 800 or third-party HMI connected via OPC-UA, no HMI screen changes are required following a mechanical reducer replacement — the robot’s kinematic model remains unchanged. However, if the robot was previously operating with a modified DH-parameter set due to gearbox wear compensation, those offsets should be cleared and the robot re-mastered to factory zero position using the calibration pin method.
Downtime Control During System Migration
Minimizing production downtime during an IRB gearbox replacement requires a structured pre-staging approach. Begin by ordering the ABB 3HAC046336-003 with sufficient lead time and confirming receipt against the packing list before scheduling the maintenance window. Pre-stage all ancillary consumables — grease cartridges, oil seals, and torque wrench calibration records — so the mechanical work can proceed without interruption.
Back up the robot system configuration from the IRC5 or OmniCore controller to a USB drive using the FlexPendant’s Backup & Restore function. This preserves the RAPID program, I/O configuration, tool data, work object definitions, and safety configuration. If the robot is part of a MultiMove system coordinating with a IRBP positioner or a conveyor tracking application using a DSQC 377B encoder interface board, back up the entire system — not just the individual robot task.
During the replacement window, keep the IRC5 controller powered but in manual mode to maintain the fieldbus network heartbeat and prevent upstream PLC fault accumulation. After reinstallation and axis calibration, run the robot through a slow-speed dry cycle (10% speed override) before returning to production speed. Verify TCP (Tool Center Point) accuracy against a reference fixture before releasing the cell to production. This structured approach typically limits unplanned downtime to under 4 hours for a single-axis reducer replacement by an experienced team.
Retrofit Support FAQ
Q1: Is the ABB 3HAC046336-003 a direct replacement for the original factory-installed reducer?
Yes. The 3HAC046336-003 is the OEM-specified RV-100N-161 reducer for the applicable IRB robot axes. It uses the same flange bolt pattern, input shaft spline, and output flange dimensions as the original unit. No mechanical adaptation is required. Confirm the axis number and robot serial number against the ABB spare parts catalog before ordering.
Q2: What commissioning steps are required after installation?
After mechanical installation and SMB cable reconnection, perform a revolution counter update via the FlexPendant, followed by fine calibration using the calibration pin at the robot’s zero-position mark. Verify axis load parameters in the IRC5 or OmniCore configuration match the robot’s payload specification. Run a slow-speed test cycle and check for abnormal vibration or temperature rise at the gearbox housing before returning to full production speed.
Q3: Can this reducer be used in robots communicating via PROFINET or EtherNet/IP?
Yes. The 3HAC046336-003 is a purely mechanical component and is communication-protocol agnostic. It is compatible with ABB robots running IRC5 controllers configured for PROFINET (via DSQC 688 PROFINET device board) or EtherNet/IP (via DSQC 669 EtherNet/IP board). No fieldbus reconfiguration is needed following a mechanical reducer replacement.
Q4: What does the 12-month warranty cover?
The 12-month warranty covers manufacturing defects, premature bearing failure, and abnormal gear wear under normal operating conditions. It does not cover damage resulting from improper installation, incorrect lubrication, overloading beyond rated torque, or contamination ingress. SMARTNEXMSK provides pre-shipment functional inspection documentation with each unit. Warranty claims are processed via [email protected] with photographic evidence of the defect.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341