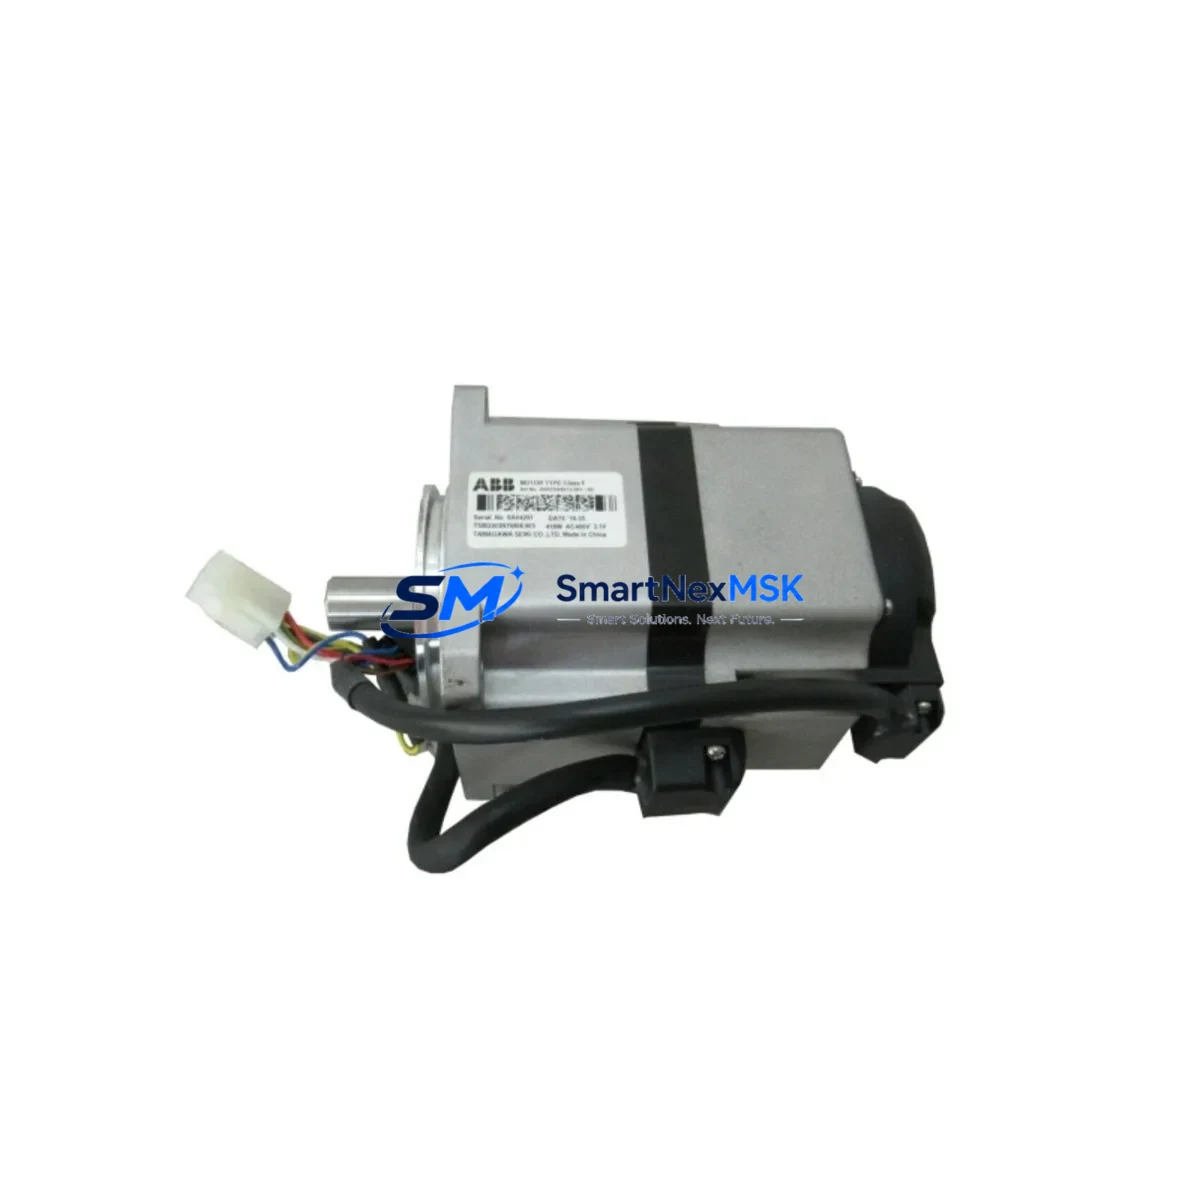
ABB 3HAC048317-001 Retrofit-Ready AC Servo Motor for IRB 6700 Control Systems
The ABB 3HAC048317-001 is a precision-engineered rotary AC servo motor with integrated pinion, purpose-built for axis drive applications in the IRB 6700 robot series. As industrial facilities face increasing pressure to extend the service life of existing robot installations, this module has become a critical retrofit component for maintenance engineers managing aging ABB robot fleets. Whether you are replacing a failed axis motor on a production line or executing a planned upgrade of a legacy IRB 6640 or IRB 6650 system migrating to the IRB 6700 platform, the 3HAC048317-001 provides a verified drop-in solution that preserves existing wiring harnesses, mounting geometry, and drive communication protocols.
Sourced directly from ABB-authorized supply chains and subject to full functional testing prior to dispatch, each unit ships with a 12-month warranty covering manufacturing defects and operational failures under normal industrial duty cycles. Stock is maintained for immediate fulfillment to minimize unplanned downtime on critical production assets.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Series | ABB IRB 6700 (all variants); cross-reference IRB 6640, IRB 6650 with axis mapping verification |
| Motor Type | Rotary AC Servo Motor with Pinion |
| Mounting Interface | Standard ABB axis flange; direct bolt-on replacement, no adapter plate required |
| Connector / Terminal | OEM-matched motor power and resolver/encoder connector; compatible with existing 3HAC cable assemblies |
| Communication Protocol | Compatible with ABB IRC5 controller drive bus; no firmware reconfiguration required for same-series swap |
| Drive Compatibility | Works with DSQC662 drive unit and standard IRC5 axis computer modules |
| Installation Requirement | Axis calibration via RobotStudio or FlexPendant required after replacement; revolution counter update mandatory |
| Retrofit Recommendation | Verify axis load parameters in RAPID program; update SMB (Serial Measurement Board) data if replacing SMB simultaneously |
| Debugging Focus | Torque tuning, backlash check on pinion mesh, brake release test, and jog-mode verification before production restart |
| Warranty | 12 Months — covers manufacturing defects and operational failure under rated duty cycle |
Retrofit Planning for Existing Automation Systems
Successful integration of the 3HAC048317-001 into an existing robot cell begins well before the physical swap. Engineers should first audit the IRC5 controller cabinet to confirm the DSQC662 axis drive module is within its own service life, as a degraded drive can mask motor performance issues and lead to repeat failures. The 3HAC046337-003 — the associated motor cable assembly — should be inspected for insulation wear, connector pin corrosion, and continuity before reuse; replacing the motor without addressing a marginal cable is a common source of post-retrofit faults.
For facilities running multi-robot cells, the SMB (Serial Measurement Board) unit mounted on the robot arm stores axis revolution counter data. If the SMB battery has not been replaced within the recommended interval, this is the ideal time to install a fresh SMB battery pack alongside the motor swap, avoiding a second planned outage. The DSQC1000 main computer and DSQC663 I/O module in the IRC5 cabinet should also be checked for firmware currency, as older firmware versions may generate axis error codes during the post-replacement calibration sequence.
Where the retrofit involves migrating from an older IRB 6640 platform to the IRB 6700, engineers must account for differences in the mechanical unit configuration file (MOC.cfg). The axis payload and inertia parameters defined in the RAPID program may require adjustment to reflect the IRB 6700’s extended reach and revised axis torque ratings. HMI screens built on ABB’s Panel Builder or third-party SCADA systems referencing robot status tags should be reviewed to confirm signal mapping remains valid after the controller configuration update.
For cells using DeviceNet or PROFIBUS communication between the IRC5 controller and external PLCs — such as Siemens S7-300 or Allen-Bradley ControlLogix systems — the fieldbus node address and I/O mapping table should be documented before any hardware change. This ensures the PLC program does not require modification and that the robot’s ready/fault status signals continue to drive the line control logic correctly after restart. Where EtherNet/IP has been adopted as part of a broader network modernization, confirm that the IRC5 DSQC688 fieldbus adapter is correctly configured before the robot is returned to automatic mode.
Downtime Control During System Migration
Minimizing production impact during a servo motor replacement on an IRB 6700 requires a structured pre-outage preparation protocol. Before the maintenance window opens, the RAPID program should be backed up in full using RobotStudio, including all module files, system parameters, and the current calibration offset data. The revolution counter values for all axes should be recorded from the FlexPendant and stored offline — this data is essential for restoring accurate axis positioning after the 3HAC048317-001 is installed and the revolution counter update procedure is executed.
During the physical swap, the robot should be positioned to a mechanically stable maintenance pose with all axes locked via the brake release unit. The pinion mesh on the replacement motor should be checked against the gear ring for correct backlash before final torque of the mounting fasteners. Once the motor is secured and the 3HAC046337-003 cable reconnected, the IRC5 controller should be powered up in manual mode and the revolution counter updated axis by axis via the FlexPendant before any automatic program execution is attempted.
A controlled jog-mode verification across the full axis range — at reduced speed — confirms that the motor direction, torque response, and position feedback are consistent with the pre-failure baseline. Only after this verification should the robot be returned to automatic mode and the production program restarted. This structured approach consistently achieves full production restoration within a single planned maintenance shift, protecting both the robot asset and the surrounding line equipment from secondary damage caused by premature restart.
Retrofit Support FAQ
Q: Is the 3HAC048317-001 a direct replacement for the original motor on all IRB 6700 variants?
A: Yes, the 3HAC048317-001 is the OEM-specified motor for the IRB 6700 series axis positions it is designed for. For cross-series applications (e.g., IRB 6640 to IRB 6700 migration), axis mapping and mechanical unit configuration verification is required. Contact our technical team with your robot serial number for confirmation before ordering.
Q: What calibration steps are required after installation?
A: After physical installation, a revolution counter update must be performed via the FlexPendant. Full axis calibration using the calibration pendulum or RobotStudio calibration routine is recommended if the original calibration data is unavailable or if the SMB has been replaced simultaneously. Torque and backlash verification should be completed before returning the robot to automatic mode.
Q: How is each unit tested before shipment?
A: Every 3HAC048317-001 unit undergoes functional testing covering winding resistance, insulation integrity, encoder/resolver signal output, and brake engagement before dispatch. Units are packed in anti-static, shock-protected packaging to maintain condition during international freight. A test report is available upon request.
Q: What does the 12-month warranty cover?
A: The 12-month warranty covers manufacturing defects and operational failures occurring under rated duty cycle conditions. It does not cover damage resulting from incorrect installation, overvoltage events, or operation outside the motor’s rated parameters. Warranty claims are processed with a replacement unit dispatched upon fault confirmation, minimizing your downtime exposure.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341