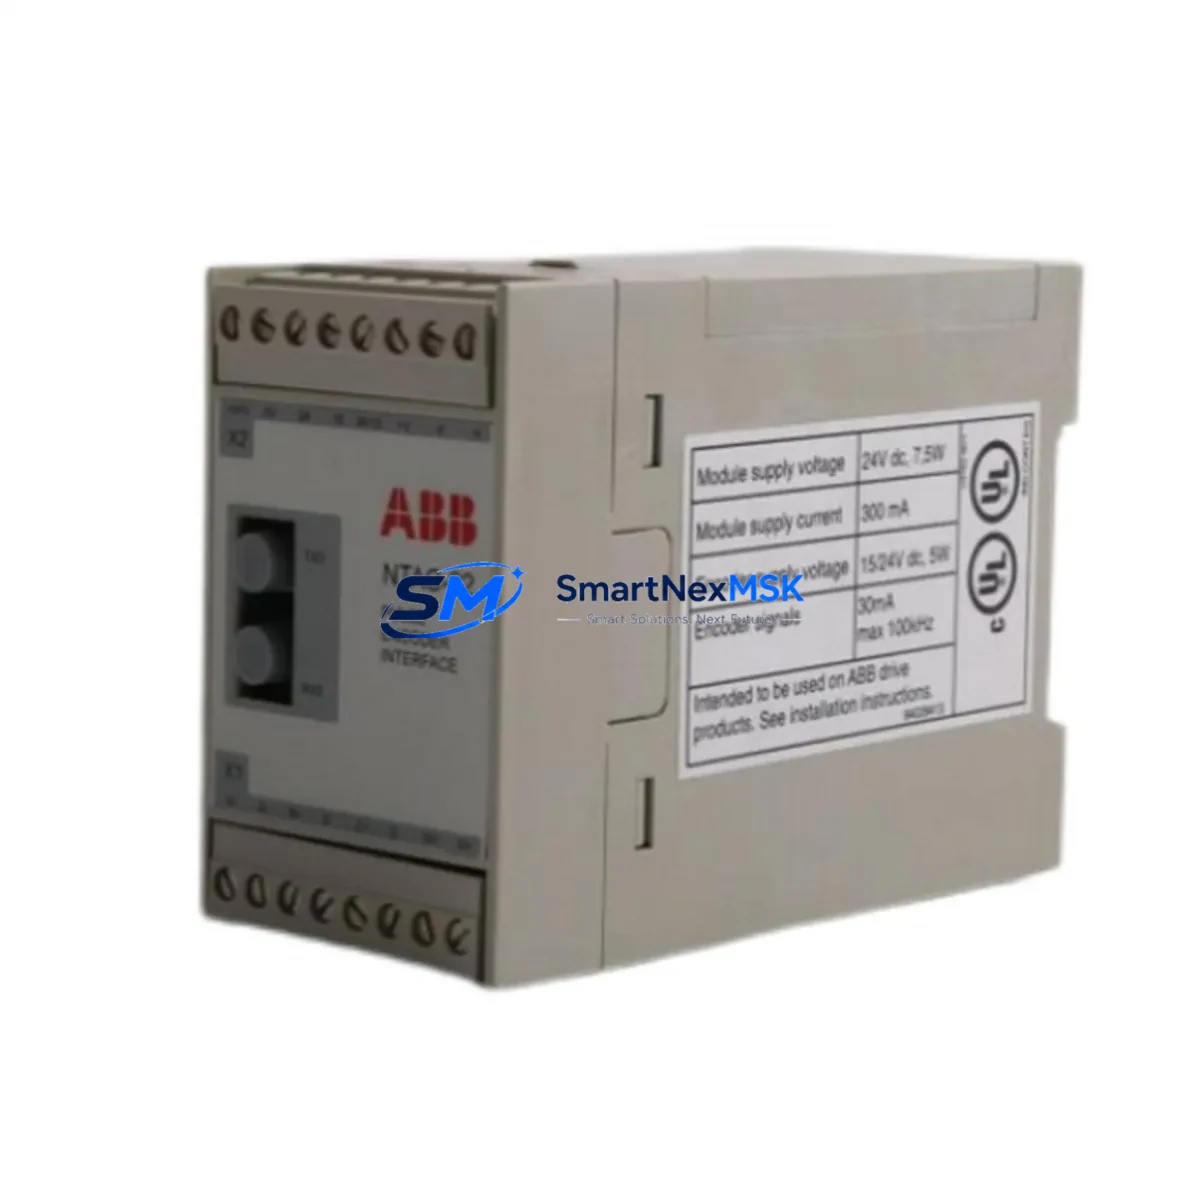
ABB 3HAC057544-006 Retrofit-Ready Servo Motor for IRB660 Control Systems
The ABB 3HAC057544-006 is a precision servo motor with integrated pinion, purpose-built for the IRB660 palletizing robot series. As legacy IRB660 installations approach end-of-service milestones, this unit serves as the definitive retrofit-ready replacement for aging or discontinued axis drive components. Whether you are restoring a failed joint, upgrading a worn drivetrain, or executing a planned control system modernization, the 3HAC057544-006 delivers OEM-grade mechanical and electrical compatibility without requiring structural modifications to the robot arm or control cabinet.
This servo motor is fully compatible with the ABB IRC5 controller platform, which governs the majority of IRB660 installations currently in service across palletizing, material handling, and end-of-line automation cells. The unit integrates directly with the IRC5 single-cabinet and IRC5 panel-mounted controller variants, and communicates via the standard ABB resolver feedback interface. No firmware patching or axis parameter reconfiguration is required when replacing a like-for-like 3HAC057544-006 unit, significantly reducing commissioning time and minimizing exposure to unplanned downtime.
Before proceeding with installation, engineers should verify the following against the existing system: available power supply capacity from the IRC5 drive module (confirm axis current rating matches the replacement unit), terminal block wiring at the motor connector (M23 circular connector pinout must match the original harness), backplane slot assignment within the IRC5 drive system, motor axis address as configured in RobotWare, program compatibility with existing RAPID routines referencing joint speed and torque limits, any HMI screen calibration tied to axis position feedback, communication link integrity between the IRC5 main computer and the drive unit, and field commissioning steps including brake release verification, resolver offset calibration, and load cycle testing.
In retrofit scenarios where the original 3HAC057544-006 has been discontinued or is unavailable through standard distribution channels, this unit provides a verified drop-in solution. Customers migrating from earlier IRB660 variants should also confirm compatibility with the 3HAC026253-001 motor cable harness and the 3HAC14550-2 connector kit, both of which are commonly retained during partial drivetrain upgrades. The 3HAC057544-006 mounts to the same axis bracket geometry as its predecessor, and the integrated pinion gear meshes directly with the existing gearbox output stage without requiring shimming or backlash adjustment.
For control cabinet upgrades running in parallel with the motor replacement, engineers frequently source the DSQC662 I/O module and DSQC679 teach pendant alongside this servo unit to complete a full IRC5 cabinet refresh. In multi-robot cells, the 3HAC057544-006 is often deployed in conjunction with the IRC5 MultiMove controller option, where axis synchronization across coordinated robot groups must be preserved throughout the replacement procedure. The DSQC1000 main computer board and 3HAC031670-001 power distribution unit are additional components commonly evaluated during the same maintenance window.
All units are pre-tested prior to shipment, with functional verification covering resolver signal integrity, brake engagement and release, and no-load rotation across the full speed range. Each 3HAC057544-006 ships with a 12-month warranty covering manufacturing defects and premature failure under normal operating conditions. Typical lead time is 1–3 business days from order confirmation, with expedited dispatch available for critical production recovery situations.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Series | ABB IRB660 (all variants) |
| Controller Compatibility | IRC5 Single Cabinet, IRC5 Panel Mounted |
| Feedback Interface | Resolver (standard ABB axis feedback) |
| Connector Type | M23 Circular Connector (matches OEM harness) |
| Mounting Interface | Direct bolt-on to IRB660 axis bracket — no modification required |
| Pinion Integration | Integrated pinion gear — meshes with existing gearbox output stage |
| Communication Protocol | ABB proprietary resolver feedback; IRC5 drive bus compatible |
| Replacement Scope | Like-for-like drop-in; no axis parameter reconfiguration required |
| Pre-Shipment Testing | Resolver signal, brake function, no-load rotation verified |
| Warranty | 12 Months — manufacturing defects and premature failure |
| Lead Time | 1–3 Business Days (expedited available) |
| Origin | CN |
Retrofit Planning for Existing Automation Systems
A successful IRB660 servo motor retrofit begins well before the maintenance window opens. The first step is a full audit of the control cabinet, confirming that the IRC5 drive module assigned to the affected axis has sufficient current headroom for the replacement 3HAC057544-006 unit. Engineers should pull the axis configuration from RobotWare and cross-reference the motor data file to ensure the drive parameters match the replacement unit’s torque and speed envelope.
Wiring continuity must be verified at the motor connector and traced back through the 3HAC026253-001 cable harness to the IRC5 drive terminal block. Any signs of insulation degradation or connector corrosion at the M23 interface should be addressed before the new motor is installed. If the 3HAC14550-2 connector kit is not already on hand, it should be sourced as part of the retrofit kit to avoid delays during installation.
For cells where the IRB660 operates alongside other robots or peripheral equipment, the DSQC662 I/O module configuration should be reviewed to confirm that safety interlocks and zone signals remain intact after the axis replacement. If the cell uses a DSQC679 teach pendant for manual jogging and program verification, the pendant should be available on-site during commissioning to allow axis-by-axis motion testing under manual control before returning to automatic mode.
Backplane slot assignments within the IRC5 cabinet should be documented before any hardware is removed. The 3HAC031670-001 power distribution unit and DSQC1000 main computer board should be inspected for firmware currency as part of the same maintenance event, since outdated firmware can introduce compatibility issues with replacement drive components. If the cell is running an older RobotWare version, a controlled firmware update should be scheduled in parallel with the motor replacement to avoid a second maintenance window.
For I/O-intensive applications, engineers should also verify that the DSQC662 I/O module address mapping is preserved after the axis replacement, particularly in cells where the IRB660 interfaces with conveyor encoders, vision systems, or barcode readers via the IRC5 fieldbus interface. Any changes to the axis configuration in RobotWare should be backed up to a USB drive before the replacement begins, ensuring that the original program logic can be restored if commissioning reveals unexpected behavior.
Downtime Control During System Migration
Minimizing downtime during an IRB660 servo motor replacement requires a structured approach that protects the original program logic and maintains field control continuity throughout the procedure. The recommended sequence begins with a full RobotWare backup, capturing the system configuration, RAPID programs, I/O signal maps, and axis calibration data to a secure storage location before any hardware is disturbed.
Once the backup is confirmed, the IRC5 controller should be placed in manual mode and the affected axis brakes engaged before the motor connector is disconnected. The 3HAC057544-006 can then be unbolted from the axis bracket and the replacement unit installed in its place. The M23 connector should be seated and locked before power is restored to the drive module.
After physical installation, the resolver offset calibration procedure should be executed using the IRC5 teach pendant before any automatic program execution is attempted. This step is critical for preserving the axis position reference that the RAPID programs rely on for path accuracy. Once calibration is confirmed, a slow-speed manual jog through the full axis range should be completed to verify smooth motion and correct brake behavior before the cell is returned to production.
For cells where production continuity is critical, a pre-staged replacement unit — tested and ready to install — can reduce the active maintenance window to under two hours. Keeping a 3HAC057544-006 in local inventory, alongside the associated connector kit and cable harness, is the most effective strategy for protecting against unplanned downtime caused by axis motor failure in high-utilization IRB660 installations.
Retrofit Support FAQ
Q: Is the 3HAC057544-006 a direct replacement for the original IRB660 axis motor?
A: Yes. The 3HAC057544-006 is a like-for-like replacement for the original servo motor with pinion on the IRB660. It mounts to the same bracket geometry, uses the same M23 connector pinout, and communicates via the standard ABB resolver feedback interface. No axis parameter reconfiguration is required for a like-for-like swap.
Q: What commissioning steps are required after installation?
A: After physical installation and connector seating, a resolver offset calibration must be performed using the IRC5 teach pendant. Following calibration, a manual jog through the full axis range should be completed to verify motion quality and brake function before returning the cell to automatic mode.
Q: How do I verify wiring compatibility before installation?
A: Confirm that the existing 3HAC026253-001 cable harness is in good condition and that the M23 connector pins match the replacement unit’s pinout. If the harness shows signs of wear, replace it using the 3HAC14550-2 connector kit before installing the new motor.
Q: What does the 12-month warranty cover?
A: The warranty covers manufacturing defects and premature failure under normal operating conditions for 12 months from the date of shipment. Each unit is pre-tested prior to dispatch, with resolver signal integrity, brake function, and no-load rotation verified before release.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341