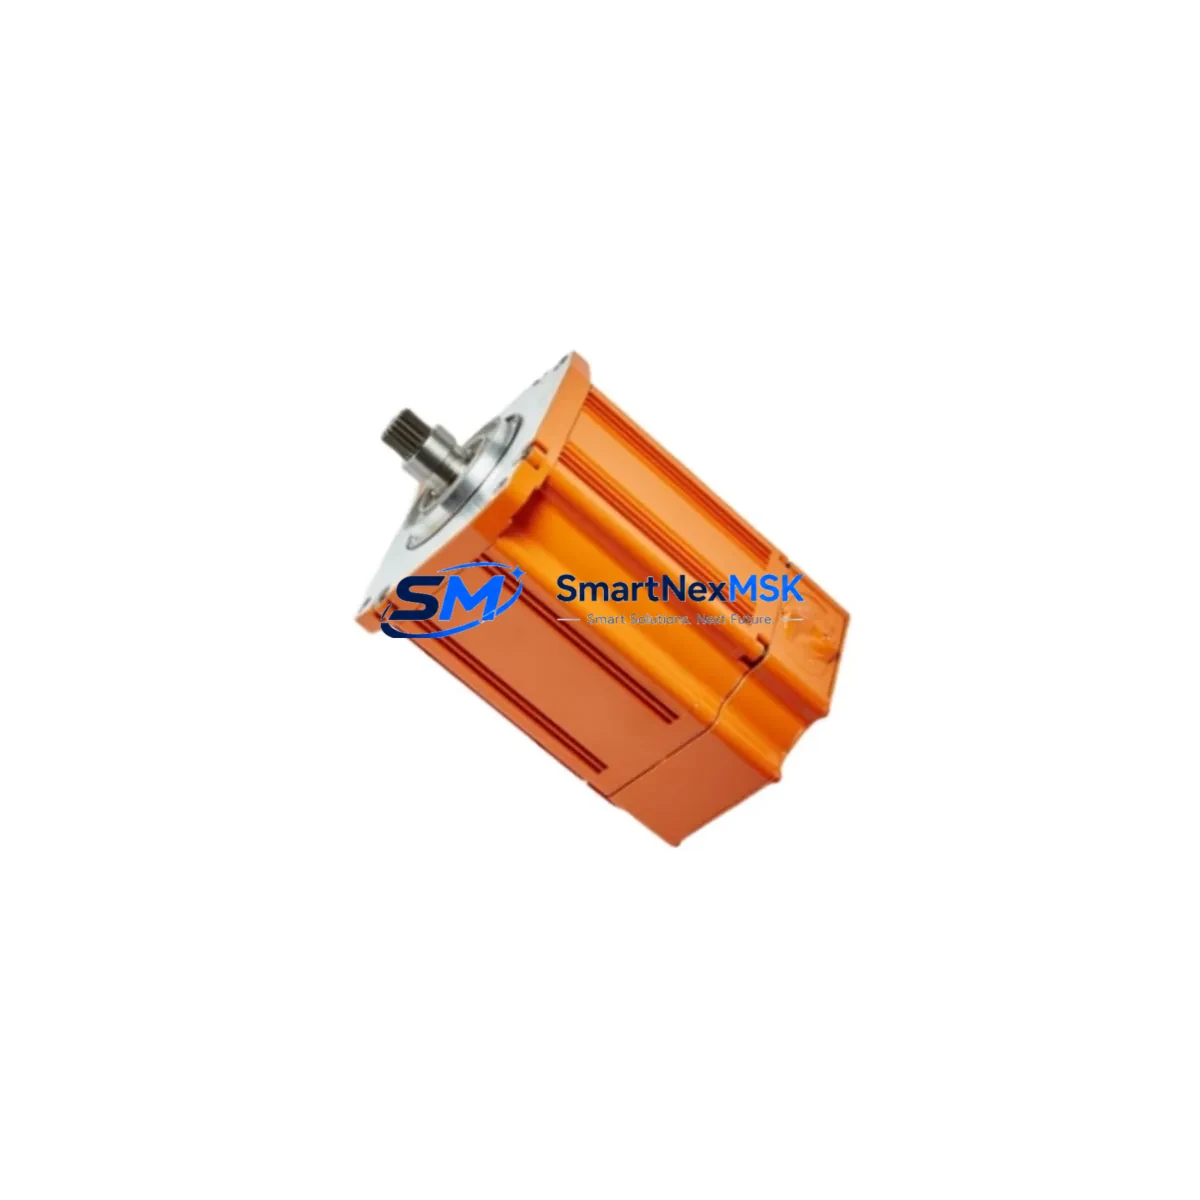
ABB 3HAC058993-003 Retrofit-Ready Servo Motor for IRB6600 Control Systems
The ABB 3HAC058993-003 is a precision servo motor engineered for Axis-1 drive on the ABB IRB6600 industrial robot series — one of ABB’s most widely deployed heavy-payload robotic platforms in automotive, foundry, and heavy manufacturing environments. As the IRB6600 fleet ages and OEM spare parts become increasingly scarce, the 3HAC058993-003 has become a critical retrofit component for maintenance engineers tasked with extending the operational life of existing robot cells without committing to full system replacement.
This unit is sourced from verified supply channels, pre-tested against ABB’s original torque, encoder feedback, and thermal performance specifications, and ships with a 12-month warranty covering manufacturing defects and functional failure under normal operating conditions. Whether you are executing a planned preventive replacement, responding to an unplanned axis fault, or upgrading a degraded drive train ahead of a production campaign, the 3HAC058993-003 is available for immediate dispatch with full documentation support.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Model | ABB IRB6600 (all variants: IRB6600-175/2.55, IRB6600-200/2.75, IRB6600-225/2.55) |
| Axis Position | Axis 1 (Base Rotation) |
| Connector / Terminal Interface | OEM-matched motor power and resolver/encoder connectors; direct plug-in replacement |
| Mounting / Flange Standard | Compatible with IRB6600 lower arm casting and gearbox interface (ABB 3HAC series) |
| Communication Compatibility | Works with ABB IRC5 controller, DSQC series drive modules, and Profibus/DeviceNet I/O configurations |
| Replacement Recommendation | Direct drop-in for failed or degraded OEM 3HAC058993-003; no mechanical modification required |
| Commissioning Notes | Axis calibration required post-installation; use ABB RobotStudio or FlexPendant for fine-tuning |
| Warranty | 12 Months — covers manufacturing defects and functional failure under rated operating conditions |
Retrofit Planning for Existing Automation Systems
Replacing the Axis-1 servo motor on an IRB6600 is a structured process that demands careful preparation across mechanical, electrical, and software domains. Before removing the failed unit, engineers should document the current axis calibration data stored in the ABB IRC5 controller — specifically the revolution counter values and fine calibration offsets, which are held in the DSQC1000 main computer or its predecessor the DSQC652 board depending on controller generation.
On the electrical side, the motor power cable (typically routed through the lower arm cable harness, part of the 3HAC044075-001 cable bundle) must be inspected for insulation wear before reconnection. The resolver or encoder feedback cable should be checked for continuity and shielding integrity, as signal degradation here is a common secondary cause of axis faults that can be misdiagnosed as motor failure. Terminal connections at the DSQC508 or DSQC540 drive module should be cleaned and torqued to specification.
For sites running multiple IRB6600 units on a shared IRC5 MultiMove controller, it is advisable to schedule the motor swap during a planned maintenance window rather than reacting to an in-production failure. The IRC5 cabinet houses the DSQC series drive units, the DSQC1000 main computer, and the panel board — all of which interact with axis motor feedback. A corrupted revolution counter caused by an abrupt motor swap can trigger SafeMove faults and halt adjacent robot cells if the system is not properly isolated before work begins.
Sites that have already migrated from the older S4C+ controller to the IRC5 platform will find the 3HAC058993-003 fully compatible with the updated drive architecture. For facilities still operating legacy S4C+ cabinets with DSQC345 or DSQC346 drive units, a controller upgrade path should be evaluated in parallel with the motor replacement, as continued support for S4C+ hardware is increasingly limited. In such cases, the IRC5 controller upgrade kit, combined with updated DSQC drive modules and a refreshed FlexPendant (TPU), provides a comprehensive modernization path that preserves the existing IRB6600 mechanical structure while bringing the control system up to current software and safety standards.
I/O architecture should also be reviewed during the retrofit. Many legacy IRB6600 installations use hardwired digital I/O through DSQC328 or DSQC332 I/O boards. If the retrofit scope includes a controller upgrade, migrating to EtherNet/IP or Profinet-based I/O using the DSQC688 or DSQC1030 communication modules can significantly reduce wiring complexity and improve diagnostic visibility. The 3HAC058993-003 motor replacement itself does not require I/O changes, but the maintenance window is an efficient opportunity to address aging I/O infrastructure in the same cabinet.
Downtime Control During System Migration
Minimizing downtime during an IRB6600 Axis-1 motor replacement requires a pre-staged approach. The replacement 3HAC058993-003 unit should be on-site and bench-verified before the production line is taken offline. Bench verification includes confirming encoder signal output, checking motor winding resistance against ABB specification, and visually inspecting the shaft and flange for transit damage.
The axis calibration procedure is the most time-sensitive step. ABB’s calibration pendulum method or the Levelmeter 2000 tool should be prepared in advance. If the IRC5 controller retains valid revolution counter data from before the fault, the fine calibration process can be completed in under 30 minutes. If the counter data is lost — which occurs when the motor is replaced without first backing up the SMB (Serial Measurement Board) data — a full mechanical calibration is required, which can extend the downtime window by several hours.
To protect original program logic, a full system backup should be performed via RobotStudio or the FlexPendant before any hardware work begins. This backup captures RAPID programs, system parameters, I/O configuration, and SafeMove safety configuration. After motor replacement and calibration, the backup can be used to verify that no parameter drift has occurred and to restore any settings that may have been reset during the maintenance procedure. Maintaining control continuity across the replacement cycle — from pre-fault backup through post-calibration verification — is the single most effective strategy for keeping total downtime under four hours on a well-prepared site.
Retrofit Support FAQ
Q1: Is the 3HAC058993-003 a direct replacement for the original ABB IRB6600 Axis-1 motor, or are adapter brackets required?
A: The 3HAC058993-003 is a direct drop-in replacement. The motor flange, shaft dimensions, and connector pinout match the OEM specification for IRB6600 Axis-1. No adapter brackets or mechanical modifications are required. Axis calibration is required after installation, as with any motor replacement on this platform.
Q2: What commissioning steps are required after installing the replacement motor?
A: After mechanical installation and electrical reconnection, the revolution counter must be updated using the ABB FlexPendant. If fine calibration data was preserved from the SMB backup, fine calibration can be restored directly. If not, a full calibration using the calibration pendulum or Levelmeter 2000 tool is required. A test run at reduced speed should be performed before returning the robot to full production duty.
Q3: Can this motor be used with both IRC5 and older S4C+ controllers?
A: The 3HAC058993-003 is primarily validated for use with the IRC5 controller platform and its associated DSQC drive modules. Compatibility with S4C+ controllers depends on the specific drive unit variant installed. We recommend confirming the drive module part number before ordering if your site is running a legacy S4C+ cabinet. Our technical team can assist with compatibility verification prior to shipment.
Q4: What does the 12-month warranty cover, and what is the process for a warranty claim?
A: The 12-month warranty covers manufacturing defects and functional failure under rated operating conditions from the date of shipment. It does not cover damage resulting from incorrect installation, overvoltage events, or operation outside the motor’s rated parameters. To initiate a warranty claim, contact our sales team with the order reference, a description of the fault, and any available fault codes from the IRC5 controller. Replacement or repair will be arranged within the warranty period at no additional cost.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341