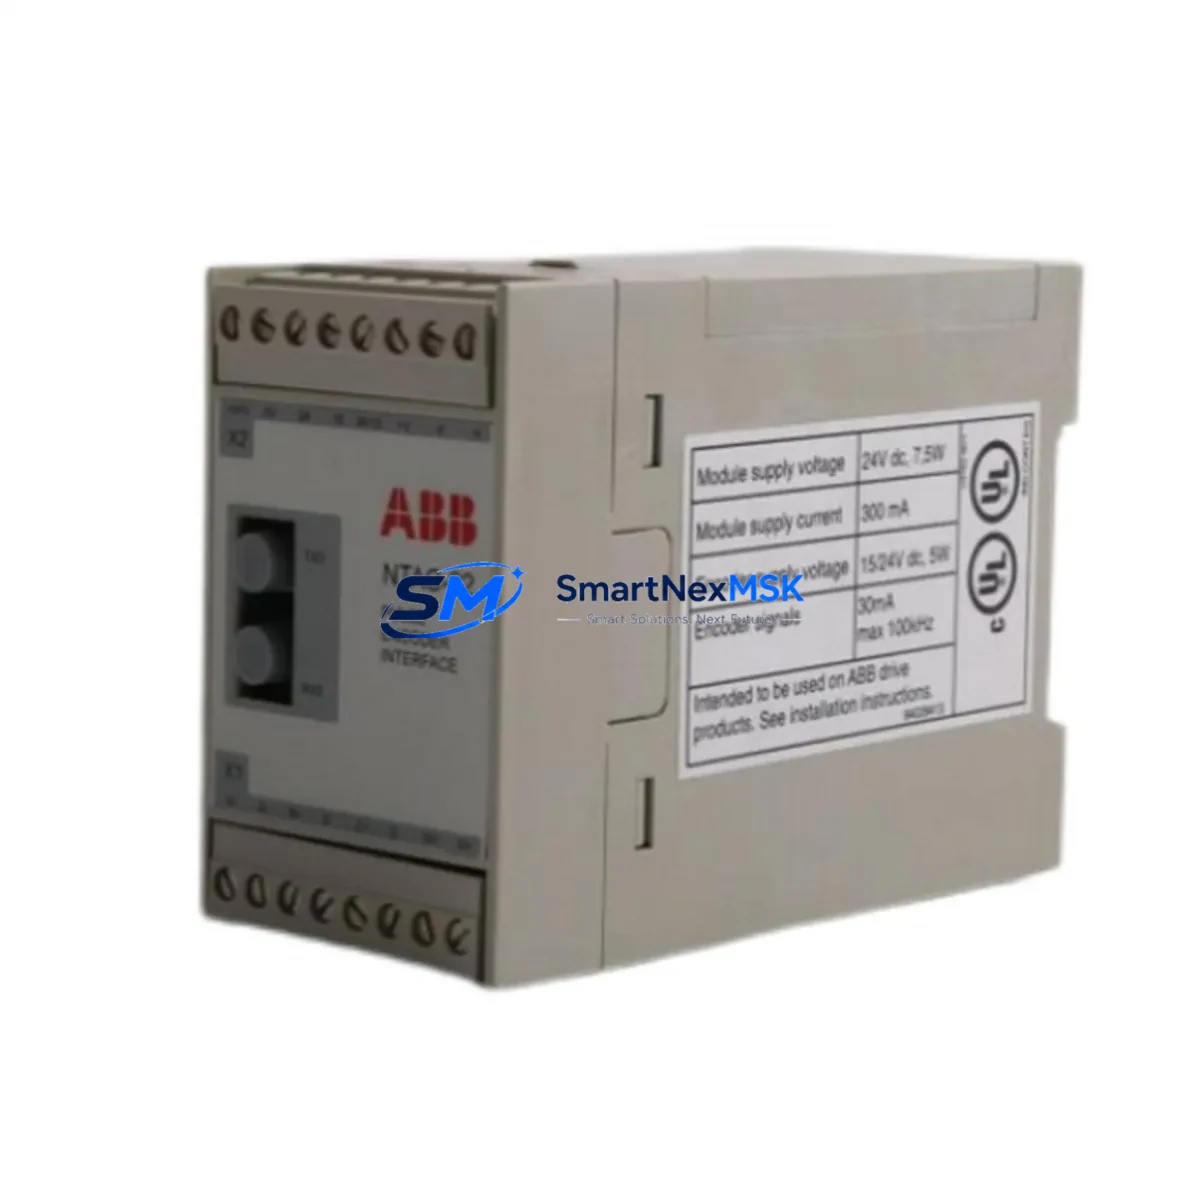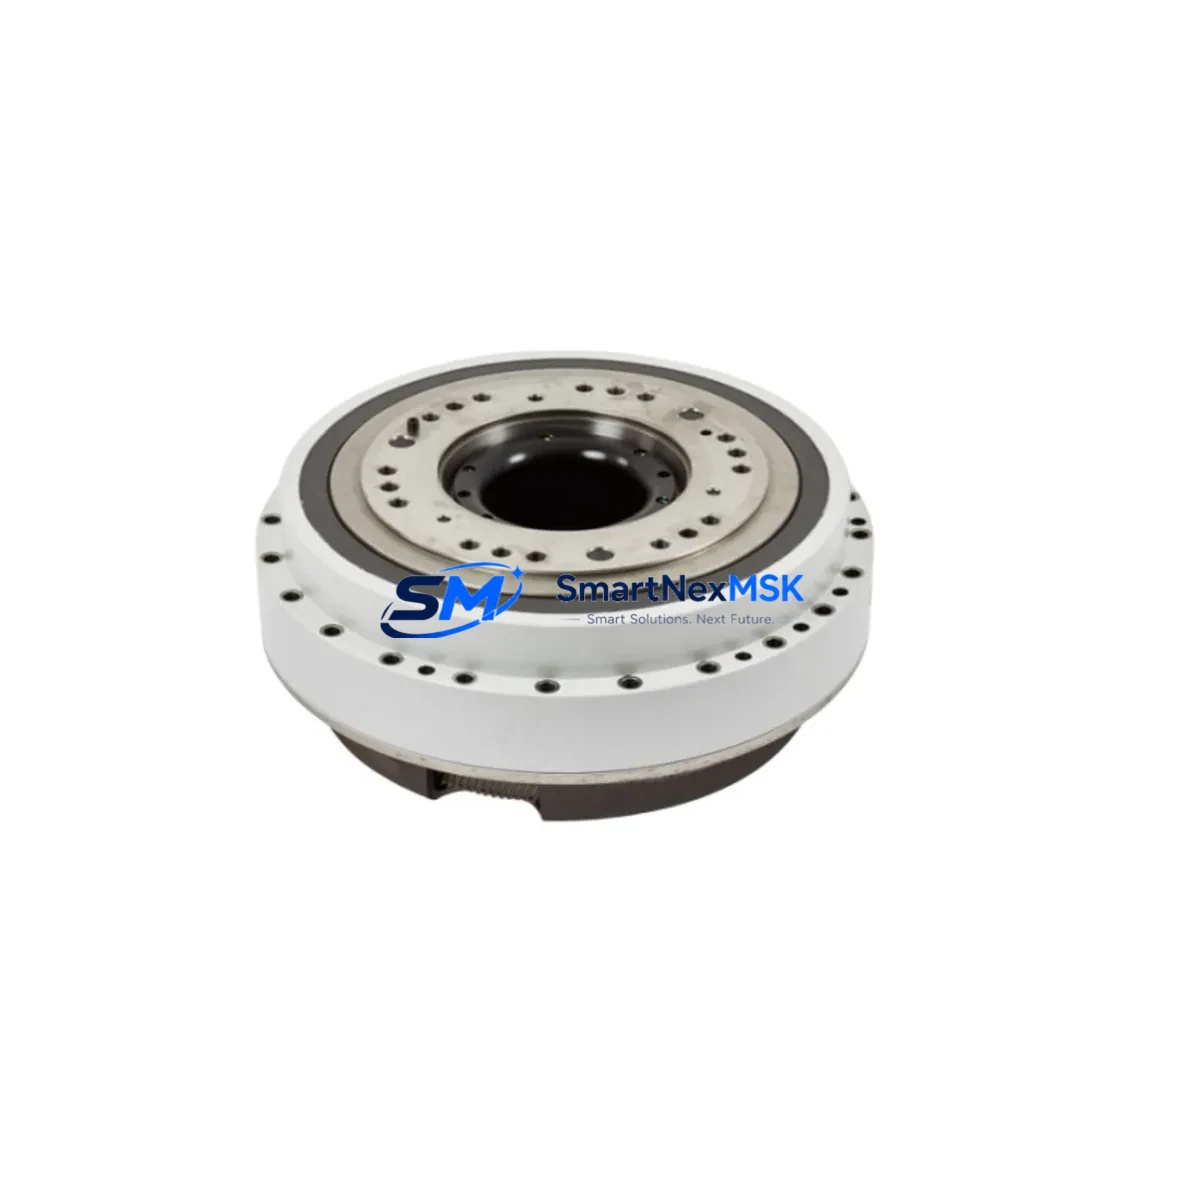
ABB 3HAC10602-2 Retrofit-Ready Servo Motor for IRB Series Control Systems
The ABB 3HAC10602-2 is a precision AC servo motor unit engineered for seamless integration into ABB IRB Series industrial robot control systems. As legacy automation lines face increasing pressure from discontinued spare parts and aging drive architectures, the 3HAC10602-2 has become a critical retrofit component for maintenance engineers and system integrators managing IRB 1400, IRB 2400, IRB 4400, and IRB 6400 platforms. Whether you are executing a planned upgrade, recovering from an unplanned axis failure, or modernizing a control cabinet to extend service life by five to ten years, this motor unit delivers the mechanical and electrical compatibility required for a smooth, low-risk transition.
Each unit supplied by SMARTNEXMSK undergoes pre-shipment functional verification, including encoder signal integrity checks, winding resistance measurement, and insulation resistance testing. Units are shipped with full documentation and carry a 12-month warranty covering manufacturing defects and premature failure under normal operating conditions. In-stock inventory ensures lead times of 3–7 business days for most destinations, with expedited options available for critical downtime situations.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| SKU / Part Number | 3HAC10602-2 |
| Compatible Robot Series | ABB IRB 1400, IRB 2400, IRB 4400, IRB 6400 |
| Motor Type | AC Brushless Servo Motor |
| Encoder Interface | Resolver / Serial Encoder (axis-dependent) |
| Mounting Interface | Direct flange-mount; matches OEM mechanical footprint |
| Drive Compatibility | ABB DSQC series drive units (DSQC 345, DSQC 346, DSQC 374) |
| Communication Protocol | Axis computer serial link via ABB S4 / S4C+ controller |
| Replacement Recommendation | Drop-in replacement for original 3HAC10602-2; verify axis number and cable harness routing |
| Commissioning Notes | Revolution counter update required after installation; use RobotStudio or FlexPendant |
| Warranty | 12 Months — covers manufacturing defects and premature failure under normal use |
Retrofit Planning for Existing Automation Systems
Successful integration of the 3HAC10602-2 into an existing IRB Series robot begins well before the motor is physically installed. Engineers should start by auditing the ABB S4 or S4C+ controller cabinet, confirming that the DSQC 345 or DSQC 346 drive module is serviceable and that the axis computer board — typically a DSQC 374 — is free of fault codes related to the affected axis. If the drive module shows recurring overcurrent or encoder loss faults, it is advisable to replace the drive unit concurrently with the motor to avoid repeat failures after commissioning.
Terminal wiring is a common source of commissioning delays. The 3HAC10602-2 uses a multi-pin motor connector that mates with the robot arm cable harness. Before disconnecting the old motor, photograph or document the cable routing through the robot’s lower arm and wrist sections. Pay particular attention to the resolver cable shield termination at the drive end — improper shield grounding is a leading cause of encoder noise faults (error code 50024 or 50025 on S4C+ systems). If the existing cable harness shows signs of insulation fatigue or connector corrosion, replacing the motor cable assembly — available as ABB part 3HAC10602-1 or equivalent — at the same time eliminates a common callback risk.
For sites running ABB IRC5 controllers alongside legacy S4C+ cells, the retrofit planning scope may extend to evaluating whether the IRB axis configuration in RobotStudio matches the physical motor parameters after replacement. The IRC5 controller uses a different axis computer architecture (DSQC 668 or DSQC 693) and communicates with drive modules via the internal drive bus, so cross-platform compatibility must be confirmed before assuming a direct swap. In mixed-fleet environments, it is also worth auditing the PROFIBUS DP or DeviceNet network topology to ensure that the robot’s I/O scanner — often a DSQC 352 or DSQC 378 fieldbus adapter — remains correctly addressed after the maintenance window.
Power supply capacity is another pre-retrofit checkpoint. The ABB S4C+ controller’s internal power distribution unit must be able to sustain peak servo current demand during acceleration cycles. If the control cabinet also houses a DSQC 508 I/O unit or additional DSQC 355 analog I/O modules, verify that the 24 VDC rail loading remains within specification. Overloaded power rails are a silent cause of intermittent axis faults that are difficult to diagnose after the fact.
HMI considerations should not be overlooked. If the production cell uses an ABB FlexPendant (IRC5) or a legacy TP (Teach Pendant) on S4C+, confirm that any axis-specific screen configurations or custom RAPID program references to the replaced axis are reviewed before returning the robot to automatic mode. In some installations, third-party SCADA or MES systems monitor axis torque or position data via OPC-UA or Ethernet/IP; these data paths should be validated post-commissioning to ensure reporting continuity.
Downtime Control During System Migration
Minimizing unplanned downtime during a servo motor replacement on an IRB Series robot requires a structured approach that protects both the original program logic and the physical safety of the work cell. The recommended sequence is: (1) back up the complete robot system — including RAPID modules, I/O configuration, and safety parameters — using RobotStudio or the FlexPendant backup function before any hardware is touched; (2) isolate the robot from the production line using the controller’s external emergency stop chain and confirm zero-energy state on the drive bus; (3) perform the mechanical swap and cable reconnection; (4) power up in manual mode and execute a revolution counter update on the affected axis; (5) run a slow-speed dry cycle through the full working envelope to verify position accuracy and absence of fault codes; (6) restore automatic mode and monitor the first production cycle for thermal and current anomalies.
For facilities that cannot tolerate extended downtime, SMARTNEXMSK offers pre-tested exchange units that can be shipped ahead of the planned maintenance window. Having a verified spare on-site before the old motor is removed eliminates the risk of extended downtime caused by shipping delays or incoming inspection failures. The 12-month warranty on all supplied units applies from the date of invoice, giving maintenance teams a full year of coverage from the moment the replacement is commissioned.
Where the original RAPID program references axis-specific motion instructions with fine-tuned path accuracy parameters, it is strongly recommended to retain a copy of the original system backup even after the new motor is confirmed operational. This provides a rollback reference if subtle path deviations are detected during the first production quality audit.
Retrofit Support FAQ
Q1: Is the 3HAC10602-2 a direct drop-in replacement for the original ABB part?
Yes. The 3HAC10602-2 supplied by SMARTNEXMSK matches the OEM mechanical interface, encoder type, and electrical connector pinout. No modification to the robot arm structure or cable harness is required in standard IRB 1400, IRB 2400, IRB 4400, and IRB 6400 applications. A revolution counter update via the FlexPendant or RobotStudio is required after installation — this is a standard ABB commissioning step and does not indicate incompatibility.
Q2: What pre-shipment testing is performed on each unit?
Every 3HAC10602-2 unit undergoes winding resistance measurement, insulation resistance testing (Megger test at 500 VDC), and encoder signal verification before shipment. A test report is available upon request. Units are packed in anti-static, shock-absorbing packaging to prevent transit damage. The 12-month warranty covers manufacturing defects and premature failure under normal operating conditions from the date of invoice.
Q3: Can this motor be used with an ABB IRC5 controller, or is it limited to S4/S4C+?
The 3HAC10602-2 was originally specified for ABB S4 and S4C+ controller platforms. Compatibility with IRC5 depends on the specific robot model and axis configuration. Customers integrating this motor into an IRC5-controlled robot should confirm the axis motor parameter file (MOC.cfg) matches the motor’s rated torque, speed, and encoder resolution. SMARTNEXMSK’s technical team can assist with parameter file review prior to purchase — contact [email protected] with your robot serial number and controller type.
Q4: What is the warranty coverage and what does it include?
All units carry a 12-month warranty from the date of invoice. Coverage includes manufacturing defects, premature bearing failure, winding insulation breakdown, and encoder signal failure under normal operating conditions. Warranty claims require the unit to be returned in its original packaging with a fault description. Physical damage caused by incorrect installation, overvoltage, or contamination is excluded. Replacement or repair is completed within 10 business days of receiving the returned unit.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341