ABB 3HAC3941-1 Maintenance-Ready Spare IRB 4400 Automation
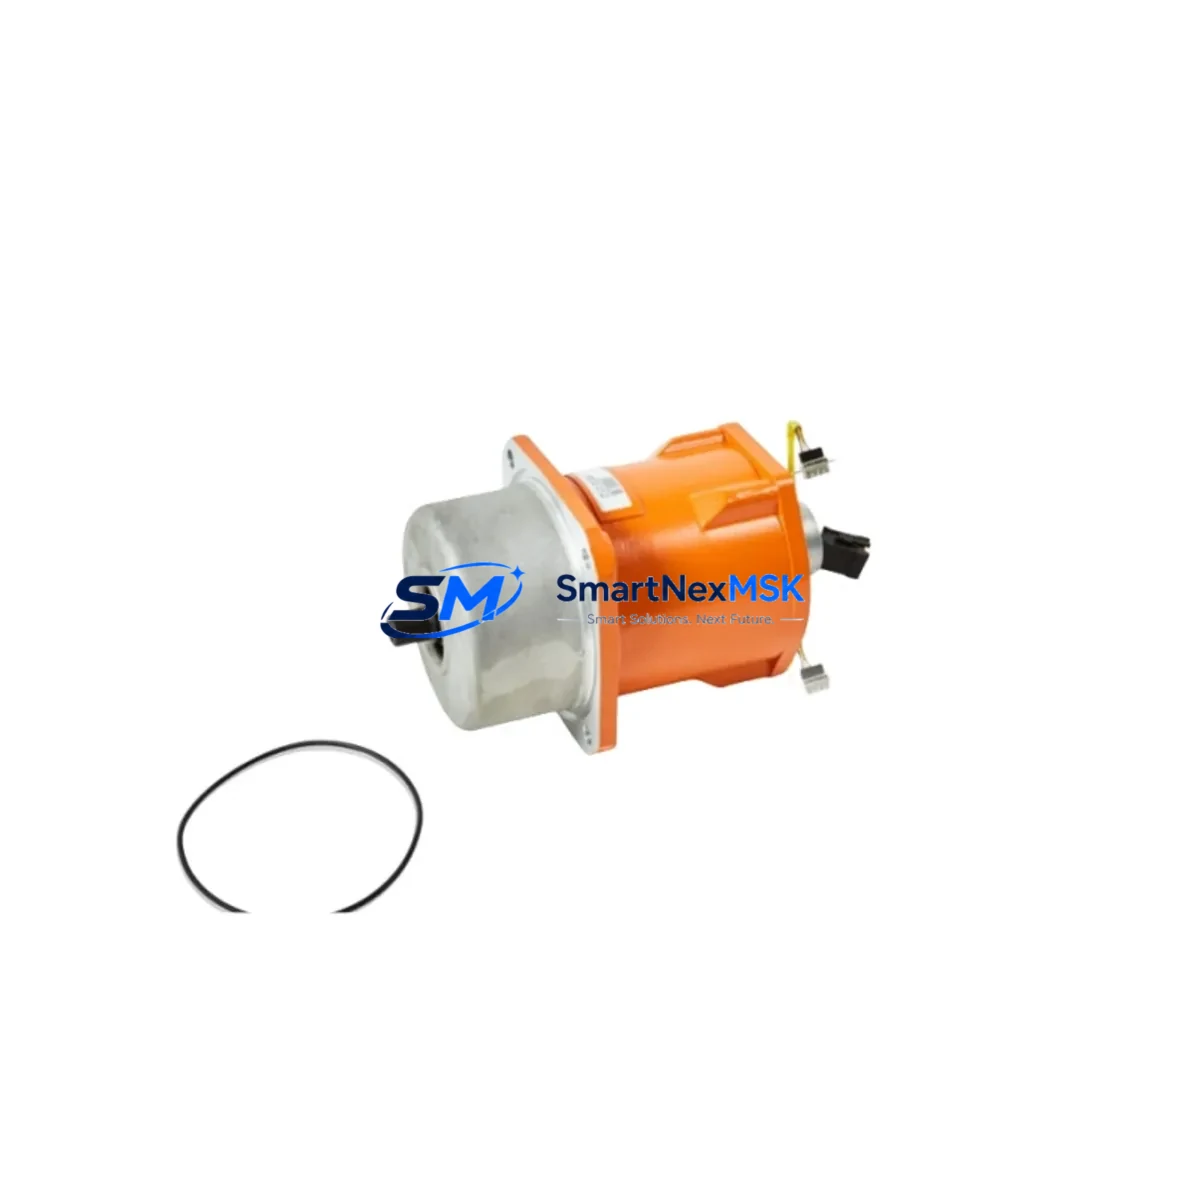
The ABB 3HAC3941-1 is an original servo motor with pinion, purpose-built for axis drive applications in the ABB IRB 4400 industrial robot series. For maintenance engineers managing robotic welding cells, material handling lines, or precision assembly systems, this component represents a critical spare that directly determines system uptime. Sourced from verified supply channels, each unit undergoes functional inspection and electrical testing prior to shipment, ensuring it arrives ready for immediate installation without additional bench validation.
Unplanned downtime caused by servo motor failure in an IRB 4400 cell can halt an entire production line within minutes. Stocking the 3HAC3941-1 as a ready spare eliminates the lead-time gap that typically extends emergency shutdowns from hours into days. Whether you are managing a single robot or a multi-cell automation floor, having this unit on the shelf is a foundational element of any credible preventive maintenance program.
This listing covers the 3HAC3941-1 in its original ABB specification. Cross-reference part numbers including 3HAC050269-001 and 3HAB9047-1 have been verified against IRB 4400 axis configurations. Procurement engineers should confirm the axis assignment and gear ratio specification against the robot’s maintenance manual before ordering, particularly when replacing units on axis 1 through axis 6 drive trains where pinion engagement tolerances are critical.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | 3HAC3941-1 |
| Cross Reference | 3HAC050269-001 / 3HAB9047-1 / 3HAB8271-1 / 3HAC9841-1 |
| Compatible Series | ABB IRB 4400 (all variants) |
| Component Type | Servo Motor with Pinion — Axis Drive |
| Brand / Origin | ABB / Sweden (SE) |
| Condition | Original Spare — New or Refurbished-to-Spec |
| Weight | Approx. 200 g (motor assembly) |
| Application Environment | Industrial robot arm, enclosed control cabinet, IP54+ rated cell |
| Installation Interface | Pinion-drive axis mount; torque spec per IRB 4400 maintenance manual |
| Pre-Shipment Testing | Electrical continuity, insulation resistance, encoder signal verification |
| Warranty | 12 Months from date of shipment |
| Delivery | Express worldwide; DHL / FedEx / SF Express available |
| Maintenance Recommendation | Replace at first sign of encoder fault, axis overload alarm, or irregular motion profile |
Maintenance Planning for Continuous Operation
When a 3HAC3941-1 servo motor fault is confirmed on an IRB 4400 axis, experienced maintenance engineers know that the motor itself is rarely the only component requiring attention. A thorough site inspection should extend to the surrounding electrical and mechanical ecosystem to prevent repeat failures and ensure the replacement holds under production load.
Begin with the axis drive power supply — verify that the DC bus voltage feeding the servo drive is within specification, as undervoltage conditions accelerate motor winding stress. Inspect the servo drive unit (DSQC 661 or equivalent) for fault history logs; a drive that has been operating in overcurrent protection mode may have contributed to the motor failure. Check the motor power cable and resolver/encoder cable (typically routed through the robot arm conduit) for chafing, connector corrosion, or intermittent contact — these are common root causes of encoder fault alarms that are misdiagnosed as motor failures.
At the control cabinet level, inspect the IRC5 controller’s axis computer board and confirm firmware is current. Review the SMB (Serial Measurement Board) for battery status and calibration data integrity — an SMB with a depleted battery can corrupt axis position data and trigger false motor fault codes. The 24 VDC system power supply should be load-tested; marginal supplies cause intermittent I/O faults that mask underlying drive issues.
For the broader maintenance checklist, also evaluate: brake resistor condition on the drive module, terminal block integrity on the X1/X2 axis power connectors, contactor and relay condition in the main power distribution section, and the teach pendant (FlexPendant) cable for continuity. If the robot operates in a welding cell, inspect the weld interface board and fieldbus communication module (DeviceNet, PROFIBUS, or EtherNet/IP) for fault isolation. Keeping spare units of the SMB, servo drive, and encoder cable alongside the 3HAC3941-1 motor constitutes a complete axis-level spare kit for the IRB 4400 platform.
Site Replacement Workflow
Replacing the 3HAC3941-1 on an IRB 4400 follows a structured sequence to minimize downtime and avoid secondary damage. Before beginning, confirm the robot is in a safe, de-energized state with the main breaker locked out and the brake release procedure completed per the ABB IRB 4400 Product Manual (document 3HAC16590-1 or later revision).
Step 1 — Fault Isolation: Retrieve the error log from the IRC5 controller. Confirm the fault code maps to the specific axis and motor. Cross-check with the SMB calibration data to rule out position sensor issues before committing to motor replacement.
Step 2 — Motor Removal: Disconnect the motor power connector and encoder/resolver connector. Remove the axis cover and unfasten the motor mounting bolts per the torque specification in the maintenance manual. Extract the motor assembly carefully to avoid pinion gear damage.
Step 3 — Inspection and Preparation: Inspect the gear mesh surface and bearing housing for wear. Clean the mounting face. Verify the replacement 3HAC3941-1 pinion specification matches the removed unit before installation.
Step 4 — Installation and Calibration: Install the new motor, torque fasteners to specification, reconnect all cables, and restore power. Perform axis calibration using the ABB calibration routine. Run a slow-speed test cycle before returning the robot to production speed.
Step 5 — Documentation: Log the replacement in the maintenance record, update the spare parts inventory, and schedule the next inspection interval. For aging IRB 4400 systems beyond 10 years of service, consider a full axis bearing and seal inspection during the same maintenance window to extend system life without additional downtime events.
Spare Parts Support FAQ
Q1: Is the 3HAC3941-1 compatible with all IRB 4400 variants, including the IRB 4400/60 and IRB 4400/45?
The 3HAC3941-1 is the standard servo motor with pinion for the IRB 4400 series. Compatibility across payload variants (45 kg, 60 kg) depends on the specific axis assignment. Always cross-reference the robot’s serial number and axis configuration against the ABB spare parts catalog or contact our technical team with your robot’s nameplate data for confirmation before ordering.
Q2: What pre-shipment testing is performed on each unit?
Every 3HAC3941-1 unit is tested for electrical continuity across all motor windings, insulation resistance between phases and ground, and encoder/resolver signal output verification. Units that do not meet specification thresholds are not shipped. A test report is available upon request for quality-critical procurement processes.
Q3: How should the 3HAC3941-1 be stored if purchased as a long-term spare?
Store in original packaging or anti-static, moisture-resistant packaging in a temperature-controlled environment (5°C–40°C, <85% RH non-condensing). Rotate stock on a first-in, first-out basis. The 12-month warranty period begins from the date of shipment, so coordinate procurement timing with your planned maintenance schedule to maximize warranty coverage during the active service window.
Q4: What is the lead time, and is express shipment available for emergency downtime situations?
In-stock units ship within 1–2 business days. Express courier options (DHL Express, FedEx International Priority, SF Express for Asia-Pacific) are available at checkout. For critical production downtime situations, contact our sales team directly to arrange same-day dispatch where stock and logistics permit.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341