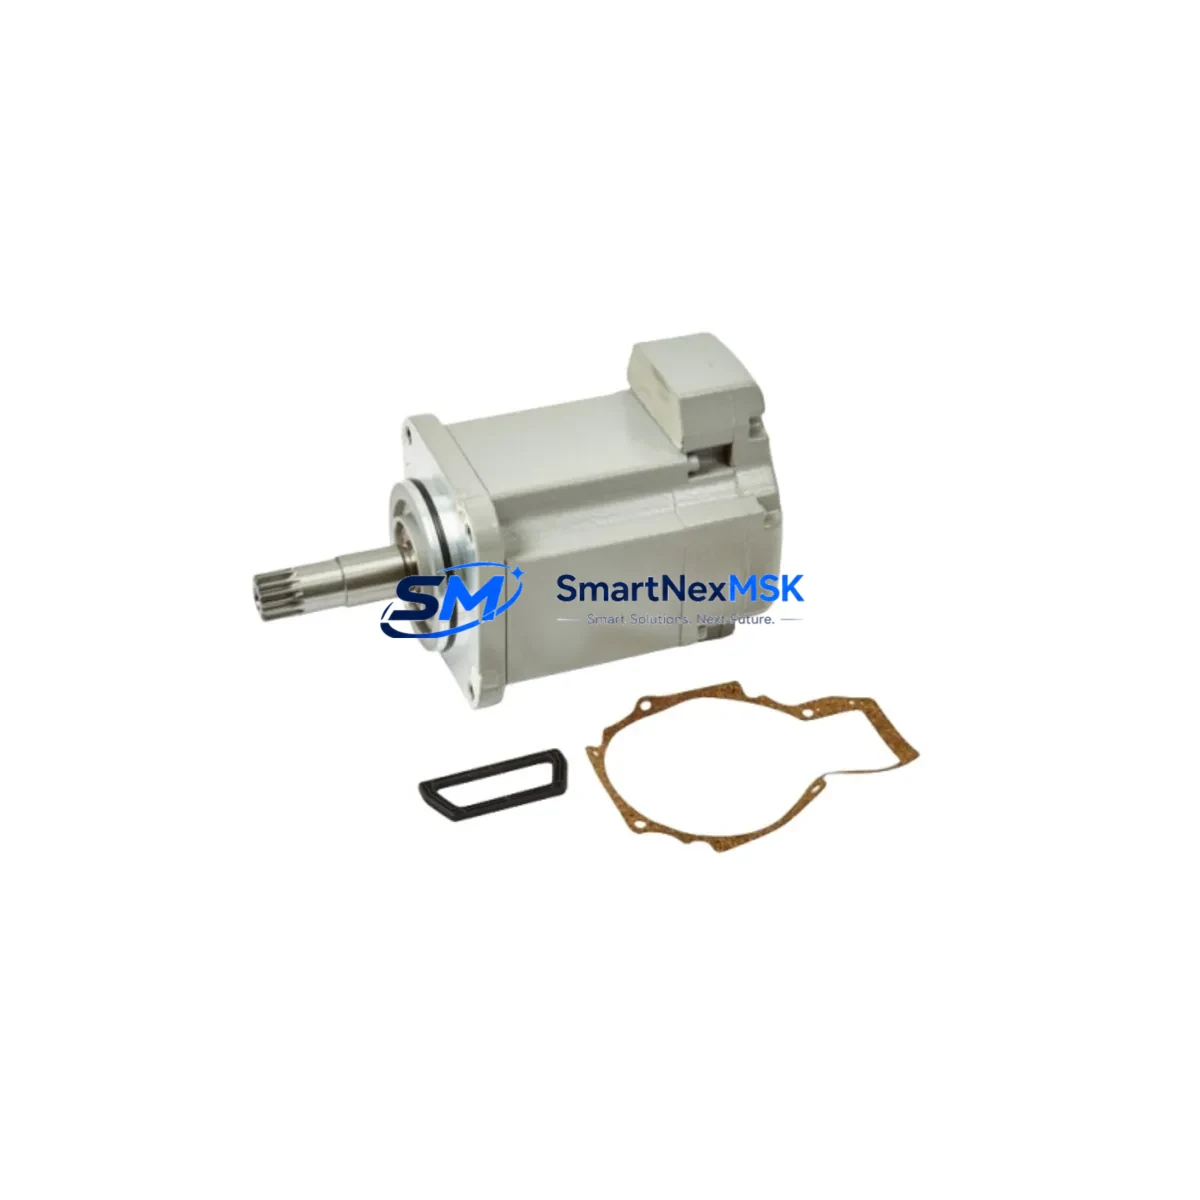
ABB 3HNA003542-001 Retrofit-Ready Servo Motor for IRB6700 Control Systems: Seamless Compatibility and Legacy System Upgrade
The ABB 3HNA003542-001 is a precision servo motor assembly engineered for direct retrofit into ABB IRB6700-150/3.20 industrial robot systems. As automation facilities face increasing pressure to extend the operational life of legacy robot cells while maintaining production throughput, the 3HNA003542-001 provides a verified drop-in replacement path that eliminates the need for full robot replacement. Whether you are recovering from an unplanned motor failure, executing a scheduled overhaul, or upgrading an aging IRB6700 line, this unit delivers the mechanical and electrical compatibility required for a controlled, low-risk migration.
This servo motor is fully compatible with the ABB IRC5 controller platform, which governs axis motion, feedback processing, and drive communication across the IRB6700 family. The unit interfaces directly with the SMB (Serial Measurement Board), typically referenced as 3HAC061315-003, and communicates via the resolver feedback loop that ABB’s motion control architecture depends on. Engineers replacing a failed axis motor should verify that the SMB firmware version aligns with the replacement unit’s encoder protocol before powering the system. In most IRB6700 installations, the axis 1 through axis 6 drive modules housed within the IRC5 cabinet — including the DSQC662 drive unit — do not require reconfiguration when a like-for-like motor swap is performed using the 3HNA003542-001.
Upgrade Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Model | ABB IRB6700-150/3.20 |
| Replaces OEM Part | 3HNA003542-001, 3HNE02177-1 |
| Controller Compatibility | ABB IRC5 (single and dual cabinet) |
| Feedback Interface | Resolver / SMB (3HAC061315-003) |
| Drive Unit Compatibility | DSQC662, DSQC663 axis drive modules |
| Mounting Interface | Direct bolt-on, OEM flange pattern |
| Communication Protocol | ABB proprietary resolver loop (no fieldbus reconfiguration required) |
| Installation Requirement | Fine calibration via RobotStudio or FlexPendant after swap |
| Retrofit Complexity | Low — like-for-like replacement, no mechanical adaptation required |
| Warranty | 12 Months from date of shipment |
Retrofit Planning for Existing Automation Systems
A successful IRB6700 servo motor retrofit begins well before the replacement unit arrives on-site. Maintenance engineers should pull the current robot configuration backup from the IRC5 controller using RobotStudio, preserving all axis calibration offsets, tool data, and work object definitions. This backup protects the production program in the event that the FlexPendant calibration sequence introduces any offset drift during the fine-calibration step after motor installation.
Before removing the failed motor, document the existing cable routing for the motor power connector (typically an MP connector on the lower arm harness) and the resolver signal cable that feeds back to the SMB board. The 3HNA003542-001 uses the same connector pinout as the original OEM unit, so no wiring adapter is required. However, technicians should inspect the condition of the 3HAC044168-001 motor cable harness and replace it if insulation wear is detected — a degraded harness is a common secondary failure point in high-cycle IRB6700 installations.
For facilities running multiple IRB6700 units on the same production line, it is advisable to maintain a spare DSQC662 drive module in the control cabinet spares kit alongside the servo motor. Drive module failures and motor failures often share root causes in high-duty-cycle environments, and having both components available reduces the risk of a second unplanned stoppage during the same maintenance window. Similarly, the SMB unit (3HAC061315-003) should be tested during the motor swap — an SMB with degraded resolver signal conditioning can cause persistent axis error alarms even after a new motor is installed.
Facilities that have integrated the IRB6700 with a PROFINET or DeviceNet fieldbus network via an DSQC688 or DSQC652 communication board will find that the motor replacement does not affect fieldbus addressing or PLC I/O mapping. The Siemens S7-300 or S7-1500 PLC managing the robot cell’s safety interlock and conveyor synchronization signals will continue to operate without modification. However, the safety controller — often a JSHD4 or equivalent safety board within the IRC5 — should be verified for correct axis supervision parameters after calibration is complete.
Where the IRB6700 is mounted on a servo-driven track or positioner, the track drive controller and its associated encoder feedback should be checked for synchronization integrity after the robot axis motor is replaced. Any residual position offset in the robot’s base frame relative to the track zero point must be corrected in the robot’s base coordinate calibration before resuming production.
Downtime Control During System Migration
Minimizing unplanned downtime during a servo motor replacement on an IRB6700 requires a structured pre-swap checklist and a clear sequence of operations. The recommended approach is to perform the motor swap during a scheduled maintenance window rather than under emergency conditions, using the following sequence:
First, create a full system backup via RobotStudio before any mechanical work begins. This preserves the RAPID program, I/O configuration, tool data, and all calibration offsets. Second, power down the IRC5 cabinet following the ABB lockout/tagout procedure, and allow the drive capacitors to discharge fully before opening the cabinet or touching motor connectors. Third, replace the 3HNA003542-001 motor using the OEM torque specifications for all fasteners — under-torqued motor mounts are a leading cause of vibration-induced calibration drift in high-payload robot axes.
After mechanical installation, perform the fine calibration sequence using the FlexPendant’s calibration wizard. For axis 1 motors, this typically involves a pendulum calibration or a reference mark alignment depending on the robot’s calibration method. Once calibration is confirmed within tolerance, run the robot through a slow-speed dry cycle of the production program before restoring full speed and payload. This step catches any residual offset that could cause a path deviation or collision with fixturing.
For facilities where continuous production is critical, consider maintaining a pre-tested, pre-calibrated spare IRB6700 axis motor in stock. A pre-calibrated unit — one that has been bench-tested and had its resolver offset recorded — can reduce on-site calibration time significantly, compressing total downtime from several hours to under 90 minutes in experienced maintenance teams.
Retrofit Support FAQ
Q: Is the 3HNA003542-001 a direct replacement for 3HNE02177-1?
A: Yes. The 3HNA003542-001 supersedes the 3HNE02177-1 in ABB’s parts catalog and is the current recommended replacement for IRB6700-150/3.20 axis motor applications. No mechanical or electrical adaptation is required for a direct swap.
Q: Will I need to reconfigure the IRC5 controller or RAPID program after replacing the motor?
A: The RAPID program and I/O configuration do not require modification. However, a fine calibration of the replaced axis is mandatory after any servo motor swap. This is performed via the FlexPendant calibration wizard and typically takes 30–60 minutes depending on the axis and calibration method in use.
Q: What pre-shipment testing is performed on the 3HNA003542-001?
A: Each unit undergoes electrical continuity testing, resolver signal verification, and insulation resistance testing prior to shipment. Units are packaged with anti-static protection and shock-absorbing foam to prevent transit damage. A test report is available upon request.
Q: What warranty coverage is provided?
A: All 3HNA003542-001 units supplied by SMARTNEXMSK carry a 12-month warranty from the date of shipment, covering manufacturing defects and premature failure under normal operating conditions. Warranty claims are supported by our technical team with replacement dispatch within 5 business days upon fault confirmation.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341