ABB MTD5003HAC038210-002 Spare IRB6600 Automation: Downtime Control Through Verified Spare Parts
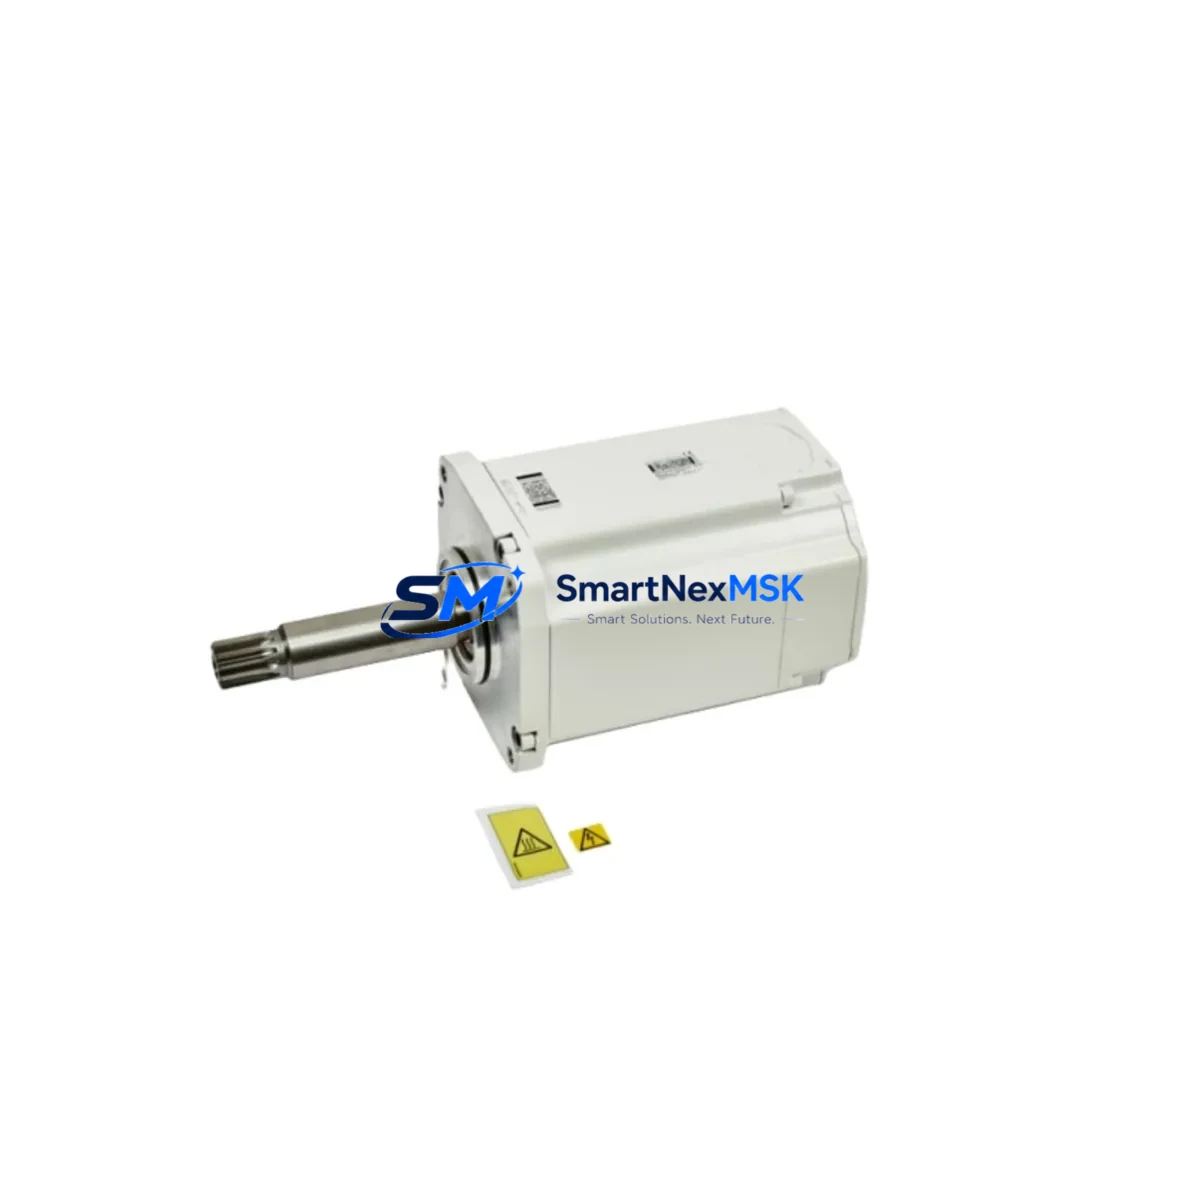
The ABB MTD5003HAC038210-002 is an original Axis 1 servo motor assembly engineered for the IRB6600 industrial robot series, cross-referenced as 3HAC034644-003 and 3HAC052991-005. This unit is a direct drop-in replacement for aging or failed drive components in high-cycle manufacturing environments. Whether your facility runs continuous automotive body welding, heavy-duty material handling, or foundry automation, maintaining a verified spare of this servo motor assembly is a cornerstone of any credible downtime-reduction strategy.
Sourced from ABB’s original supply chain and tested prior to dispatch, each unit ships with a 12-month warranty covering manufacturing defects and functional performance. Our pre-shipment inspection protocol includes insulation resistance verification, encoder signal integrity check, and mechanical shaft runout measurement — ensuring the replacement unit performs to OEM specification from the moment it is installed.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | MTD5003HAC038210-002 |
| Cross Reference | 3HAC034644-003 / 3HAC052991-005 |
| Brand | ABB Robotics |
| Series Compatibility | IRB6600 (IRB6600-175/2.55, IRB6600-200/2.75) |
| Axis | Axis 1 — Base Rotation |
| Component Type | AC Servo Motor Assembly |
| Origin | Sweden (ABB OEM) |
| Encoder Type | Resolver / Absolute Encoder (OEM matched) |
| Mounting | Direct flange mount, OEM bolt pattern |
| Application Environment | Industrial robot cell, foundry, automotive, heavy manufacturing |
| IP Rating | IP67 (per IRB6600 OEM specification) |
| Maintenance Interval | Per ABB IRC5 controller maintenance schedule |
| Pre-Shipment Test | Insulation resistance, encoder signal integrity, shaft runout |
| Warranty | 12 Months — Manufacturing defects & functional performance |
| Lead Time | In-stock: ships within 1–3 business days |
Maintenance Planning for Continuous Operation
When a maintenance or procurement engineer schedules replacement of the MTD5003HAC038210-002 servo motor on an IRB6600 robot, the replacement event should be treated as a full Axis 1 drivetrain audit — not a single-component swap. A failed or degraded servo motor rarely fails in isolation; the surrounding electrical and mechanical ecosystem must be inspected concurrently to prevent repeat failures and unplanned stoppages.
Begin by auditing the ABB IRC5 controller drive module (DSQC661 or DSQC662 axis computer board) for fault logs and thermal stress indicators. A degraded servo motor often generates overcurrent events that stress the drive electronics upstream. Simultaneously, inspect the motor power cable assembly (3HAC031683-001) and the signal/resolver cable (3HAC031682-001) for insulation breakdown, connector corrosion, and bend-radius fatigue — both cables run through the robot base and are subject to continuous torsional stress on Axis 1.
The SMB Serial Measurement Board (3HAC14550-1) should be read for encoder error history before and after motor replacement. If the SMB has logged repeated resolver faults, it may require replacement alongside the motor to ensure clean position feedback. The Axis 1 gearbox (3HAC028845-001) should be inspected for backlash and lubrication condition; a worn gearbox accelerates motor bearing fatigue and can cause premature failure of a newly installed servo unit.
On the power distribution side, verify the IRC5 power supply unit (DSQC609) output voltage stability under load. Voltage sag during Axis 1 acceleration cycles is a known contributor to servo motor thermal stress in high-duty-cycle applications. Check the main contactor (3HAC025562-001) for contact wear and verify that the brake resistor assembly is within specification — a degraded brake resistor can cause regenerative energy spikes that damage motor windings.
For facilities running multiple IRB6600 units, it is best practice to maintain a consolidated spare kit that includes the MTD5003HAC038210-002 motor, the SMB board, both motor cables, and a set of Axis 1–3 gearbox seals. This approach eliminates secondary downtime caused by discovering adjacent component failures mid-repair. Procurement engineers should also consider stocking the teach pendant cable (3HAC031683-003) and a spare FlexPendant (3HAC028357-001), as HMI failures during a robot restart after maintenance are a common source of extended downtime.
Site Replacement Workflow
Replacing the MTD5003HAC038210-002 on an IRB6600 follows ABB’s standard Axis 1 motor exchange procedure. Before beginning, confirm the IRC5 controller is in manual mode and the robot is mechanically locked at the Axis 1 zero position using the calibration pin. Power down the controller and discharge the drive capacitors per the IRC5 maintenance manual — wait a minimum of 5 minutes after power-off before opening the controller cabinet.
Disconnect the motor power connector and resolver/encoder connector at the robot base. Remove the motor mounting bolts (typically M10 class 10.9) and extract the motor assembly. Install the replacement MTD5003HAC038210-002 using new fasteners torqued to ABB specification. Reconnect both cables, ensuring the resolver connector is fully seated and the locking ring is engaged — a partially connected resolver is the most common cause of post-replacement encoder faults.
After mechanical installation, perform a revolution counter update via the IRC5 FlexPendant before returning the robot to automatic mode. Failure to update the revolution counter will result in axis position errors and potential collision risk. Run the robot through a slow-speed calibration cycle and verify Axis 1 position accuracy against the calibration target before resuming production. Log the replacement in the robot’s maintenance record and set a reminder for the next scheduled gearbox lubrication interval.
This workflow minimizes total downtime to under 4 hours for a prepared maintenance team with the spare unit on-site — compared to 3–10 days of production loss waiting for an unplanned procurement cycle. Compatibility with legacy IRB6600 installations is confirmed; no firmware changes to the IRC5 controller are required when replacing like-for-like with the OEM part number.
Spare Parts Support FAQ
Q1: Is the MTD5003HAC038210-002 compatible with all IRB6600 variants?
Yes. The MTD5003HAC038210-002 (cross-ref: 3HAC034644-003 / 3HAC052991-005) is the OEM Axis 1 servo motor for the IRB6600 series, covering the -175/2.55 and -200/2.75 payload/reach configurations. Always verify the robot’s serial number and axis configuration against ABB’s spare parts catalog before ordering if your unit has been field-modified.
Q2: What pre-shipment testing is performed on each unit?
Every unit undergoes insulation resistance testing (megger test), encoder/resolver signal integrity verification, and mechanical shaft runout measurement before dispatch. Units that do not meet OEM specification thresholds are quarantined and not shipped. A test report is available upon request.
Q3: How should this spare be stored in a maintenance inventory?
Store in original packaging in a dry, temperature-controlled environment (5–40°C, <85% RH non-condensing). Avoid storing near strong magnetic fields or vibration sources. Rotate stock on a FIFO basis and inspect annually for packaging integrity. Shelf life in proper storage conditions exceeds 3 years.
Q4: What is covered under the 12-month warranty?
The 12-month warranty covers manufacturing defects, encoder/resolver failure, winding insulation breakdown, and bearing failure under normal operating conditions. Warranty claims require photographic documentation of the installation and the IRC5 fault log at the time of failure. Physical damage from incorrect installation, overvoltage, or contamination is excluded. Contact [email protected] to initiate a warranty claim.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341