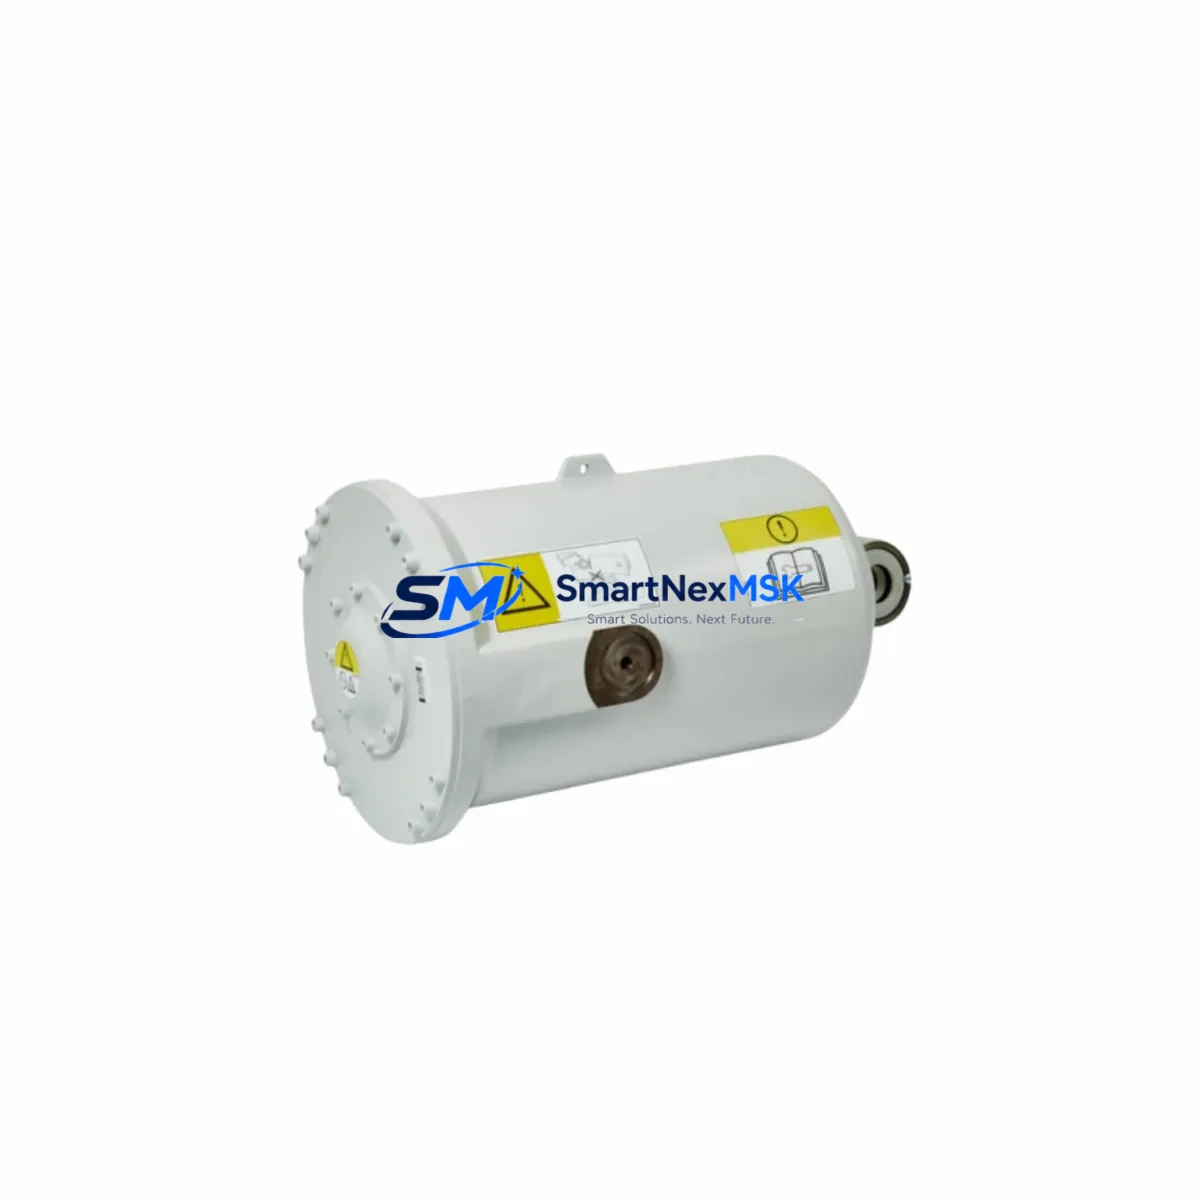
ABB MU400 3HAC040658-002 Spare for IRB4600 Automation: Spare Replacement & Industrial Downtime Risk Control
The ABB MU400 3HAC040658-002 is an original spring balancing unit designed for the IRB4600 series industrial robot. In high-cycle manufacturing environments — automotive body shops, metal fabrication lines, and general assembly cells — the spring balancing unit plays a critical role in counterbalancing the robot arm’s axis load, reducing servo motor stress, and maintaining positional accuracy over extended operational cycles. When this component degrades or fails, the robot may exhibit abnormal axis torque alarms, reduced repeatability, or complete motion lockout, triggering unplanned downtime that can cost thousands per hour.
Sourced as an original ABB spare, the 3HAC040658-002 is manufactured to the same specification as the unit installed at the factory. Maintenance engineers and procurement teams can rely on this part for direct drop-in replacement without parameter reconfiguration or mechanical adaptation. Each unit is inspected and tested prior to shipment, and is covered by a 12-month warranty against manufacturing defects.
Spare Maintenance Table
| Parameter | Specification |
|---|---|
| Part Number | 3HAC040658-002 |
| Model / Assembly | MU400 Spring Balancing Unit |
| Compatible Robot Series | ABB IRB4600 (all variants: IRB4600-20/2.50, IRB4600-40/2.55, IRB4600-45/2.05, IRB4600-60/2.05) |
| Cross-Reference SKUs | 3HAC039473-003, 3HAC051384-002 |
| Origin | Sweden (ABB Robotics) |
| Weight | Approx. 400 g |
| Application | Axis 2 / Axis 3 spring counterbalance mechanism |
| Installation Environment | Industrial robot cell; IP54 or better enclosure recommended |
| Maintenance Interval | Per ABB Product Manual — typically inspected at 20,000-hour service intervals |
| Replacement Type | Direct OEM replacement — no parameter change required |
| Pre-Shipment Testing | Yes — functional and dimensional inspection |
| Warranty | 12 Months from date of shipment |
Maintenance Planning for Continuous Operation
When a maintenance engineer schedules replacement of the 3HAC040658-002 spring balancing unit on an IRB4600 robot, the work order should not be limited to the balancing unit alone. A comprehensive inspection of the surrounding mechanical and electrical systems is essential to prevent repeat failures and maximize the value of the planned downtime window.
Begin with the ABB DSQC652 digital I/O board — verify that all digital output channels controlling the robot’s end-of-arm tooling and safety interlocks are functioning correctly before and after the mechanical replacement. Simultaneously, inspect the ABB DSQC661 axis computer for any stored fault logs related to axis 2 or axis 3 torque overload, which may indicate that the balancing unit had been degraded for some time prior to failure. If the robot controller is an IRC5 cabinet, check the ABB DSQC609 power supply unit for output voltage stability — a marginal power supply can mask itself as a mechanical fault during high-load axis movements.
The SMB (Serial Measurement Board), part 3HAC044168-001, should be inspected for resolver signal integrity on axes 2 and 3, as mechanical shock from a failing spring unit can introduce resolver offset errors. Wiring harnesses connecting the SMB to the axis motors — particularly the 3HAC031683-001 axis 2 motor cable — should be checked for chafing or connector corrosion at the cabinet entry point.
For the control cabinet itself, inspect the ABB DSQC508 fieldbus adapter or equivalent communication module for any intermittent DeviceNet or PROFIBUS faults logged during the period of mechanical degradation. Relay modules on the safety chain — including the ABB SF4 safety relay or equivalent — should be tested for contact resistance and response time. Terminal blocks on the X1 and X2 connector strips inside the IRC5 cabinet are a common source of high-resistance connections that develop unnoticed during vibration-intensive operation.
If the facility operates multiple IRB4600 units, procurement engineers should consider stocking the 3HAC040658-002 alongside the 3HAC039473-003 balancing unit variant and the 3HAC051384-002 cross-reference assembly to cover the full IRB4600 payload range. Maintaining a minimum of one spare per robot cell reduces mean time to repair (MTTR) from days to hours in the event of an unplanned failure.
Site Replacement Workflow
The 3HAC040658-002 is a direct replacement for the MU400 assembly on all IRB4600 variants. The replacement procedure follows ABB Product Manual section for axis 2/3 spring unit exchange and does not require robot recalibration in most cases, provided the axis calibration marks are preserved during disassembly.
Step 1 — Isolation: Place the IRC5 controller in manual mode, engage the mechanical brake release tool, and support axis 2 arm with a suitable lifting fixture before releasing spring tension. Follow ABB lockout/tagout procedures per local safety regulations.
Step 2 — Removal: Disconnect the spring unit retaining pins and carefully release stored spring energy per the ABB service manual procedure. Do not attempt to disassemble the spring cartridge — the 3HAC040658-002 is replaced as a complete assembly.
Step 3 — Installation: Install the new 3HAC040658-002 unit, torque all fasteners to ABB specification, and verify that the spring pre-load is within the acceptable range using the ABB calibration tool. Reconnect all mechanical linkages and confirm free movement through the full axis range.
Step 4 — Verification: Power up the IRC5 controller, clear any stored axis fault codes, and run the robot through a slow-speed test cycle. Monitor axis 2 and axis 3 motor current via the ABB RobotStudio or FlexPendant diagnostics to confirm that torque levels have returned to baseline. Log the replacement in the robot’s maintenance record.
This workflow minimizes downtime to a single planned maintenance window and eliminates the risk of secondary failures caused by deferred inspection of adjacent components.
Spare Parts Support FAQ
Q1: Is the 3HAC040658-002 compatible with all IRB4600 payload variants?
Yes. The MU400 spring balancing unit 3HAC040658-002 is compatible with the full IRB4600 series, including the 20 kg, 40 kg, 45 kg, and 60 kg payload variants. Cross-reference part numbers 3HAC039473-003 and 3HAC051384-002 cover specific sub-variants — confirm your robot’s serial number and axis configuration against the ABB spare parts catalog before ordering if you are unsure which assembly applies.
Q2: What is included in the 12-month warranty, and how is a claim processed?
The 12-month warranty covers manufacturing defects and functional failure under normal operating conditions. It does not cover damage caused by improper installation, mechanical overload, or unauthorized modification. To initiate a warranty claim, contact [email protected] with the order number, robot serial number, and a description of the fault. Replacement or refund is processed within 5 business days of fault confirmation.
Q3: How is the part tested before shipment?
Each 3HAC040658-002 unit undergoes dimensional inspection and functional pre-shipment testing to verify spring pre-load force and mechanical integrity. Units that do not meet OEM specification are rejected. A test report is available upon request for quality-critical procurement processes.
Q4: Can this part be used to extend the life of an older IRB4600 system that is no longer under ABB service contract?
Yes. The 3HAC040658-002 is an original ABB spare and is fully compatible with IRB4600 systems regardless of their service contract status. Many facilities use genuine spare parts to extend the operational life of legacy robot cells by 5–10 years beyond the standard service lifecycle, deferring capital expenditure on new robot systems while maintaining production output and safety compliance.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341