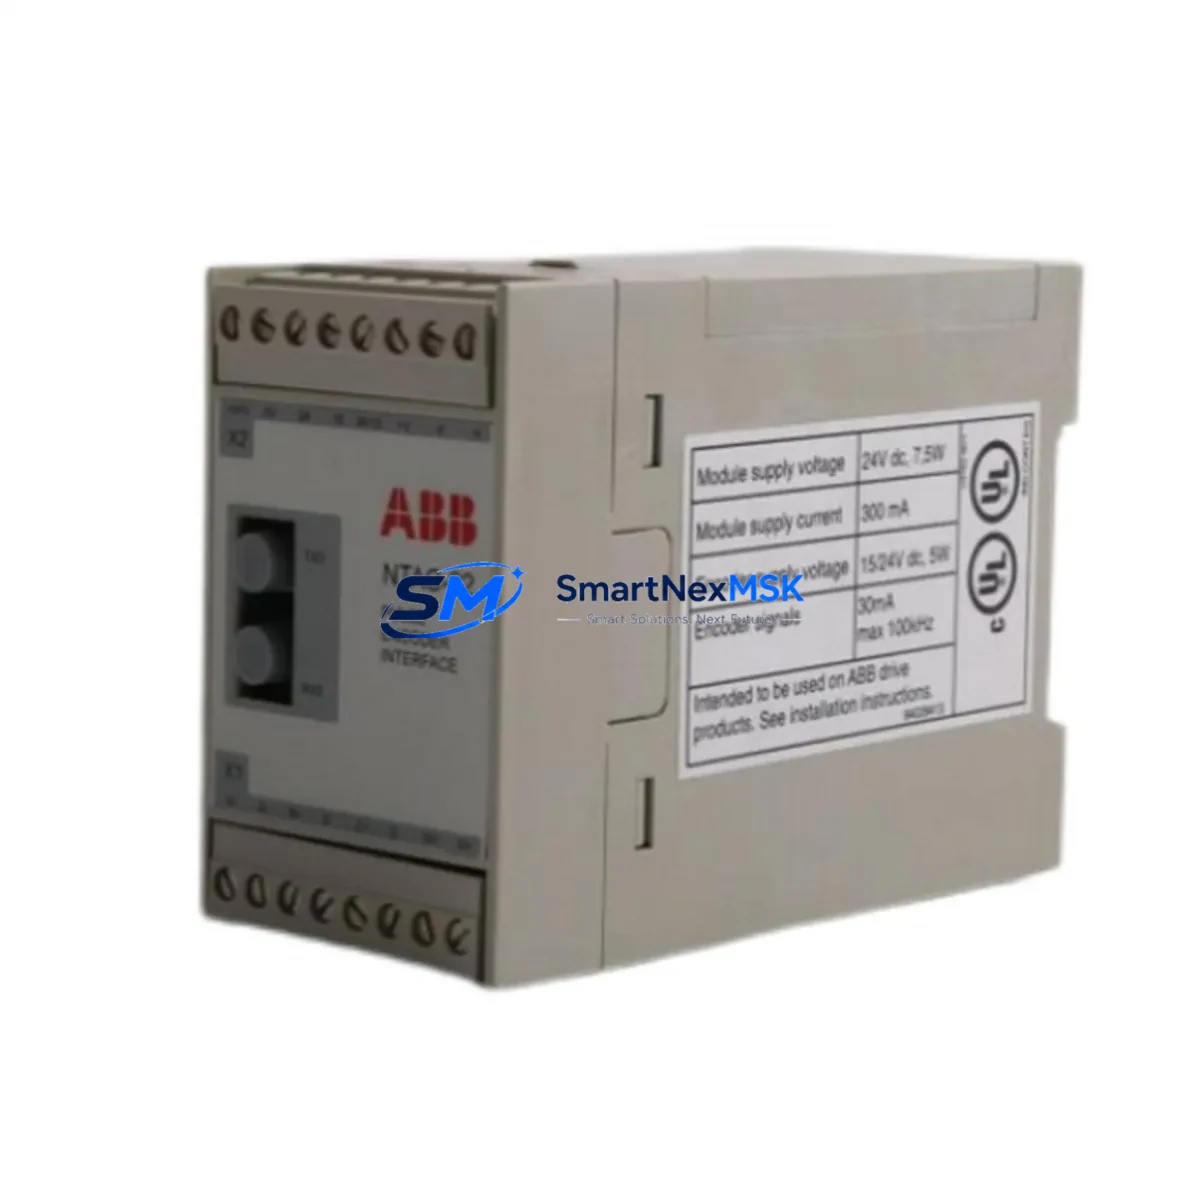
ABB SNAT 7261 QCP Retrofit-Ready Encoder Interface for ACS600 Control Systems
The ABB SNAT 7261 QCP is a pulse encoder interface board designed for use within the ACS600 series AC drive platform. As legacy ACS600 installations continue to operate across manufacturing, paper, metals, and process industries, the SNAT 7261 QCP has become a critical spare and retrofit component for engineers managing aging drive cabinets. Whether you are replacing a failed encoder feedback board, upgrading a discontinued unit, or modernizing a control system without full drive replacement, the SNAT 7261 QCP provides a verified, drop-in compatible solution that preserves your existing motor control logic and field wiring.
This board mounts directly into the ACS600 drive’s option slot and interfaces with incremental encoders to deliver closed-loop speed and position feedback to the drive’s RMIO control board. It supports standard HTL and TTL encoder signal types, making it compatible with a wide range of encoder hardware already installed in the field. For retrofit projects where the original encoder cannot be replaced, the SNAT 7261 QCP eliminates the need for signal converters or external interface modules, reducing panel complexity and commissioning time.
In modernization projects where the ACS600 drive itself is being retained but the control architecture is being updated — for example, migrating from a legacy DDCS fiber-optic fieldbus to a PROFIBUS DP or Modbus RTU network — the SNAT 7261 QCP continues to serve its encoder feedback role without modification. Engineers integrating the ACS600 into a new Siemens S7-300 or Allen-Bradley ControlLogix PLC environment via an NPBA-12 PROFIBUS adapter or NMBP-01 Modbus adapter will find that the encoder interface board operates independently of the fieldbus layer, ensuring a clean migration path.
For sites running multiple ACS600 units in a coordinated drive system — such as a multi-motor line shaft or a winder/unwinder pair — the SNAT 7261 QCP is typically installed across all speed-controlled axes. Replacement of a single failed board in such a system requires careful attention to encoder cable routing, differential signal integrity, and the drive’s parameter group 50 (encoder module settings) to ensure the replacement board is recognized correctly at power-up. Our pre-shipment testing protocol verifies board functionality against these parameters before dispatch.
Upgrade Compatibility Table
| Parameter | Detail |
|---|---|
| Compatible Drive Series | ABB ACS600 (all variants including ACS601, ACS604, ACS607) |
| Mounting Interface | ACS600 option slot (direct plug-in, no adapter required) |
| Encoder Signal Types | HTL (10–30 V), TTL (5 V differential) |
| Max Encoder Frequency | 200 kHz |
| Communication with RMIO | Internal drive backplane bus |
| Replaces / Supersedes | SNAT 7261 QCP (original), earlier SNAT 726x variants (verify slot compatibility) |
| Fieldbus Compatibility | Independent of fieldbus layer; compatible with NPBA-12, NMBP-01, NCAN-01 adapters |
| Installation Requirement | Drive must be powered down; parameter group 50 must be configured post-installation |
| Commissioning Tool | DriveWindow 2 or DriveWindow Light via RDCO-01 or RDCO-02 panel bus cable |
| Warranty | 12 months from date of shipment |
Retrofit Planning for Existing Automation Systems
A successful SNAT 7261 QCP retrofit begins well before the replacement board arrives on site. The first step is a full audit of the existing ACS600 drive cabinet: confirm the drive firmware version using the CDP-312 control panel or DriveWindow 2, document the current parameter set (especially groups 50, 51, and 98), and photograph the existing encoder cable terminations at the SNAT 7261 QCP terminal block. Encoder cables are typically shielded twisted-pair, and the shield grounding arrangement at the drive end must be replicated exactly on the replacement board to avoid noise-induced speed feedback errors.
In systems where the ACS600 is paired with an IOEC-3 or IOEC-4 I/O extension module for digital and analog I/O expansion, the encoder board replacement does not affect the IOEC wiring or configuration. However, if the drive is also equipped with an RTAC-01 pulse encoder interface for a second encoder channel, both boards should be inspected simultaneously to avoid a repeat shutdown. Similarly, if the control cabinet includes an RDCO-01 or RDCO-02 panel bus module for remote parameter access, verify that the panel bus communication is restored after the SNAT 7261 QCP is seated and the drive is powered up.
For sites migrating from a standalone ACS600 to a distributed control architecture — for example, integrating the drive into a DCS environment using a PROFIBUS DP network via the NPBA-12 adapter — the SNAT 7261 QCP retrofit can be completed in parallel with the fieldbus migration. The encoder board is configured independently through the drive’s parameter set, so fieldbus commissioning and encoder commissioning can proceed as separate workstreams, reducing total project duration.
Where the original ACS600 RMIO-01 or RMIO-11 control board is also degraded, it is advisable to replace both the RMIO board and the SNAT 7261 QCP in the same maintenance window. Attempting to commission a new encoder board on a marginal RMIO board risks misdiagnosis of encoder faults and unnecessary repeat shutdowns. Our team can supply both components as a verified matched set upon request.
Downtime Control During System Migration
Minimizing unplanned downtime during an ACS600 encoder board replacement requires a structured pre-outage preparation protocol. Before the maintenance window opens, upload the full drive parameter set using DriveWindow 2 and save it to a local file. This backup ensures that if the replacement SNAT 7261 QCP requires parameter re-entry, the process is a restore operation rather than a manual re-configuration from memory or paper records.
During the physical swap, the drive must be isolated from mains power and the DC bus must be fully discharged before the option slot cover is removed. The SNAT 7261 QCP connector is keyed, but the locking tab should be inspected for damage before insertion of the replacement board. After seating the board, restore power and use the CDP-312 panel or DriveWindow 2 to verify that parameter 98.01 (encoder module type) is correctly set and that the encoder pulse count (parameter 50.01) matches the installed encoder specification.
For production lines where even a brief speed feedback loss is unacceptable, consider pre-staging the replacement drive with the SNAT 7261 QCP already installed and parameters pre-loaded. A hot-swap of the entire drive unit — with the replacement unit pre-wired on a temporary rail — can reduce the active outage window to under 30 minutes for experienced commissioning teams. This approach is particularly effective in paper machine and metals rolling mill applications where the cost of extended downtime significantly exceeds the cost of a spare drive unit.
Retrofit Support FAQ
Q: Is the SNAT 7261 QCP a direct drop-in replacement for all ACS600 variants?
A: The SNAT 7261 QCP is compatible with the full ACS600 series, including ACS601, ACS604, and ACS607 variants, provided the drive has an available option slot. Confirm the slot designation in the drive’s hardware manual before ordering. If the existing board is a different SNAT 726x variant, verify the terminal block pinout matches before installation.
Q: What encoder types are supported, and do I need to change my existing encoder?
A: The SNAT 7261 QCP supports both HTL (10–30 V) and TTL (5 V differential) incremental encoders. In most retrofit scenarios, the existing field encoder does not need to be replaced. Confirm the encoder output voltage and signal type against the board’s specification sheet before installation.
Q: How do I verify the board is functioning correctly after installation?
A: After installation and parameter configuration, run the drive in local control mode at low speed and monitor the encoder feedback value in DriveWindow 2 or on the CDP-312 panel (parameter 01.04 or equivalent). The displayed speed should track the motor shaft speed accurately. If encoder fault F-23 or similar is displayed, recheck parameter group 50 settings and encoder cable shielding.
Q: What does the 12-month warranty cover?
A: All SNAT 7261 QCP units supplied by SMARTNEXMSK carry a 12-month warranty from the date of shipment, covering manufacturing defects and functional failures under normal operating conditions. Each unit undergoes pre-shipment functional testing. Warranty claims are supported by our technical team via email and phone. Units damaged by incorrect installation, overvoltage, or environmental contamination are not covered under the standard warranty.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341