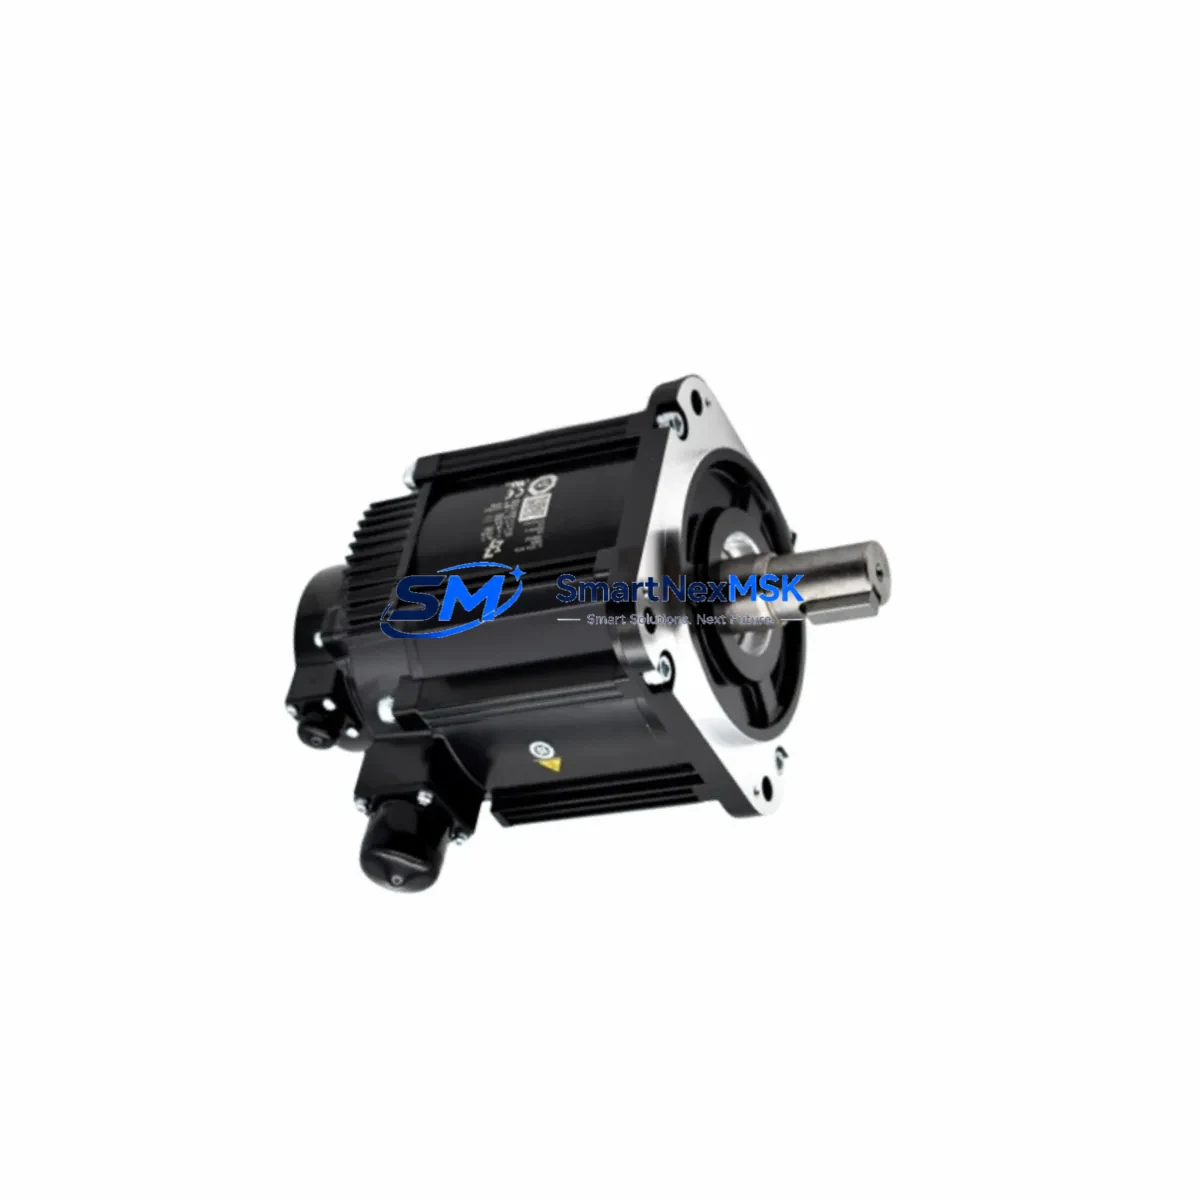
Yaskawa SGMRV-05ANA-YR21 Retrofit-Ready AC Servo Motor: Compatible Modernization & Smooth Upgrade for Legacy SGMRV Series Control Systems
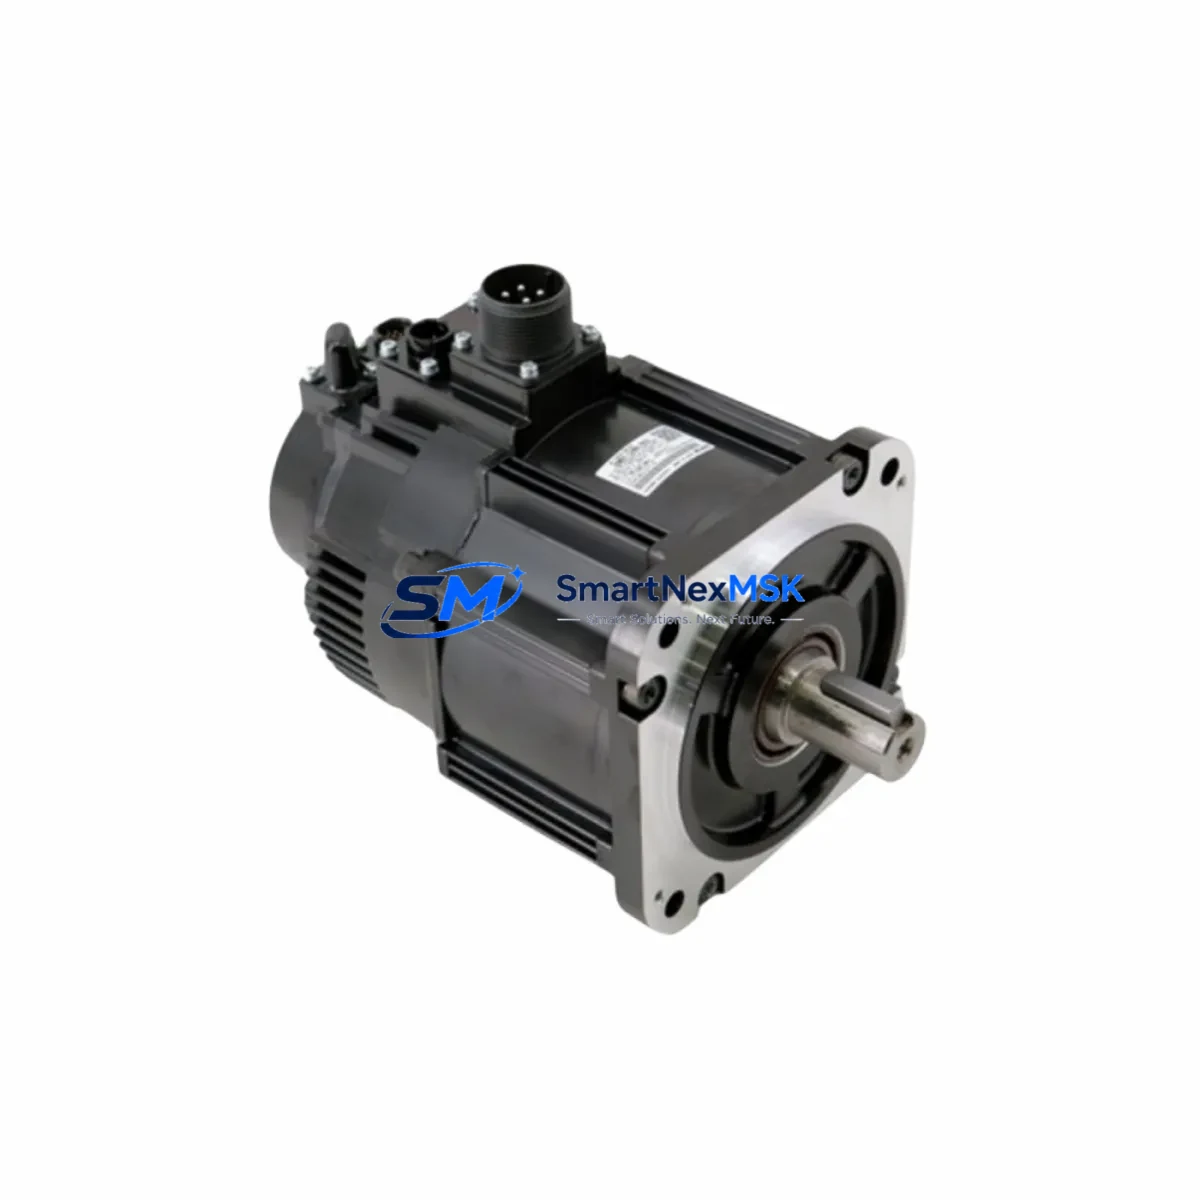
The Yaskawa SGMRV-05ANA-YR21 is a 400W hollow-shaft direct drive AC servo motor engineered for precision motion control in demanding industrial automation environments. As legacy SGMRV Series installations age and original spare parts become increasingly difficult to source, the SGMRV-05ANA-YR21 stands as the verified retrofit-ready replacement for discontinued or end-of-life units within the same platform. Whether you are managing a planned system upgrade, an emergency breakdown replacement, or a phased control cabinet modernization, this motor delivers the mechanical and electrical compatibility required to restore and extend production continuity with minimal disruption.
Designed to integrate directly into existing SGMRV Series servo systems, the SGMRV-05ANA-YR21 maintains dimensional compatibility with standard SGMRV mounting flanges and hollow-shaft configurations. Engineers undertaking retrofit projects should verify the encoder feedback type — the YR21 suffix designates an absolute encoder variant — and confirm that the paired SGDV or SGDH series servo drive is configured to accept absolute encoder signals. Where legacy drives are running incremental encoder firmware, a drive parameter update or drive replacement with a compatible SGDV-R70A or SGDV-1R6A unit may be required before commissioning the replacement motor.
Upgrade Compatibility Table
| Parameter | SGMRV-05ANA-YR21 (Replacement) | Notes / Retrofit Requirement |
|---|---|---|
| Rated Output | 400W | Matches original SGMRV-05 power class |
| Motor Type | Hollow-Shaft Direct Drive AC Servo | No gearbox required; verify shaft bore diameter |
| Encoder Type | Absolute (YR21 suffix) | Drive must support absolute encoder; check SGDV parameter Pn002 |
| Mounting Interface | Standard SGMRV flange | Direct bolt-on; no adapter plate required for same-series frames |
| Communication Compatibility | MECHATROLINK-II / MECHATROLINK-III (drive-dependent) | Confirm drive firmware version supports target protocol |
| Power Supply | Three-phase 200V AC | Verify cabinet power capacity and breaker rating before swap |
| Terminal Wiring | Standard Yaskawa CN1 / CN2 connector pinout | Retain original cable harness if undamaged; inspect for insulation wear |
| Replacement Series | SGMRV Series (same platform) | Cross-reference with SGMRV-05ANA-YR11 (incremental) if encoder type differs |
| Commissioning Tool | SigmaWin+ / SigmaWin+ Next | Required for absolute encoder initialization and parameter backup |
| Warranty | 12 Months | Covers manufacturing defects; includes pre-shipment functional test |
Retrofit Planning for Existing Automation Systems
A successful retrofit of the SGMRV-05ANA-YR21 into an existing production line requires systematic pre-installation planning. Begin by auditing the control cabinet to document the current servo drive model — typically a SGDV Series or older SGDH Series unit — and confirm its encoder interface card supports the absolute multi-turn encoder used in the YR21 variant. If the existing drive is a SGDH-A5BE or similar legacy model without absolute encoder support, plan for a parallel drive upgrade to a SGDV-R70A or SGDV-1R6A to maintain full system functionality.
Next, inspect the backplane and rack configuration. In multi-axis systems where the SGMRV-05ANA-YR21 operates alongside other servo axes — such as a SGMRV-13ANA-YR21 for a higher-torque axis or a SGMRV-02ANA-YR21 for a lighter positioning axis — verify that the MECHATROLINK network address assignments do not conflict after the module swap. Each axis node address is set via rotary switch on the drive front panel and must be unique within the MECHATROLINK segment.
Terminal wiring adaptation is a critical step. The SGMRV-05ANA-YR21 uses the standard Yaskawa CN2 encoder connector and CN1 motor power connector. If the original installation used a JZSP-CMP00-03 or JZSP-CSP12-03 encoder cable, these are typically reusable provided the cable length and shielding integrity are intact. For cabinet upgrades where the cable run has been extended or rerouted, replace with a new JZSP-CMP series cable to prevent encoder signal noise that can trigger A.810 or A.820 encoder alarms during operation.
I/O mapping should be reviewed in the host controller — whether a Yaskawa MP3300 machine controller, a third-party PLC, or a dedicated motion controller — to confirm that axis parameter tables, electronic gear ratios, and homing sequences remain valid after the motor swap. If the original motor’s absolute encoder battery-backed position data has been lost due to a power outage or battery failure, a full homing cycle must be executed before resuming automatic operation. Ensure the HMI screen associated with this axis — typically displaying position feedback, alarm status, and jog controls — reflects the correct engineering unit scaling after re-commissioning.
For systems integrating a SGDV Series drive with a SI-ES3 or SI-T3 option card for EtherNet/IP or PROFIBUS-DP communication, verify that the communication link to the host PLC is re-established after drive power cycling. Communication parameter settings stored in the option card are non-volatile but should be confirmed against the original commissioning record before returning the axis to automatic mode.
Downtime Control During System Migration
Minimizing unplanned downtime during a servo motor replacement is a primary concern for maintenance engineers managing continuous production environments. The recommended approach for replacing the SGMRV-05ANA-YR21 in a live system is to pre-stage the replacement unit with a full parameter clone from the original drive using SigmaWin+ before the scheduled maintenance window. Export the complete parameter file — including Pn000 through Pn840 and all user constants — and store it as a backup. This ensures that if the replacement drive requires parameter restoration, the process takes minutes rather than hours.
During the physical swap, isolate the axis by placing the host controller in manual or maintenance mode to prevent automatic sequence execution. If the system uses a safety relay module or a SGDV-OSA01A safety option card, confirm that the STO (Safe Torque Off) function is engaged before disconnecting motor power terminals. This protects both personnel and the mechanical load from uncontrolled movement during the changeover.
After mechanical installation and wiring reconnection, perform an absolute encoder setup using SigmaWin+ to initialize the multi-turn counter and confirm the home position offset matches the original commissioning value. Run a low-speed jog test in both directions before enabling the axis in automatic mode. Monitor the SGDV drive’s alarm display and the host controller’s diagnostic screen for any A.7A0 (absolute encoder error) or A.040 (parameter setting error) codes that may indicate a wiring fault or parameter mismatch. A structured pre-return-to-service checklist — covering encoder initialization, parameter verification, communication link confirmation, and a trial automatic cycle — reduces the risk of repeat downtime and protects the integrity of the original program logic.
Retrofit Support FAQ
Q1: Is the SGMRV-05ANA-YR21 a direct drop-in replacement for the SGMRV-05ANA-YR11?
The SGMRV-05ANA-YR21 and SGMRV-05ANA-YR11 share the same mechanical frame, rated output, and mounting interface. The key difference is the encoder type: YR21 uses an absolute encoder while YR11 uses an incremental encoder. Before substituting one for the other, confirm that the paired servo drive supports the target encoder type. A SGDV drive with absolute encoder support (Pn002 = 2) is required for the YR21 variant. If your existing drive only supports incremental encoders, either replace the drive or select the YR11 variant to maintain compatibility.
Q2: What wiring changes are required when replacing a legacy SGMRV unit with the SGMRV-05ANA-YR21?
In most same-series replacements, the existing CN1 motor power cable and CN2 encoder cable can be reused without modification, provided they are undamaged and meet the original specification length. Inspect connector pins for corrosion and cable insulation for cracking before reuse. If the original installation used a non-standard cable assembly, verify pinout compatibility against the SGMRV-05ANA-YR21 wiring diagram in the Sigma-7 Series Product Catalog before reconnecting.
Q3: Does the SGMRV-05ANA-YR21 require any special commissioning steps compared to a standard servo motor replacement?
Yes. Because the YR21 variant uses an absolute encoder, an encoder initialization procedure must be performed using SigmaWin+ after installation. This involves clearing the multi-turn alarm (A.810), setting the absolute encoder origin (Fn008), and confirming the position offset against the machine’s mechanical home reference. Skipping this step will result in position errors and may trigger safety faults in the host controller. All units supplied by SMARTNEXMSK are pre-tested for encoder communication integrity before shipment.
Q4: What does the 12-month warranty cover, and what is the process for a warranty claim?
The 12-month warranty covers manufacturing defects, encoder communication failures, and motor winding faults under normal operating conditions. It does not cover damage resulting from incorrect wiring, overvoltage, mechanical overload, or unauthorized disassembly. To initiate a warranty claim, contact our technical support team with the unit serial number, a description of the fault symptom, and the SigmaWin+ alarm log if available. Replacement or repair will be arranged within the warranty period with priority handling to minimize your production downtime.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341