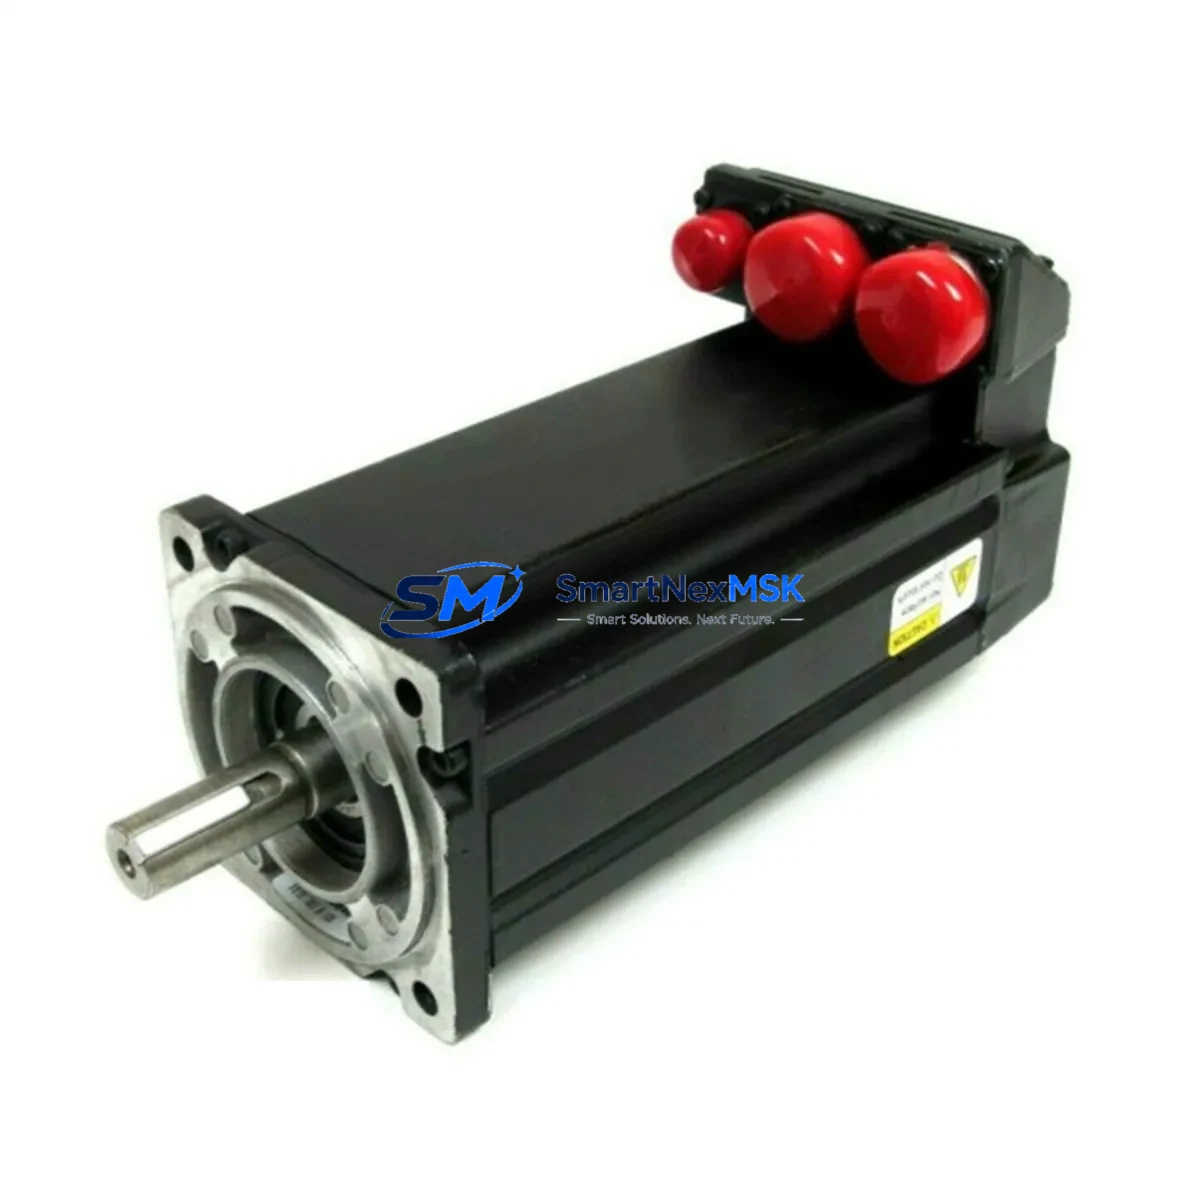
Allen-Bradley MPL-B330P-SJ24AA Retrofit-Ready Servo Motor for Kinetix Control Systems
The Allen-Bradley MPL-B330P-SJ24AA is a medium-inertia, brushless servo motor from Rockwell Automation’s MPL (Magnetically Permeable Low-inertia) series, engineered for precision motion control in demanding industrial environments. As legacy automation lines age and OEM support windows close, the MPL-B330P-SJ24AA has become one of the most sought-after retrofit and replacement components for facilities running Kinetix 6000 and Kinetix 6500 multi-axis servo drive systems. Whether you are replacing a failed unit on a packaging line, upgrading a legacy motion axis on a CNC machining center, or migrating from an older 1394 GMC Turbo drive platform, this motor delivers the torque density, feedback resolution, and drive compatibility required for a smooth, low-risk transition.
The MPL-B330P-SJ24AA operates at 460 VAC nominal input (via the drive bus), produces continuous stall torque suitable for mid-range axis loads, and integrates a high-resolution multi-turn absolute encoder that interfaces directly with the Kinetix 6000 (2094-BCxx-Mxx) and Kinetix 6500 (2198-Hxxx-ERSx) drive families through a standard 2090-XXNPMF-Sxx feedback cable. This eliminates the need for encoder signal converters or third-party interface cards during most retrofit scenarios, significantly reducing commissioning time and the risk of signal integrity issues on the feedback loop.
Upgrade Compatibility Table
| Parameter | MPL-B330P-SJ24AA | Retrofit Notes |
|---|---|---|
| Compatible Drives | Kinetix 6000 (2094), Kinetix 6500 (2198) | Verify drive firmware ≥ v4.x for full encoder support |
| Feedback Interface | Multi-turn Absolute Encoder (Hiperface) | Use 2090-XXNPMF-Sxx cable; no adapter required |
| Power Connector | SpeedTec DIN (rotating bayonet) | Confirm mating connector on existing cable harness |
| Mounting Frame | NEMA 23 / IEC 90 flange | Check shaft diameter and keyway against coupling |
| Brake Option | 24 VDC holding brake (SJ suffix) | Verify brake relay wiring in control cabinet |
| Replacement for | MPL-B330P-MJ22AA, MPL-B330P-SJ72AA, 1326AB-B330E | Confirm encoder type match before swapping |
| Installation Environment | IP65 (shaft seal), IP54 (body) | Verify enclosure rating matches application |
| Commissioning Tool | Studio 5000 Logix Designer / Motion Analyzer | Run Tune Axis wizard after mechanical installation |
| Warranty | 12-Month Warranty — covers defects in materials and workmanship from date of shipment | |
Retrofit Planning for Existing Automation Systems
A successful MPL-B330P-SJ24AA retrofit begins well before the motor arrives on-site. The first step is a thorough audit of the existing control cabinet. Most legacy installations pairing this motor frame size with a Kinetix 6000 shared-bus system will include a 2094-BC01-MP5 or 2094-BC02-M02-S IAM (Integrated Axis Module) as the bus leader, alongside one or more 2094-BM02-S AM (Axis Modules) for subordinate axes. Confirm that the IAM’s DC bus capacity is sufficient to absorb the regenerative energy from the replaced axis, particularly if the application involves frequent deceleration cycles or vertical load holding.
On the feedback side, inspect the existing 2090-XXNPMF-Sxx motor feedback cable for pinched insulation, corroded contacts, or damaged SpeedTec connectors. A degraded feedback cable is a common root cause of nuisance F004 (Motor Feedback Loss) faults that are often misdiagnosed as motor failures. If the cable is suspect, replace it concurrently with the motor to avoid a second maintenance window. For installations migrating from the older 1394 GMC Turbo platform, a 2090-K2CK-D15M feedback adapter kit is required to bridge the legacy 15-pin D-sub connector to the Kinetix-compatible SpeedTec interface.
Power wiring should be verified against the drive’s axis module output rating. The MPL-B330P-SJ24AA’s U, V, W motor leads connect to the axis module’s motor output terminals; confirm torque values on terminal screws per the 2094 installation manual. If the control cabinet includes a 1756-M02AE or 1756-M08SEG motion module in a ControlLogix rack, verify that the axis configuration in Studio 5000 references the correct motor catalog number so that the drive’s electronic gearing, torque limits, and velocity loop gains are auto-populated correctly from the Rockwell motor database.
For facilities running a PanelView Plus 7 or PanelView Plus 6 HMI, no screen modifications are typically required for a like-for-like motor swap, as the HMI communicates with the ControlLogix controller via EtherNet/IP and the axis tag structure remains unchanged. However, if the retrofit involves a change in gear ratio or mechanical coupling, update the relevant conversion tags (e.g., Axis.ConversionConstant) in the controller program before going live. Always back up the existing .ACD project file and export the current axis configuration before making any changes in Studio 5000.
Downtime Control During System Migration
Minimizing unplanned downtime is the primary concern for any servo motor replacement on a live production line. The recommended approach is to pre-stage the MPL-B330P-SJ24AA as a tested, ready-to-install spare before scheduling the maintenance window. Upon receipt, perform a basic incoming inspection: verify the motor catalog number label, check the shaft for runout, confirm the encoder connector is undamaged, and apply 24 VDC to the brake terminals to verify release. Document the motor’s serial number and encoder multi-turn position offset value (readable via the drive’s HIM or Studio 5000 online mode) before disconnecting the old unit — this offset may need to be re-established after installation if the absolute position reference is lost.
During the swap, tag and photograph all terminal connections before disconnection. The brake circuit (typically wired through a 700-HLT2Z24 relay or equivalent) should be tested independently after reconnection to confirm the brake releases on drive enable and engages on drive disable or E-stop. After mechanical installation and wiring, perform the Studio 5000 Tune Axis procedure to re-establish velocity and position loop gains. For most standard inertia-matched applications, the auto-tune result will be acceptable for immediate production restart; fine-tuning can be performed during the next scheduled maintenance window if needed.
Maintaining a documented spare parts list that includes the MPL-B330P-SJ24AA alongside related components — such as the 2090-XXNPMF-Sxx feedback cable, 2094-BM02-S axis module, and 1756-M02AE motion module — ensures that future failures can be addressed within a single shift rather than waiting for emergency procurement. All units shipped by SMARTNEXMSK are function-tested prior to dispatch and covered by a 12-month warranty, providing a reliable supply chain backstop for critical production assets.
Retrofit Support FAQ
Q1: Can the MPL-B330P-SJ24AA directly replace an MPL-B330P-MJ22AA without reprogramming?
In most cases, yes — both share the same frame size, continuous torque rating, and Hiperface encoder interface. The primary difference is the feedback cable connector style (SpeedTec vs. bayonet). Verify the mating connector on your existing 2090-series cable before ordering. No changes to the Studio 5000 axis configuration are required if the catalog number is updated in the motor properties dialog.
Q2: What wiring checks are mandatory before powering up after installation?
Confirm correct phase sequence on U, V, W motor leads (swapping any two phases will cause the drive to fault on motor direction error). Verify the 24 VDC brake circuit is wired to the correct axis module brake output terminals. Check feedback cable shield continuity and confirm the SpeedTec connector is fully seated and locked. Inspect the PE (protective earth) connection at both the motor and the drive chassis.
Q3: How do I verify compatibility with my existing Kinetix 6500 EtherNet/IP drive?
Open Studio 5000, navigate to the axis properties of the affected drive (2198-Hxxx-ERSx), and confirm the motor catalog number field accepts MPL-B330P-SJ24AA from the Rockwell motor database. If the catalog number is not listed, update the drive firmware to the latest revision and refresh the motor database. The drive’s Motion Analyzer tool can also be used to verify inertia ratio and confirm the motor is appropriately sized for the load.
Q4: What does the 12-month warranty cover, and what is the return process?
The 12-month warranty covers defects in materials and workmanship from the date of shipment. It does not cover damage resulting from incorrect installation, overvoltage, or mechanical overload. To initiate a warranty claim, contact [email protected] with the order number, motor serial number, and a description of the fault. SMARTNEXMSK will arrange return shipping and provide a replacement or full refund upon inspection confirmation.
© 2026 SMARTNEXMSK. All rights reserved.
Original Source: https://smartnexmsk.com
Contact: [email protected] | +86 18259474341